gtsam


ICE
Software Release for "Incremental Covariance Estimation for Robust Localization"
- 60
- Shell
- MIT
- 6 y ago
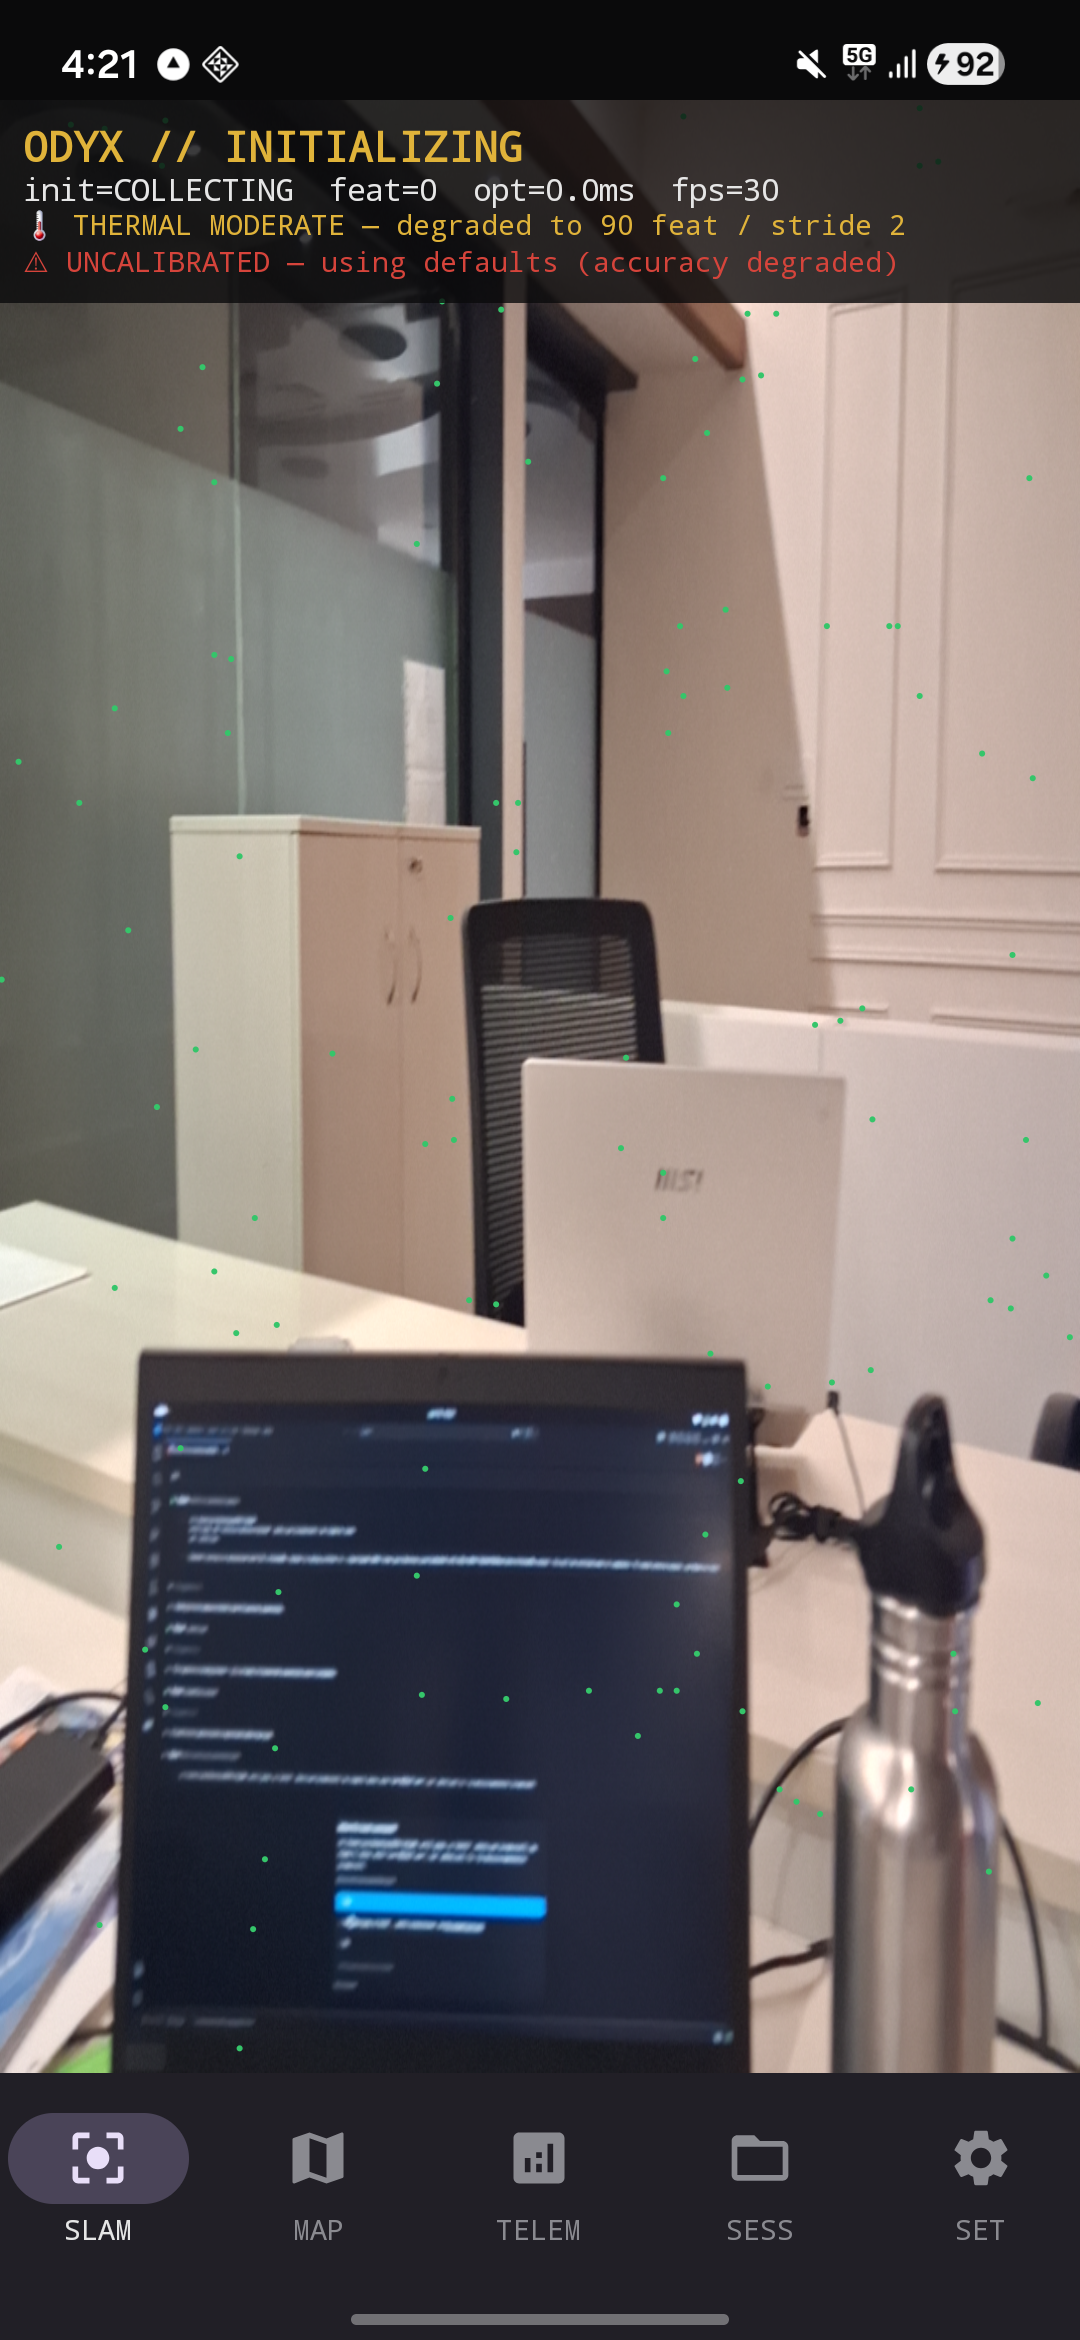
ODYX-VISUAL-SLAM
On-device visual-inertial SLAM with GNSS fusion for Android. A from-scratch GTSAM factor-graph VIO (camera + IMU + raw GNSS) that replaces ARCore for georeferenced 6-DoF pose.
- 6
- C++
- MIT
- 5 mo ago

Enabling-Robust-State-Estimation-through-Measurement-Error-Covariance-Adaptation
Software release for "Enabling Robust State Estimation through Measurement Error Covariance Adaptation"
- 22
- Shell
- MIT
- 7 y ago
PPP-BayesTree
Code release for "Evaluation of Precise Point Positioning Convergence with an Incremental Graph Optimizer".
- 56
- C++
- MIT
- 8 y ago