Robo3D
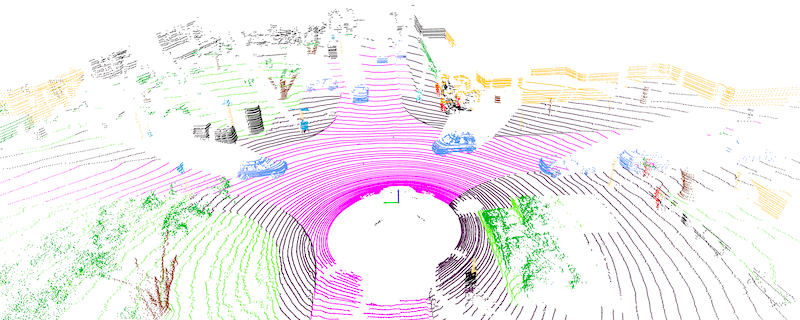
[ICCV 2023] Robo3D: Towards Robust and Reliable 3D Perception against Corruptions
- 380
- Python
- 12 mo ago
[ICCV 2023] Robo3D: Towards Robust and Reliable 3D Perception against Corruptions
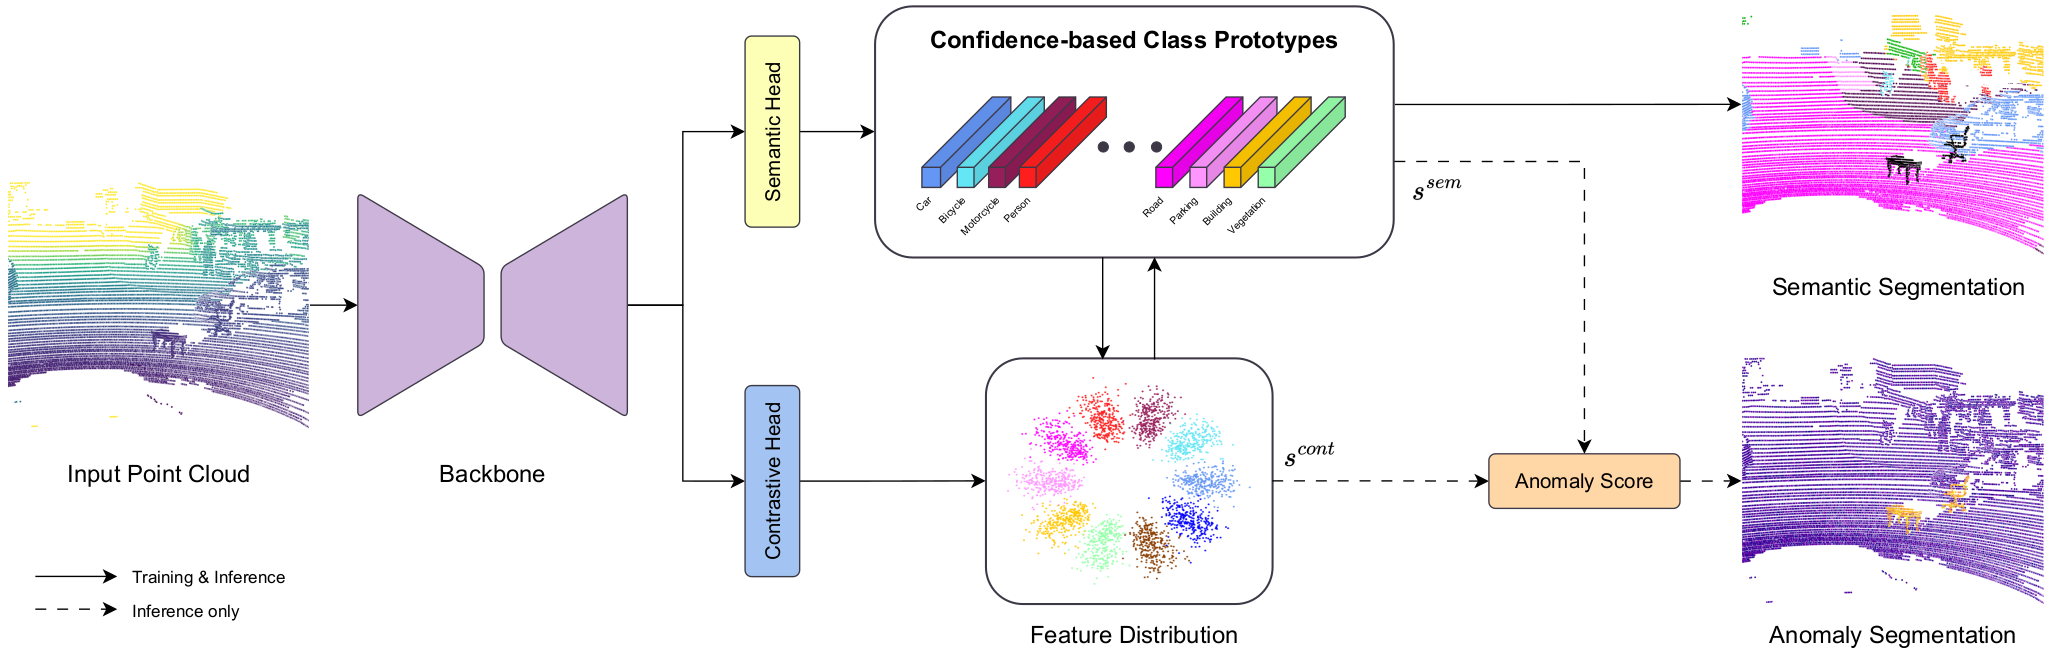
[CVPR 2026] Learning to Identify Out-of-Distribution Objects for 3D LiDAR Anomaly Segmentation
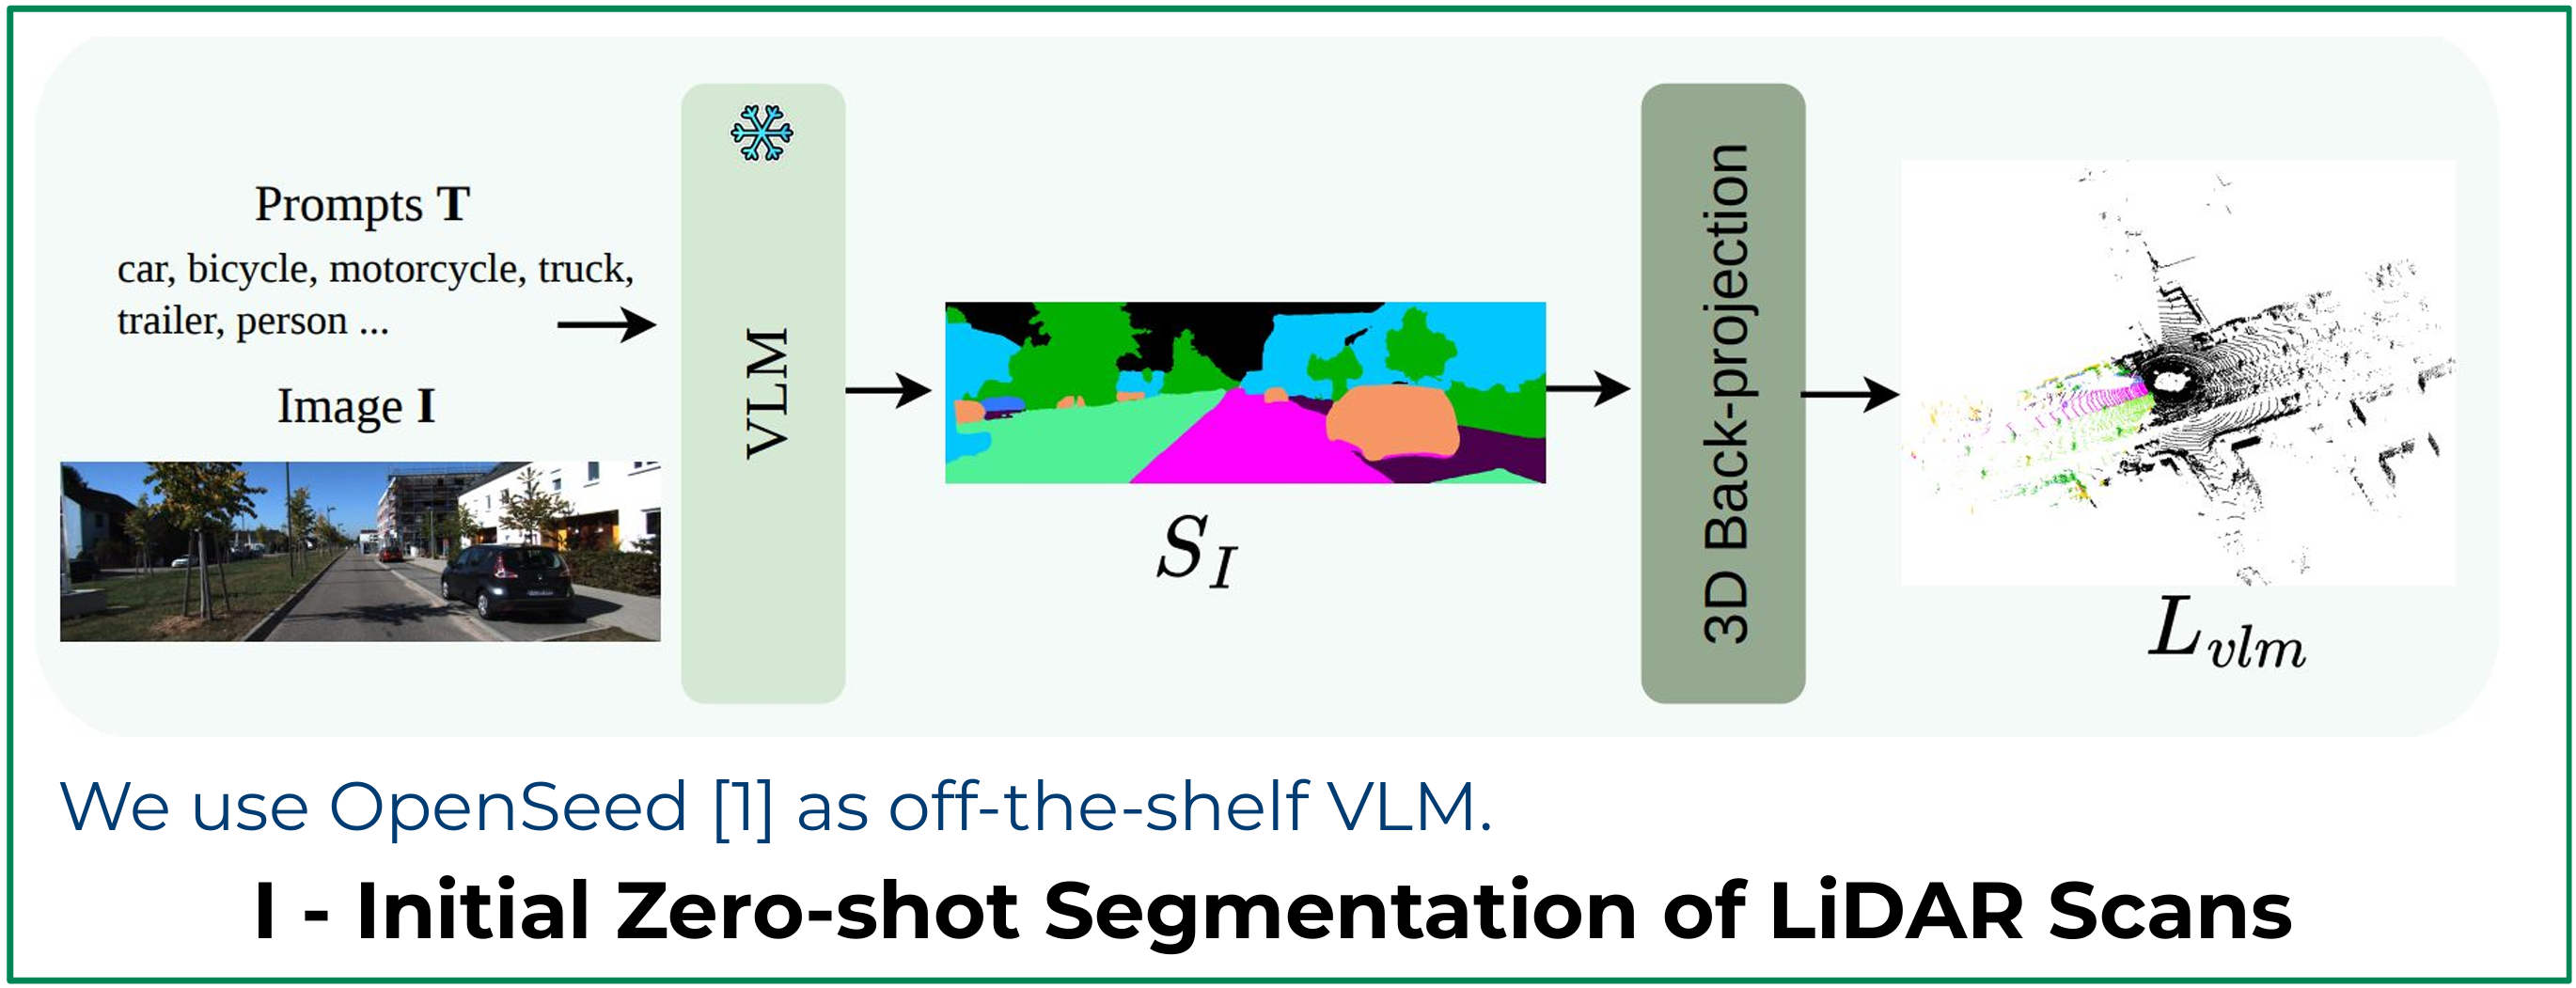
[3DV 2026, Oral] Official PyTorch implementation of LOSC: LiDAR Open-voc Segmentation Consolidator
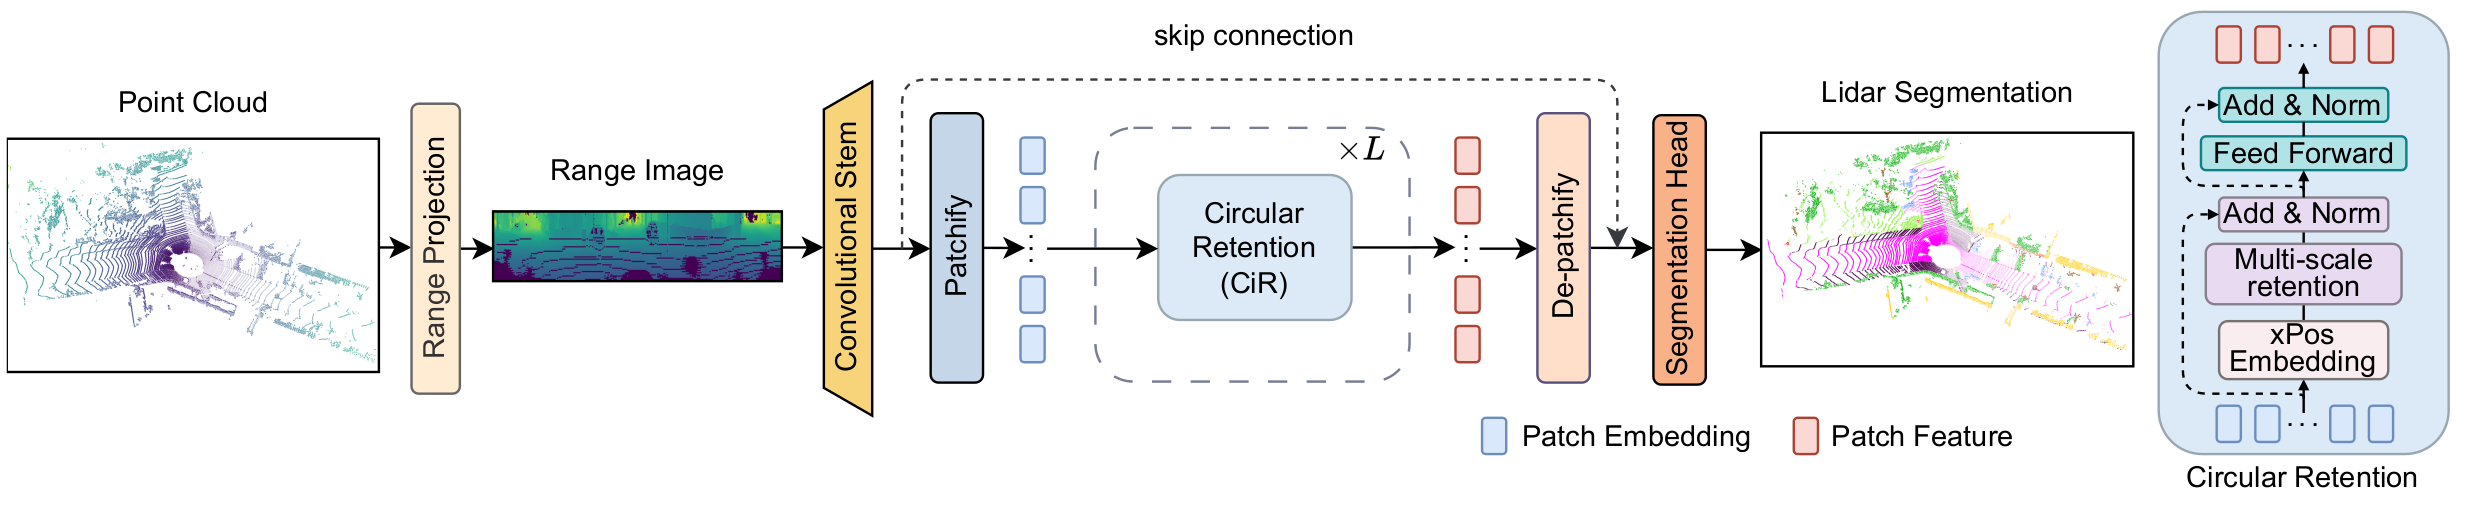
[WACV 2026] Revisiting Retentive Networks for Fast Range-View 3D LiDAR Semantic Segmentation
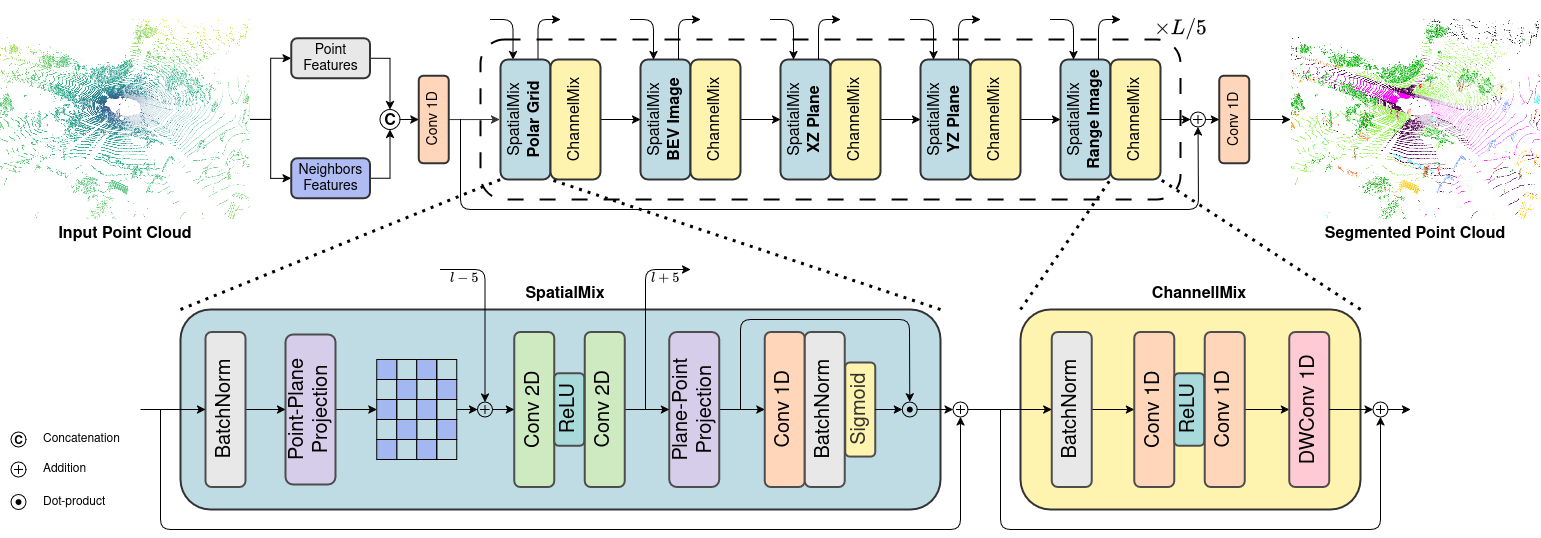
[CVIU 2026] Point-Plane Projections for Accurate LiDAR Semantic Segmentation in Small Data Scenarios