fast_gicp
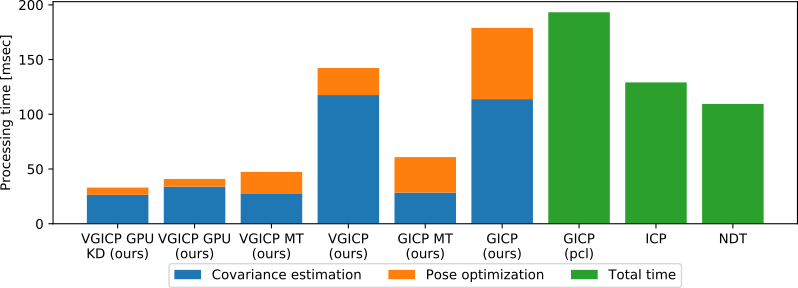
A collection of GICP-based fast point cloud registration algorithms
- 1.7k
- C++
- BSD-3-Clause
- 19 mo ago
A collection of GICP-based fast point cloud registration algorithms
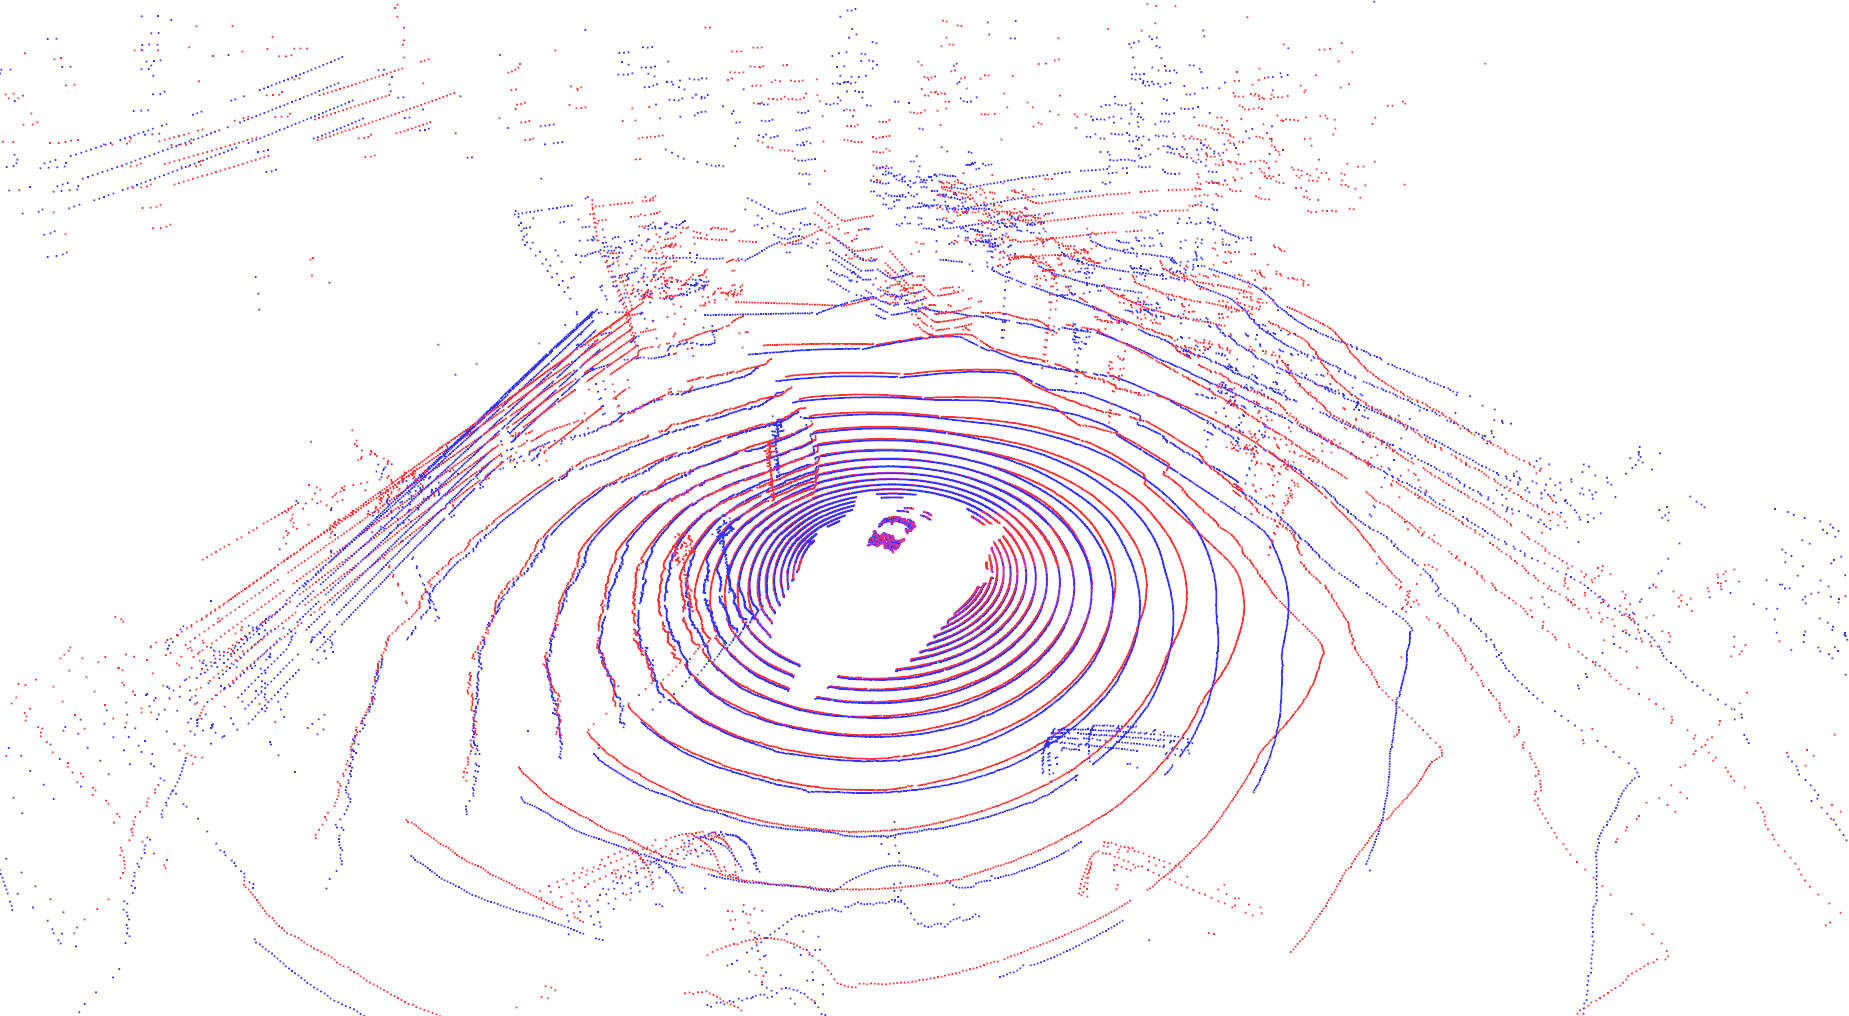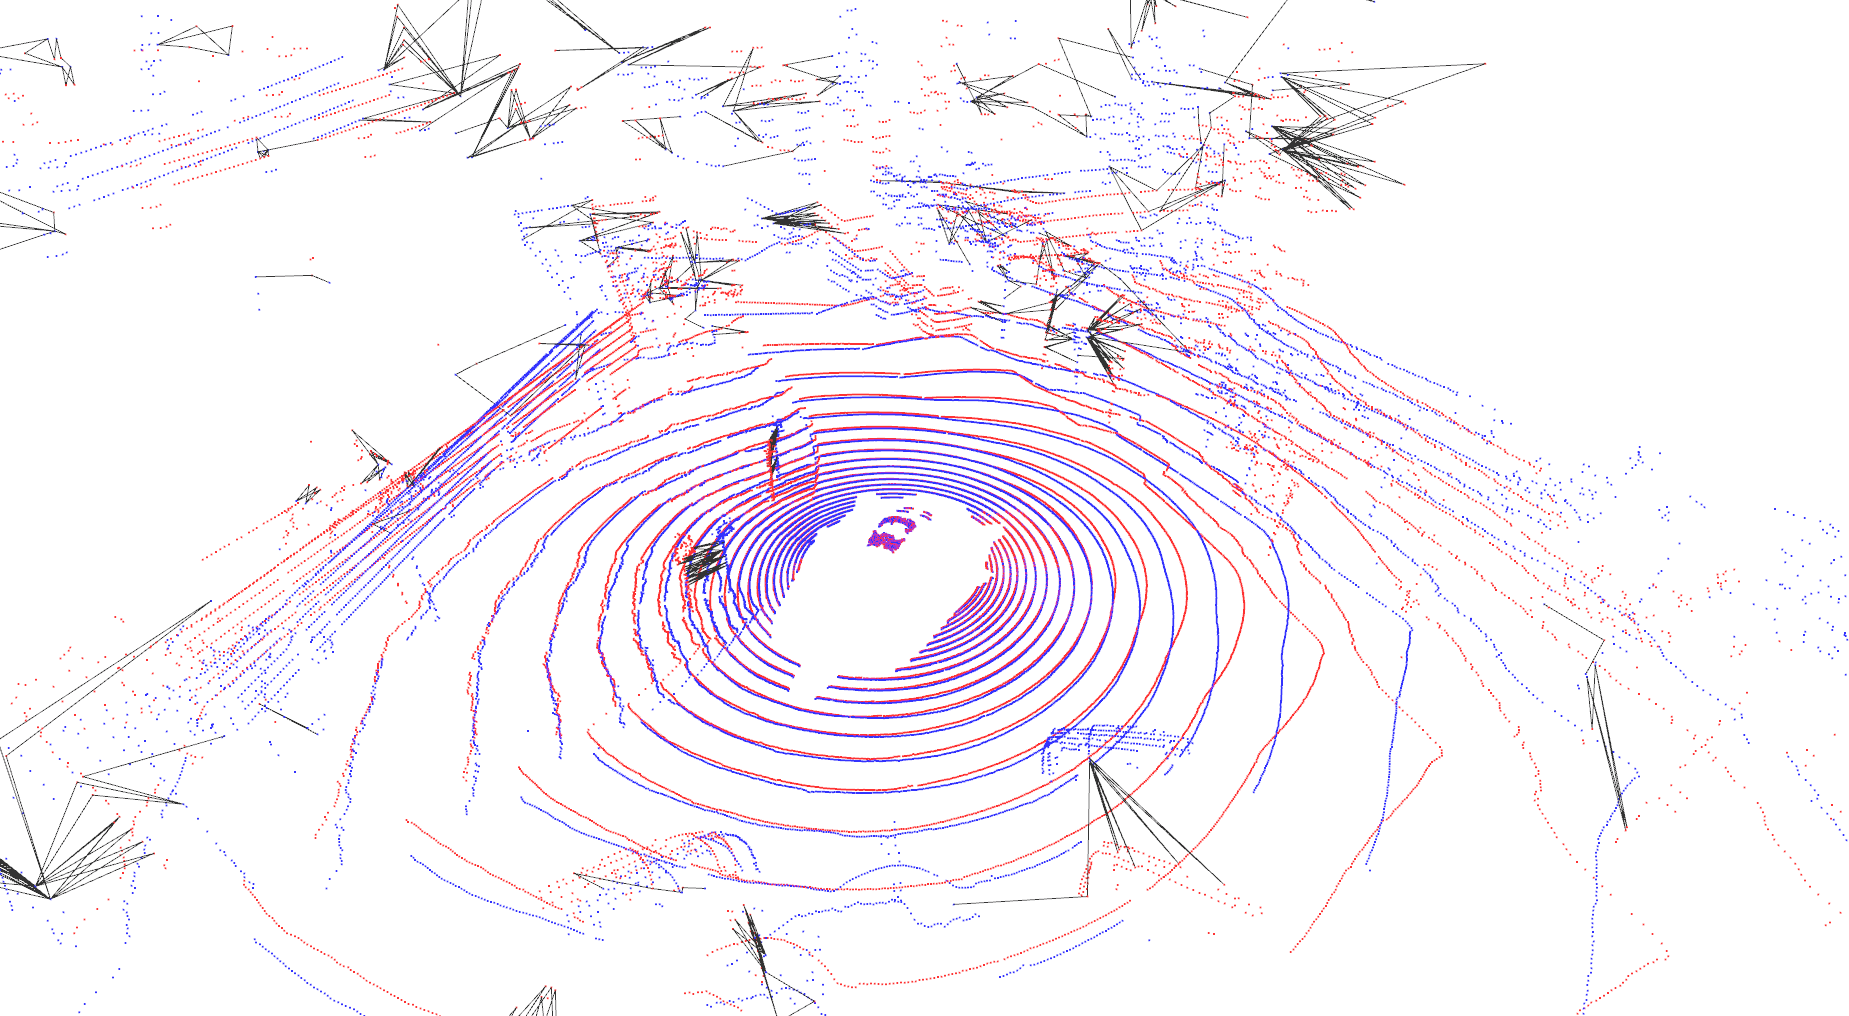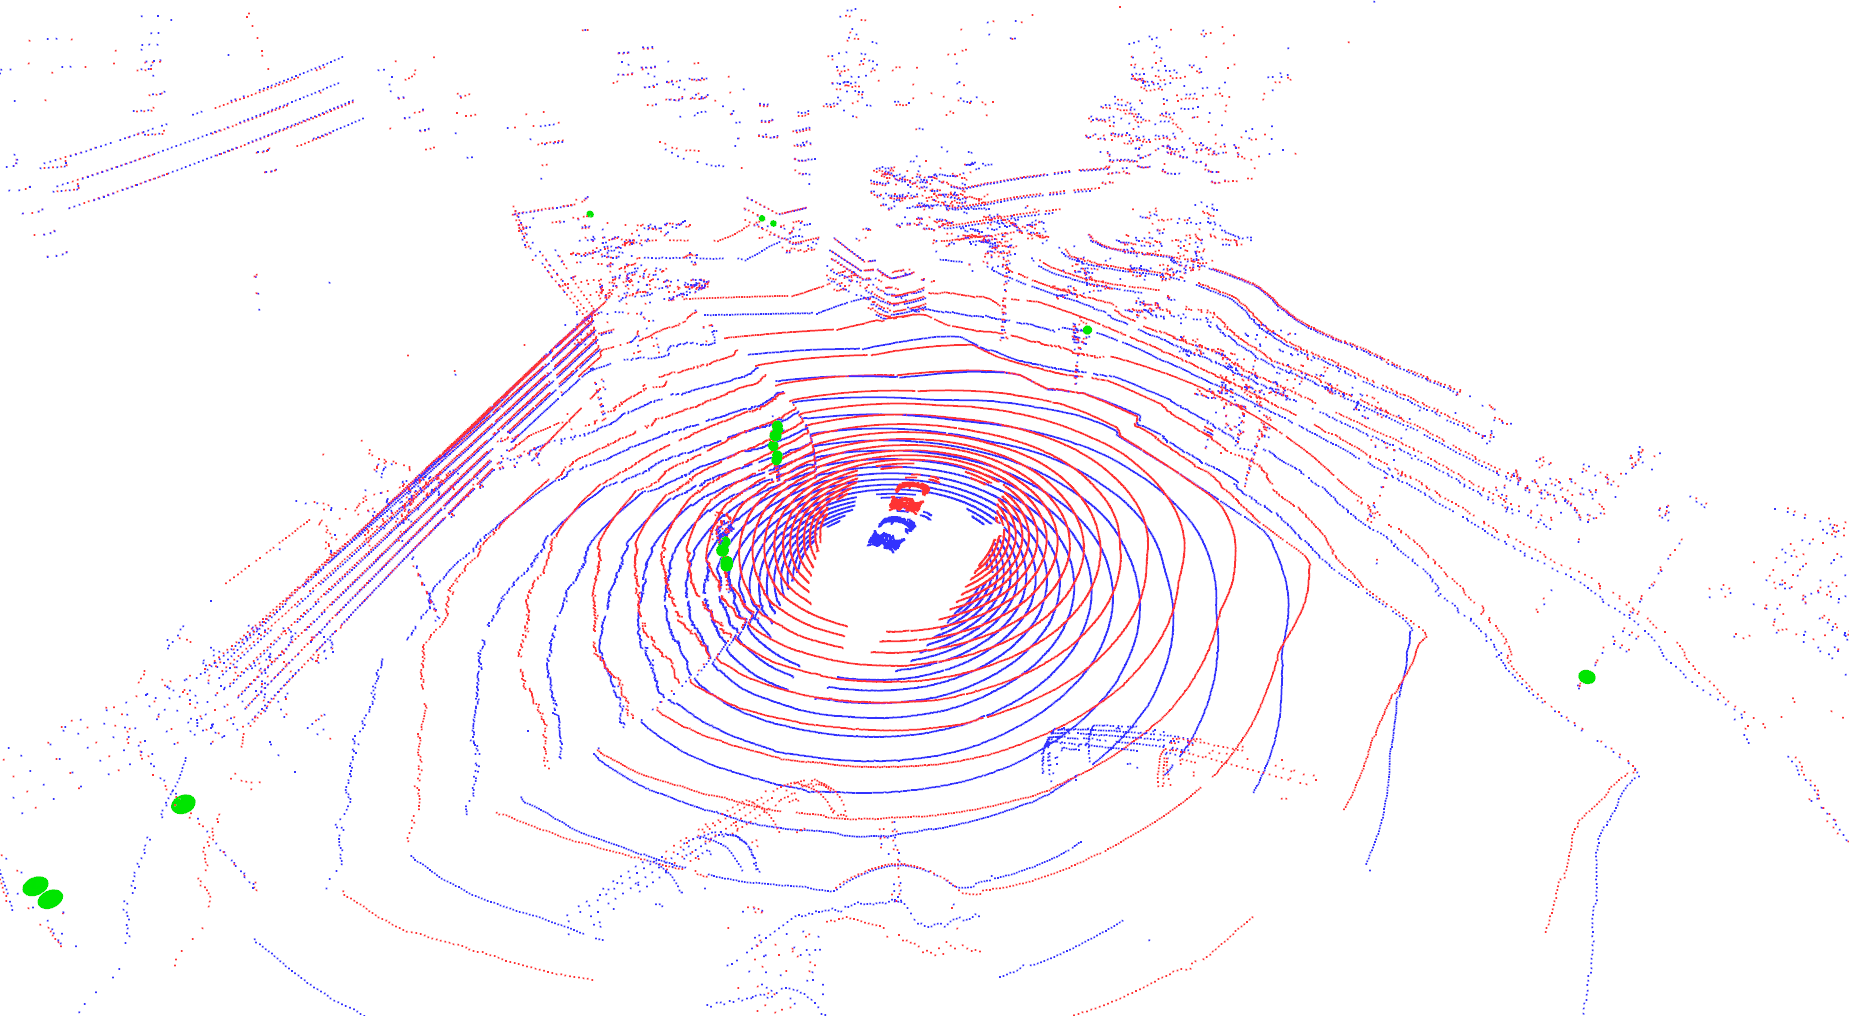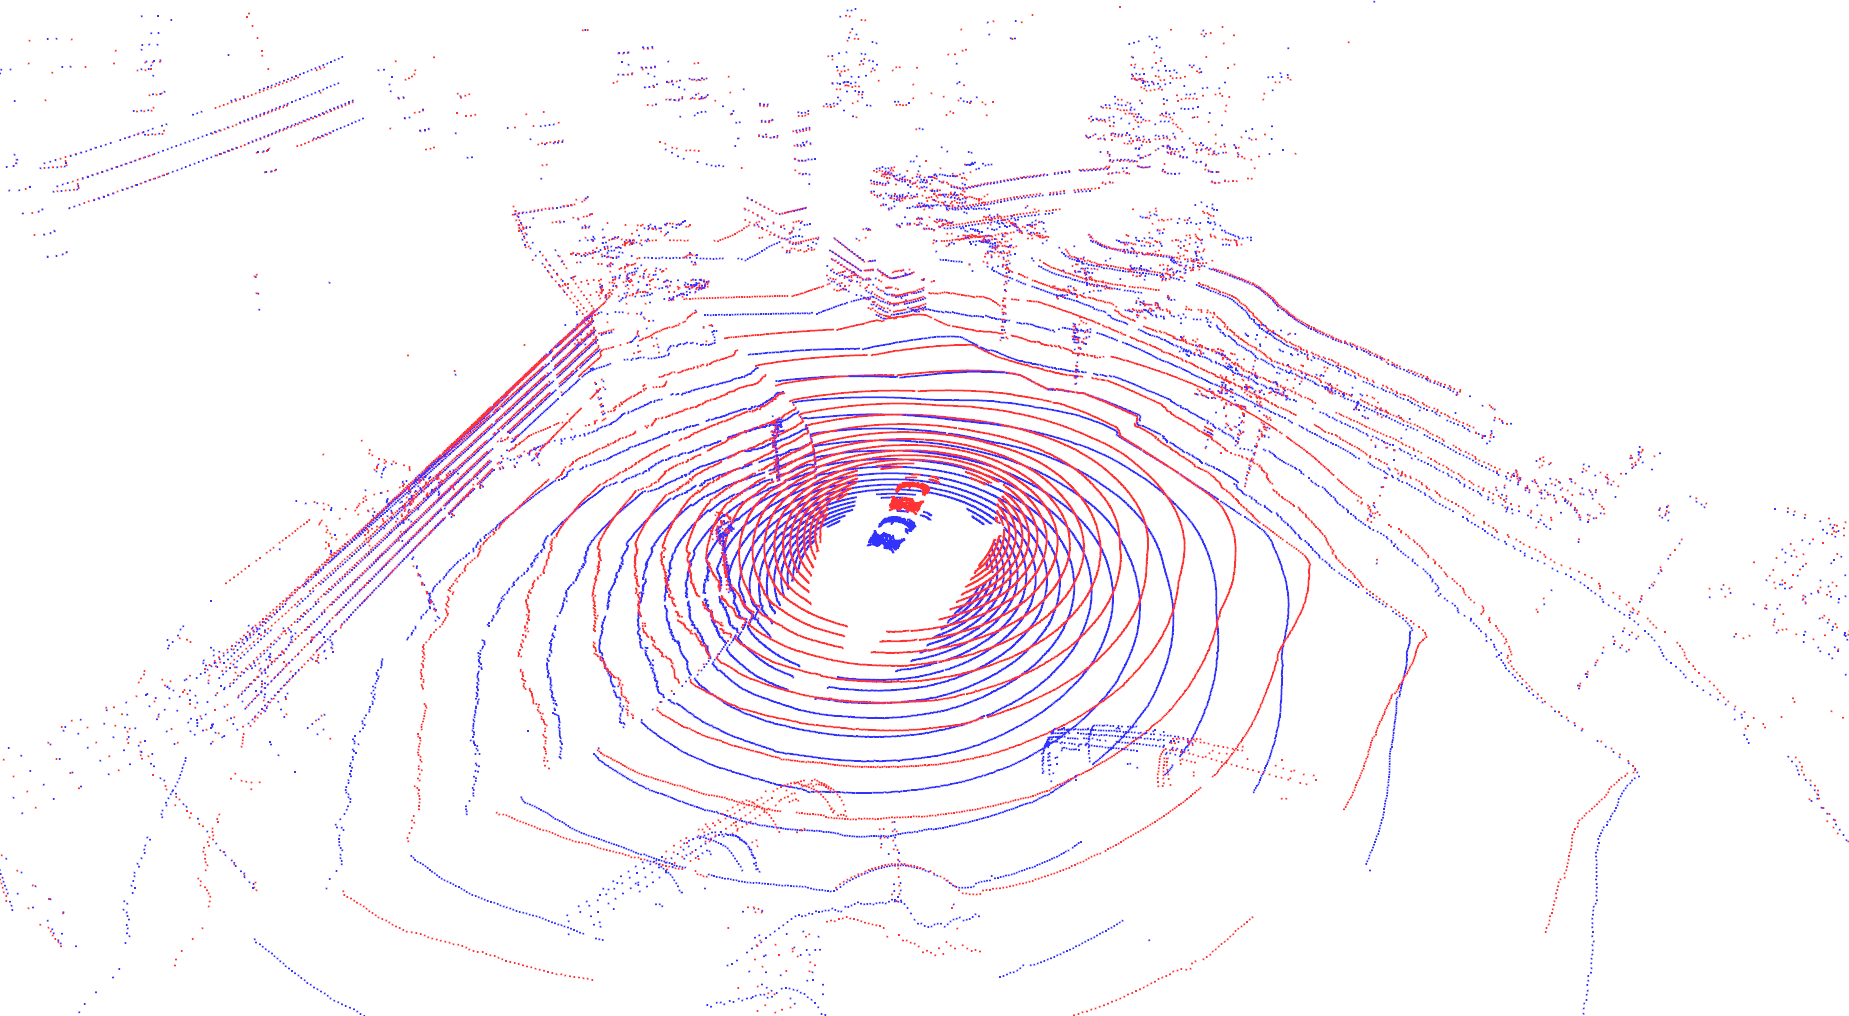
Efficient and parallel algorithms for point cloud registration [C++, Python]
K-Closest Points and Maximum Clique Pruning for Efficient and Effective 3-D Laser Scan Matching (RA-L 2022)
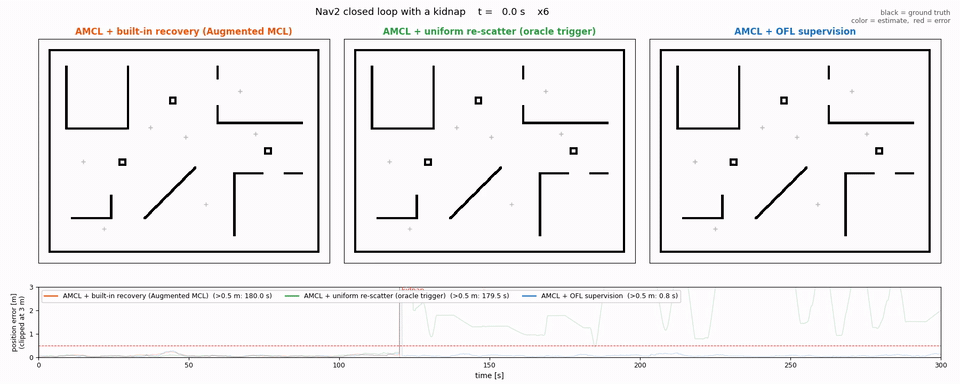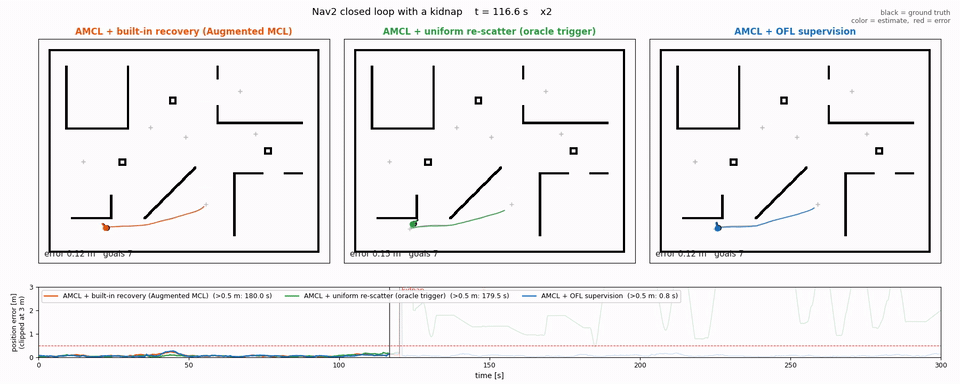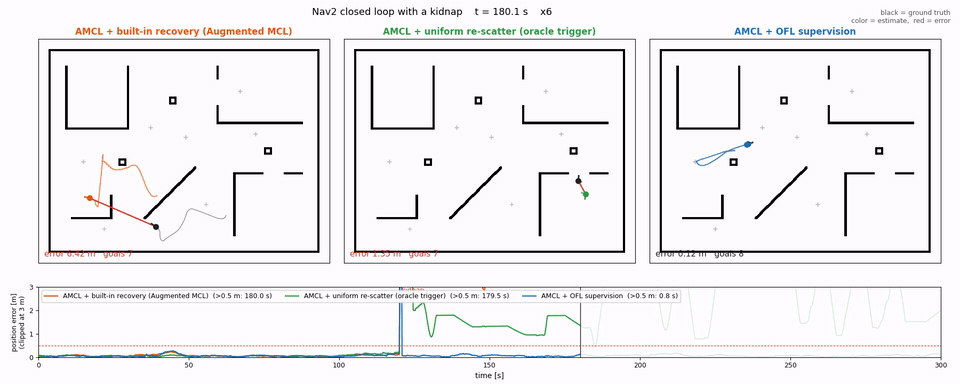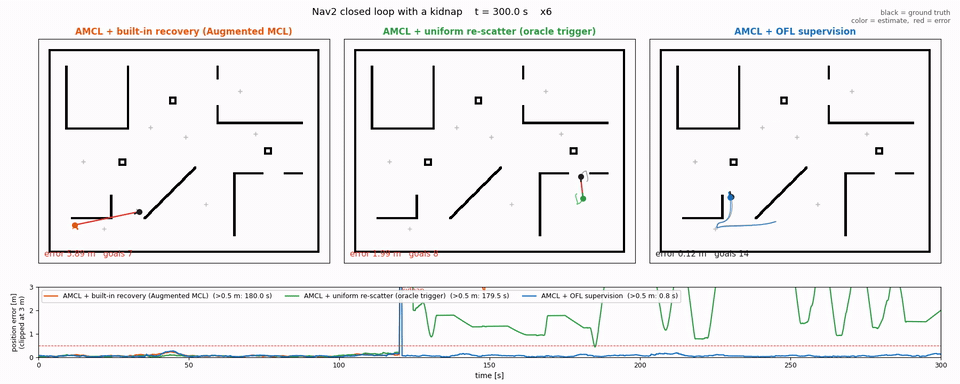
3-DoF pose from a single 2D LiDAR scan with no initial guess — ROS 2 global localization by FFT correlation of oriented (wall-normal) fields in image space