slam




cartographer
Cartographer is a system that provides real-time simultaneous localization and mapping (SLAM) in 2D and 3D across multiple platforms and sensor configurations.
- 8k
- C++
- Apache-2.0
- 3 y ago



pyslam
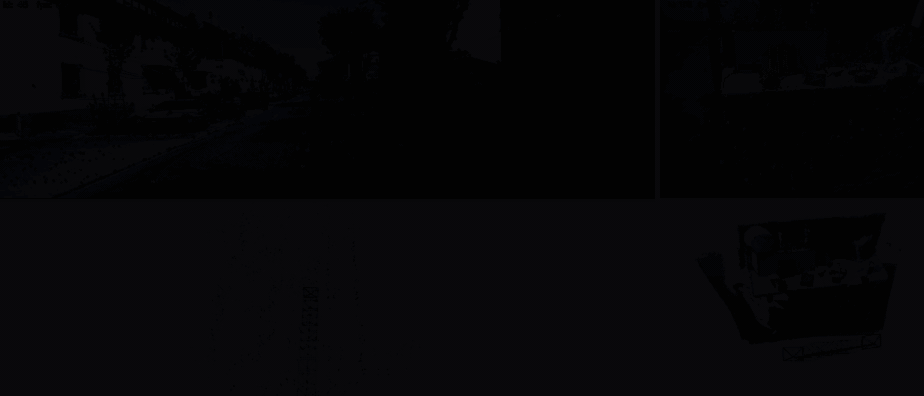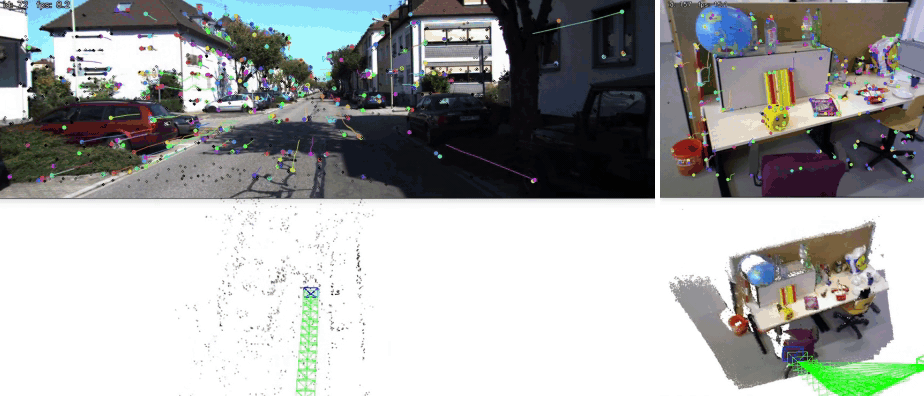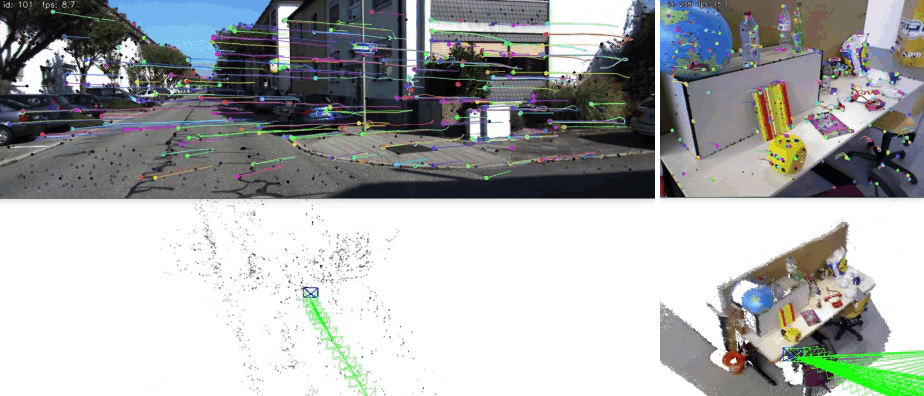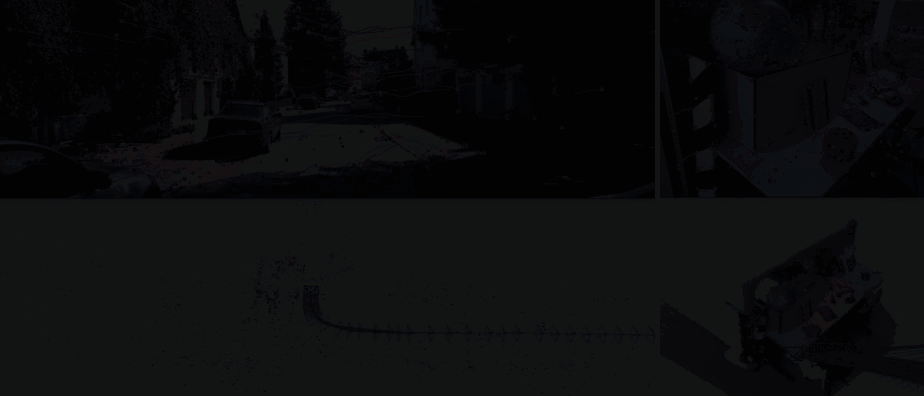
pySLAM is a hybrid Python/C++ Visual SLAM pipeline supporting monocular, stereo, and RGB-D cameras. It provides a broad set of modern local and global feature extractors, multiple loop-closure strategies, a volumetric reconstruction module, integrated depth-prediction models, and semantic segmentation capabilities for enhanced scene understanding.
- 3.4k
- Python
- GPL-3.0
- 3 d ago




AutonomousVehicleControlBeginnersGuide
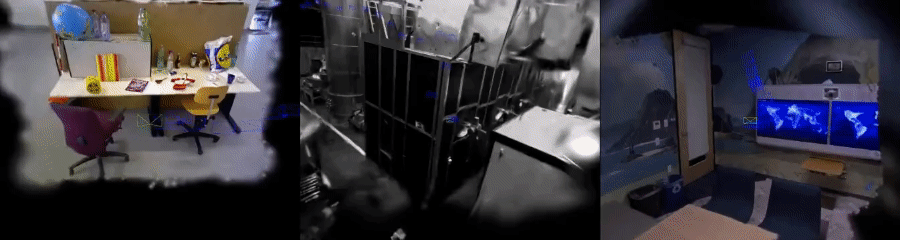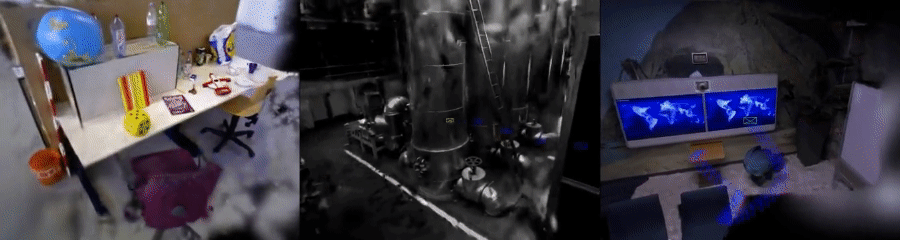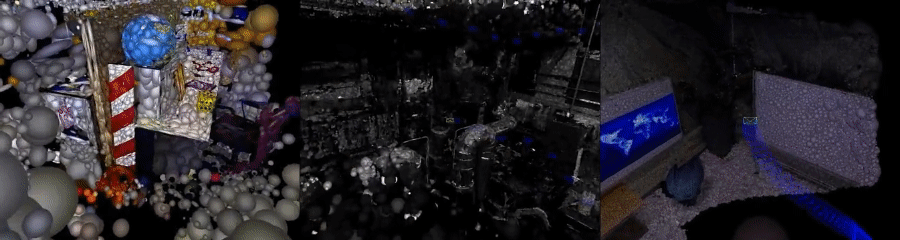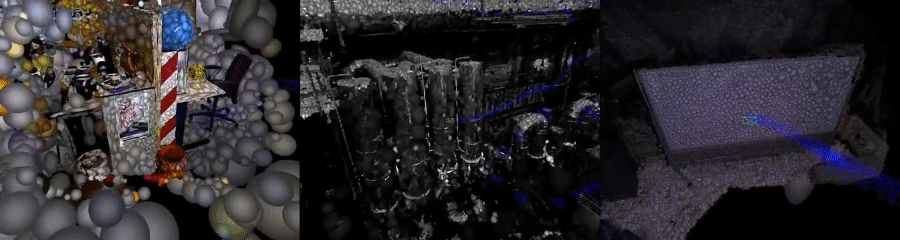
Learn autonomous driving by building it: Python simulations and an open textbook where the system grows one stage at a time. Swap and compare localization, planning and control algorithms in the same system.
- 2k
- Python
- MIT
- 2 d ago


awesome-radar-perception
A curated list of radar datasets, detection, tracking and fusion
- 1.9k
- 20 mo ago

symforce
Fast symbolic computation, code generation, and nonlinear optimization for robotics
- 1.7k
- C++
- Apache-2.0
- 3 wk ago

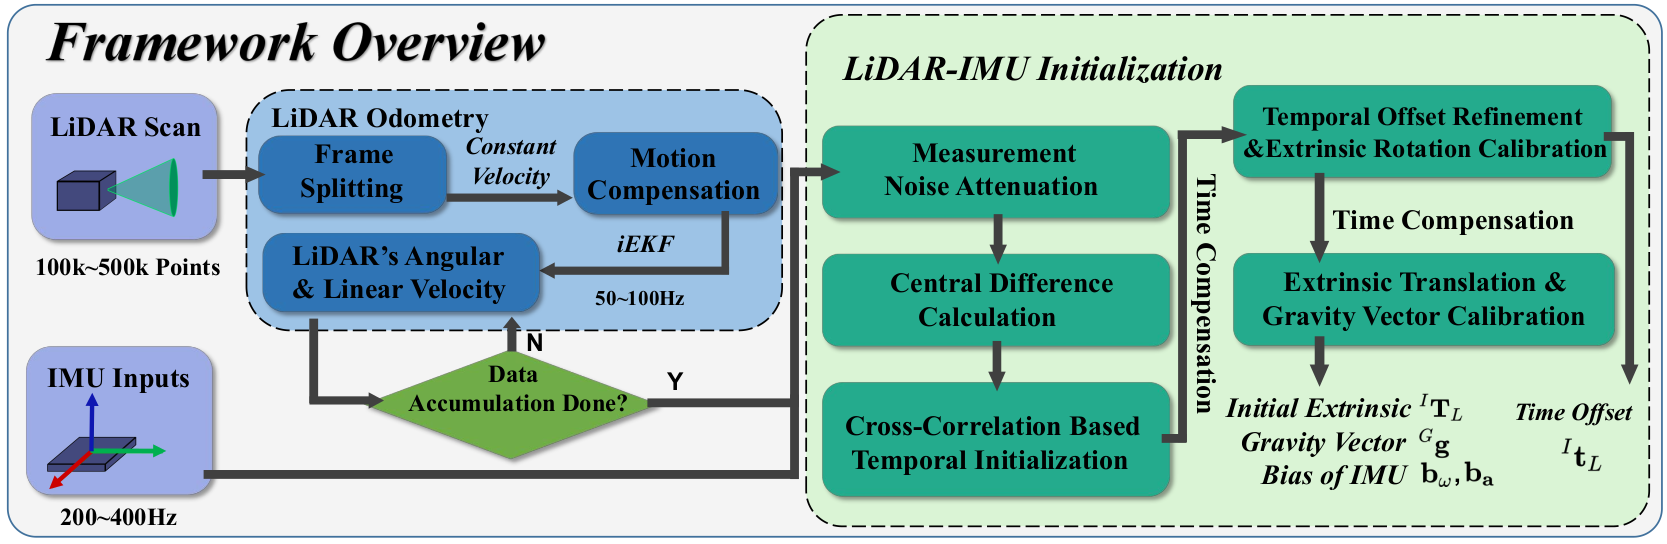
LiDAR_IMU_Init
[IROS2022] Robust Real-time LiDAR-inertial Initialization Method.
- 1.5k
- C++
- GPL-2.0
- 7 mo ago


Photogrammetry-Guide
Photogrammetry Guide. Photogrammetry is widely used for Aerial surveying, Agriculture, Architecture, 3D Games, Robotics, Archaeology, Construction, Emergency management, and Medical.
- 1.5k
- Python
- 17 mo ago

awesome-lidar
😎 Awesome LIDAR list. The list includes LIDAR manufacturers, datasets, point cloud-processing algorithms, point cloud frameworks and simulators.
- 1.4k
- CC0-1.0
- 12 d ago


zed-sdk
⚡️The spatial perception framework for rapidly building smart robots and spaces
- 1.2k
- C++
- MIT
- 4 wk ago


direct_lidar_odometry
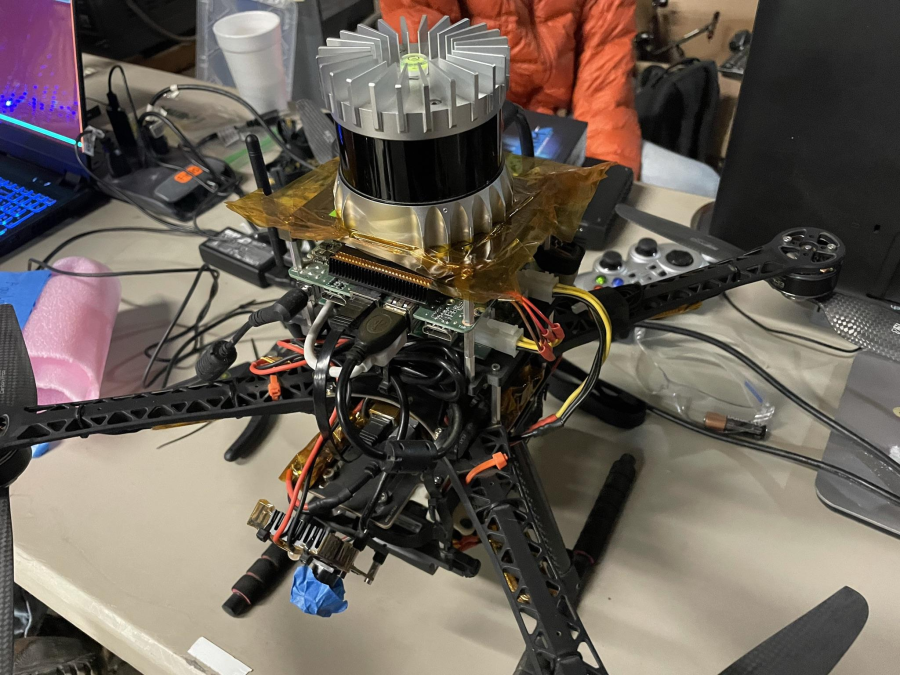
[IEEE RA-L & ICRA'22] A lightweight and computationally-efficient frontend LiDAR odometry solution with consistent and accurate localization.
- 1.1k
- C++
- MIT
- 2 y ago


lio-mapping
Implementation of Tightly Coupled 3D Lidar Inertial Odometry and Mapping (LIO-mapping)
- 1k
- C++
- GPL-3.0
- 7 y ago



deep-image-matching
Multiview matching with deep-learning and hand-crafted local features for COLMAP and other SfM software. Supports high-resolution formats and images with rotations. Both CLI and GUI are supported.
- 558
- Python
- 9 mo ago

minisam
A general and flexible factor graph non-linear least square optimization framework
- 516
- C++
- BSD-3-Clause
- 5 y ago

sparse-to-dense.pytorch
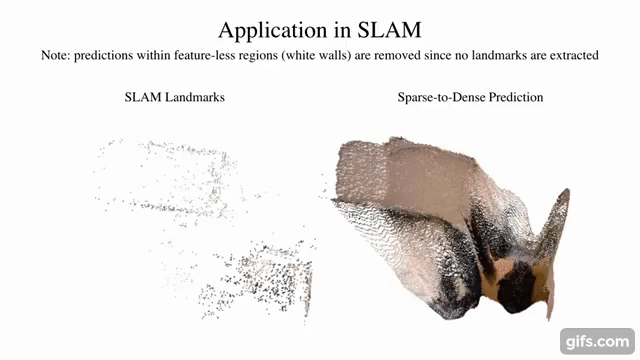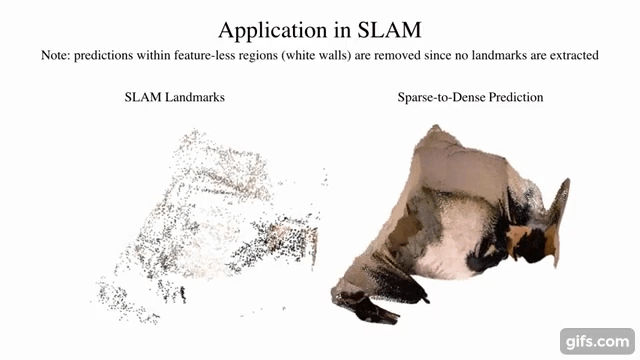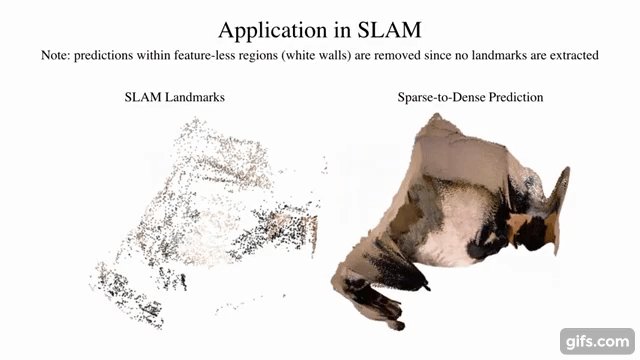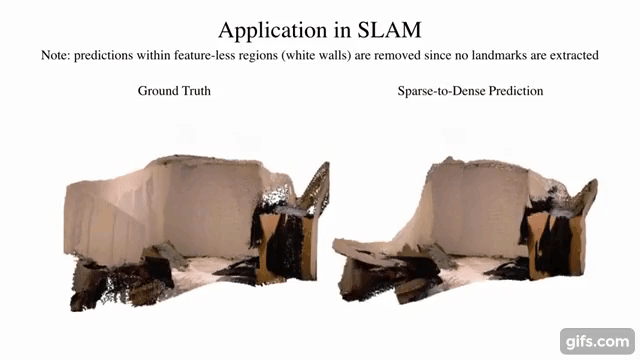
ICRA 2018 "Sparse-to-Dense: Depth Prediction from Sparse Depth Samples and a Single Image" (PyTorch Implementation)
- 451
- Python
- 8 y ago

SE-Sync
An implementation of the SE-Sync algorithm for synchronization over the special Euclidean group.
- 441
- Jupyter Notebook
- LGPL-3.0
- 2 y ago


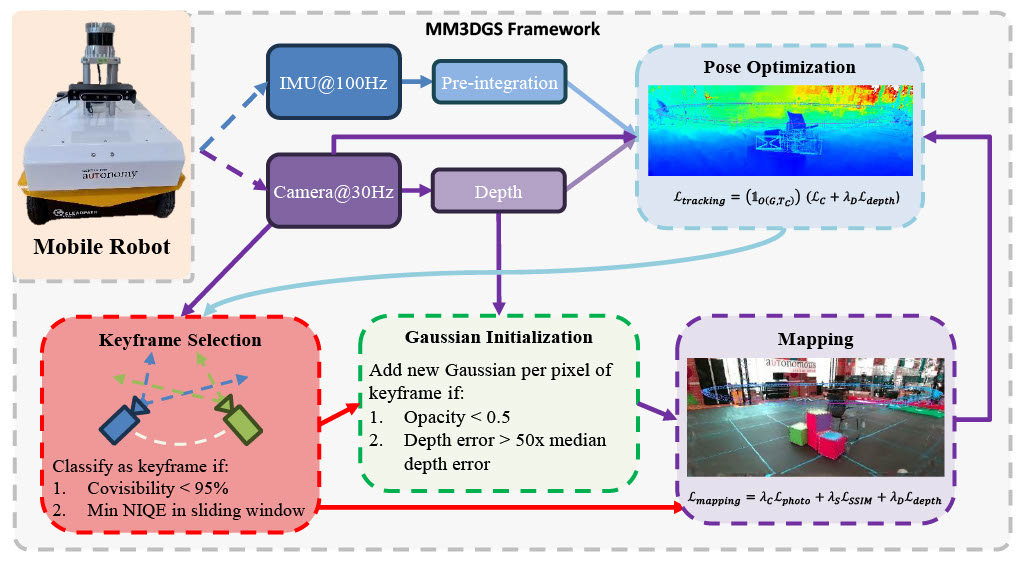
MM3DGS-SLAM
[IROS 2024] MM3DGS SLAM: Multi-modal 3D Gaussian Splatting for SLAM Using Vision, Depth, and Inertial Measurements
- 218
- Python
- 2 y ago

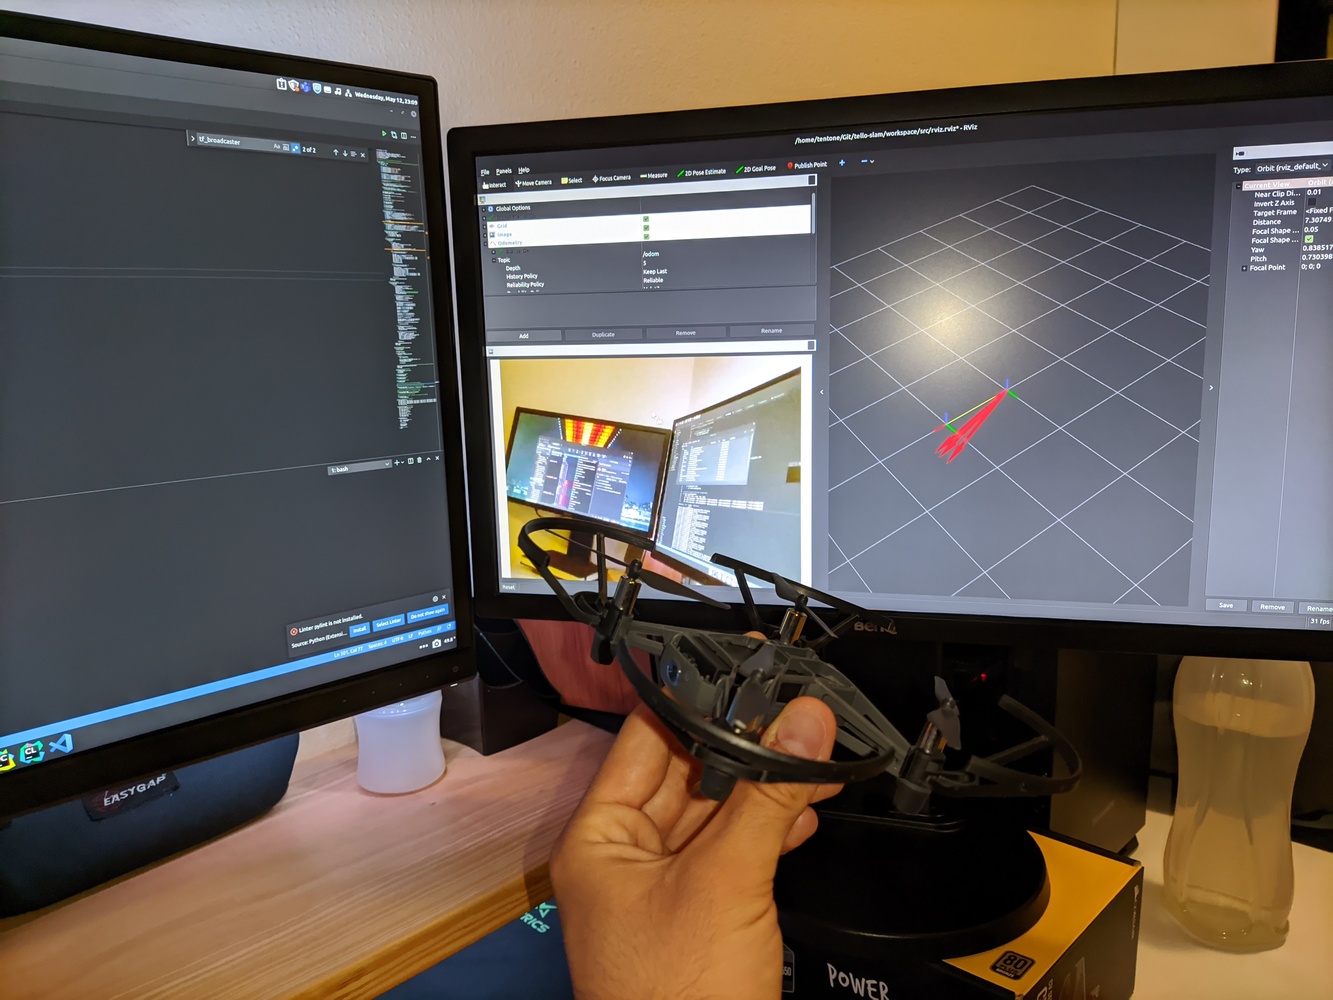
tello-ros2
ROS2 node for DJI Tello and Visual SLAM for mapping of indoor environments.
- 217
- C++
- MIT
- 3 y ago


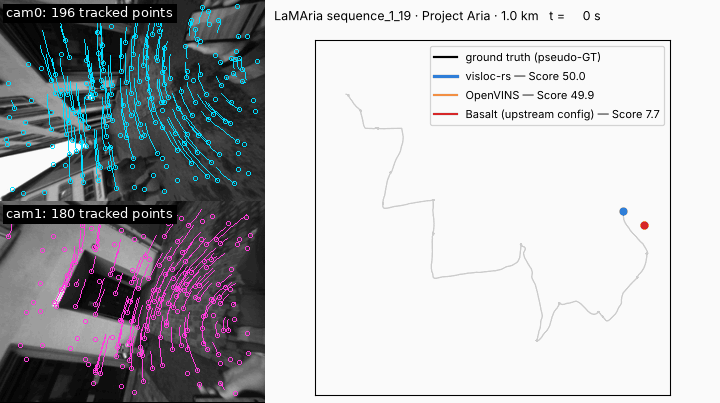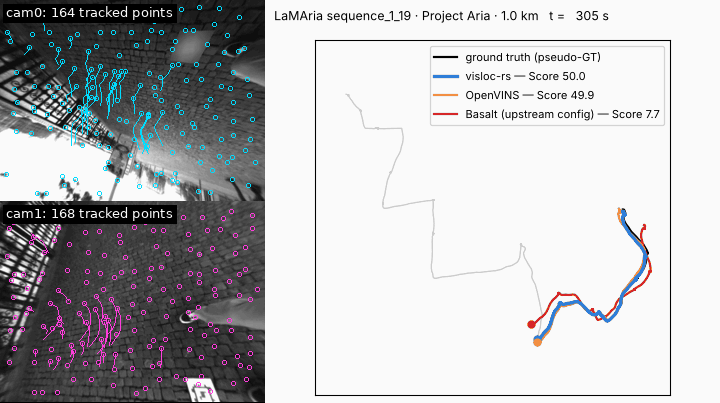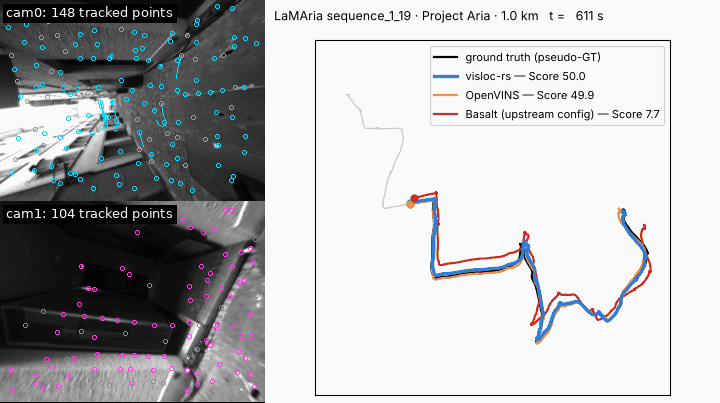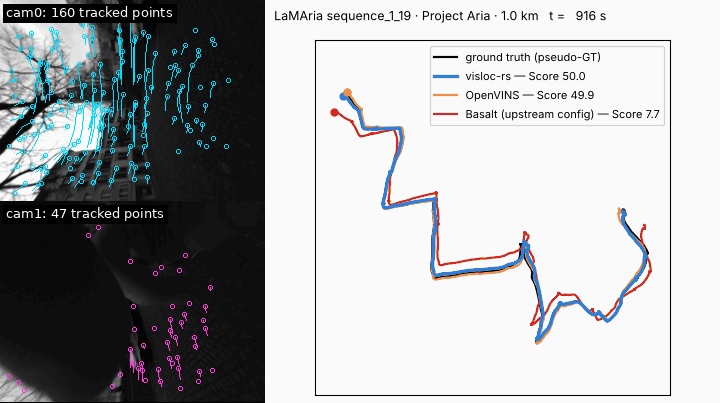
visloc-rs
SfM, MVS, visual-inertial SLAM, 3D Gaussian Splatting and map-based localization in Rust
- 178
- Rust
- 12 h ago
