hflow
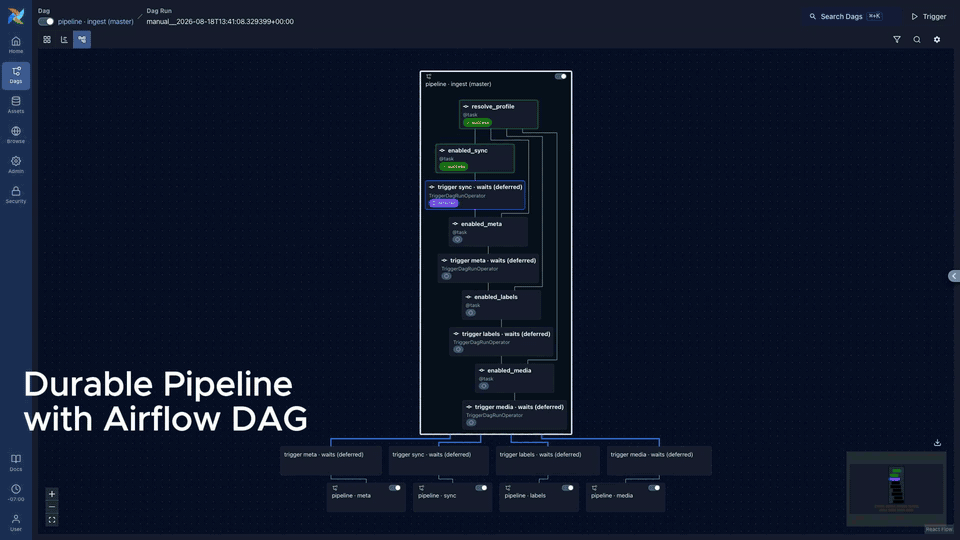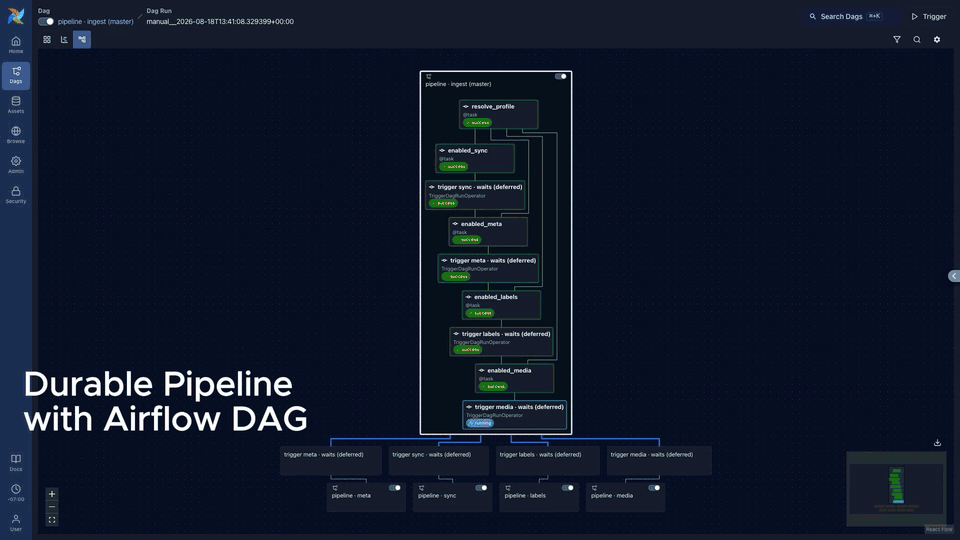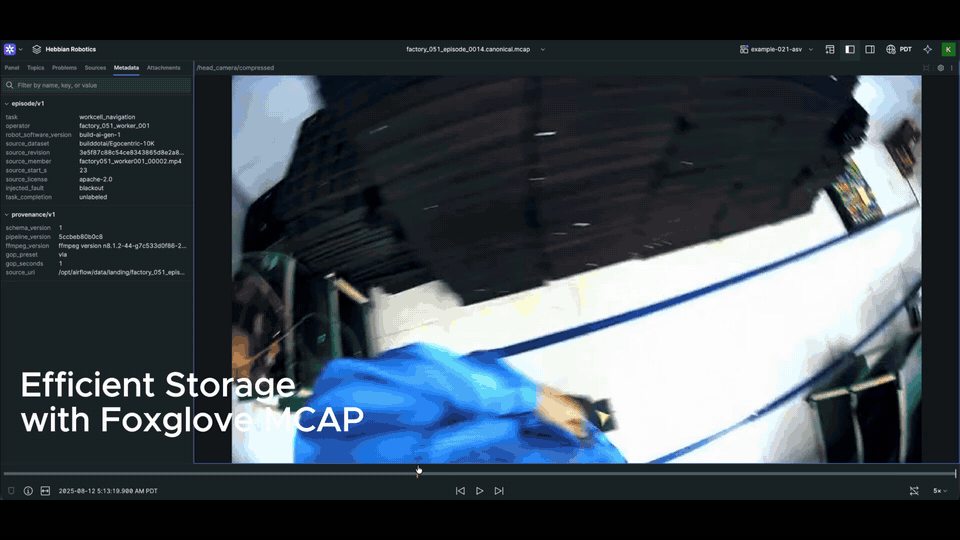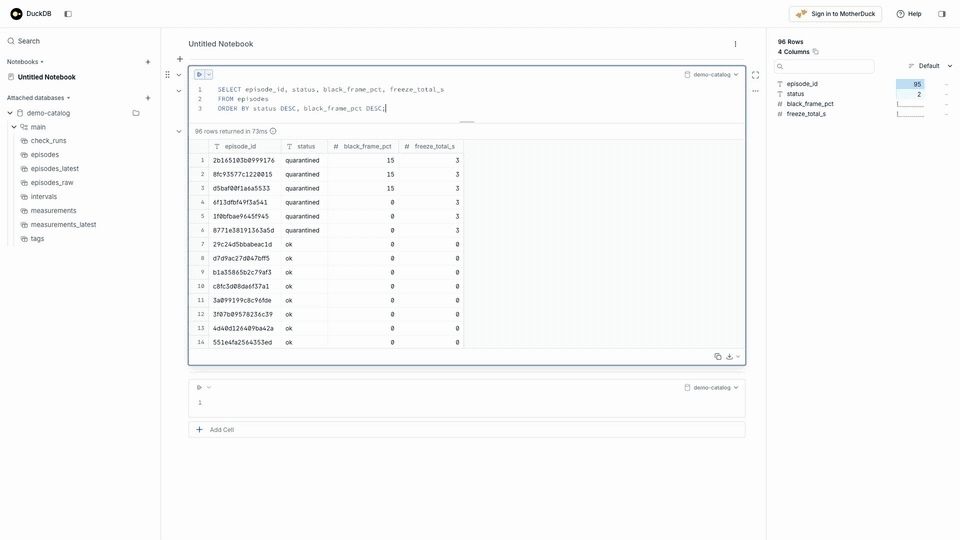
SDK for robotics teams to verify the quality of their data used for AI model training.
- 311
- Python
- Apache-2.0
- 4 d ago
SDK for robotics teams to verify the quality of their data used for AI model training.
Cerulion (YC S24) gives AI agents a harness to control real robots. Our open-source runtime and harness give any AI agent a physical body, inside safety limits the robot enforces, and tools to autonomously debug recorded robot failures. It's ROS 2 compatible.
A dashcam for your robot: ROS 2 recording that keeps the seconds before the moment that matters. v2: describe events in plain English and a vision-language model saves the clips.
Rust and Python tools for standard MCAP files: grouped writing, ROS 2 and Foxglove message encoding, and camera video export to MP4.
Veridex is the trust certificate for physical-AI data that tells you, across any format, whether the robot or sensor dataset you're about to train on is clean, correctly synchronized, and traceable to its source, before it silently wrecks your model.
Find bad ROS 2 recordings before they become bad datasets. Checks SQLite3 and MCAP bags for timing gaps, bad rates, timestamp problems, coverage, and sensor sync.
Time-aligned multi-sensor capture kernel for Android: camera, IMU, GNSS and audio on one BOOTTIME clock, straight to an MCAP file that opens in Foxglove with zero manual offset.