pcl


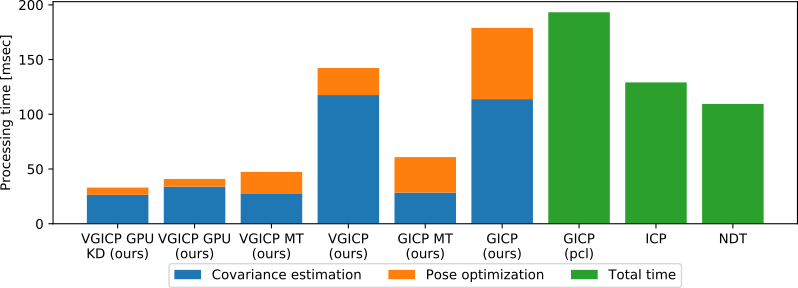
fast_gicp
A collection of GICP-based fast point cloud registration algorithms
- 1.7k
- C++
- BSD-3-Clause
- 19 mo ago

small_gicp
Efficient and parallel algorithms for point cloud registration [C++, Python]
- 1.1k
- C++
- MIT
- 7 wk ago

lidar_obstacle_detector
Real-time 3D LiDAR obstacle detection, tracking & trajectory prediction for ROS 1 / ROS 2: ground segmentation, clustering, 2.5D occupancy, optional GPU CenterPoint (TensorRT). ~10 ms/scan on one CPU core.
- 424
- C++
- MIT
- 4 wk ago

plane_fit_ground_filter
点云分割论文2017 Fast segmentation of 3d point clouds: A paradigm on lidar data for autonomous vehicle applications
- 145
- C++
- BSD-3-Clause
- 2 y ago

linefit_ground_segmentation_details
快速3D点云分割论文代码(带注解):Fast segmentation of 3d point clouds for ground vehicles
- 102
- C++
- BSD-3-Clause
- 2 y ago
UR3_ROS2_PICK_AND_PLACE
UR3 robotic arm pick-and-place stack for ROS2 Humble: MoveIt 2 + MoveIt Task Constructor, Gazebo Harmonic simulation, Robotiq/OnRobot grippers, dual-arm support, BehaviorTree.CPP task planning, perception, LLM-driven commands, and RL policies.
- 72
- C++
- MIT
- 4 d ago


SimpleTreeHeight
A simple algorithm for extracting tree height in sparse scene from point cloud data.
- 10
- Python
- MIT
- 5 y ago

