openarm
A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.
- 3.7k
- MDX
- Apache-2.0
- 6 d ago
A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.
PAROL6: open-source 3D-printed 6-axis desktop robot arm. BOM, STL and STEP files, firmware and build instructions.
Motion Generation for Robots and Machines. Real-time. Jerk-constrained. Time-optimal.
Easy to use and accurate hand eye calibration which has been working reliably for years (2016-present) with kinect, kinectv2, rgbd cameras, optical trackers, and several robots including the ur5 and kuka iiwa.
Build environment and train a robot arm from scratch (Reinforcement Learning)
An open-source SO-ARM102 robot arm, successor to SO-ARM100 and SO-ARM101. LeRobot-compatible leader-follower kit for teleoperation and imitation learning, with improved rigidity, parallel gripper, STEP/STL files and BOM.
This repository compiles a list of papers related to the application of video technology in the field of robotics! Star⭐ the repo and follow me if you like what you see🤩.
UR3 robotic arm pick-and-place stack for ROS2 Humble: MoveIt 2 + MoveIt Task Constructor, Gazebo Harmonic simulation, Robotiq/OnRobot grippers, dual-arm support, BehaviorTree.CPP task planning, perception, LLM-driven commands, and RL policies.
Открытый курс: собери первого робота и войди в робототехнику с нуля за 6 месяцев. Электроника → Arduino/ESP32 → CAD и 3D-печать → рука SO-101 → ROS 2 (SLAM, Nav2) → PID/LQR, CV → LeRobot. 100+ ресурсов, схемы, готовый код, железо на 3 бюджета, план по неделям и 30 идей проектов
Autonomous AI-powered tank platform for the homestead — YOLOv8 detection, depth AI, and a 24V LiFePO4 1kW drivetrain. Full chassis build and wiring.
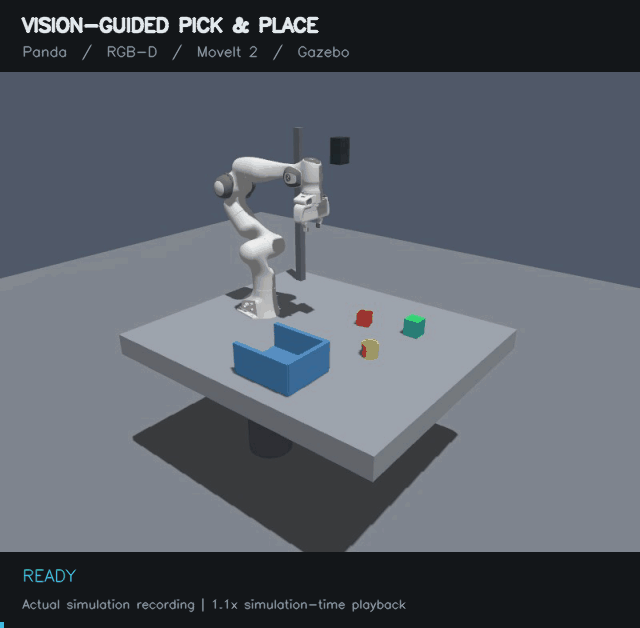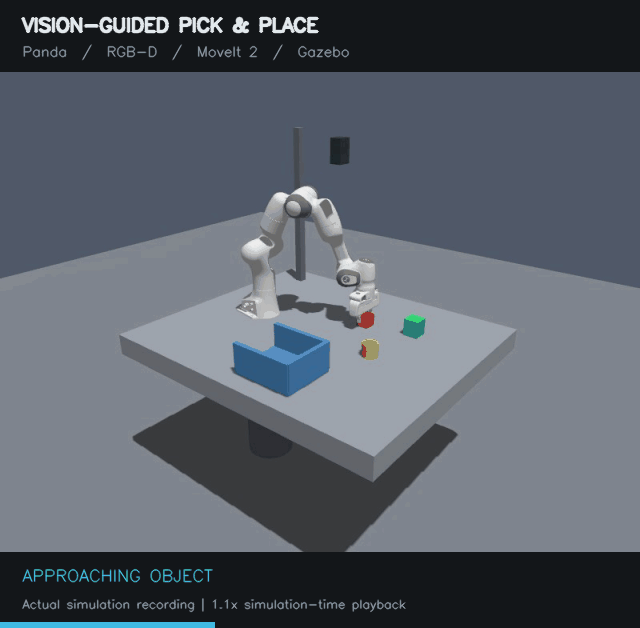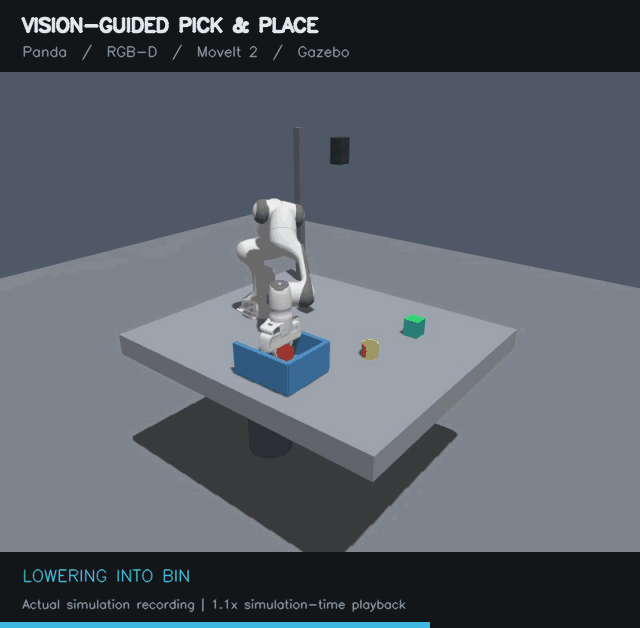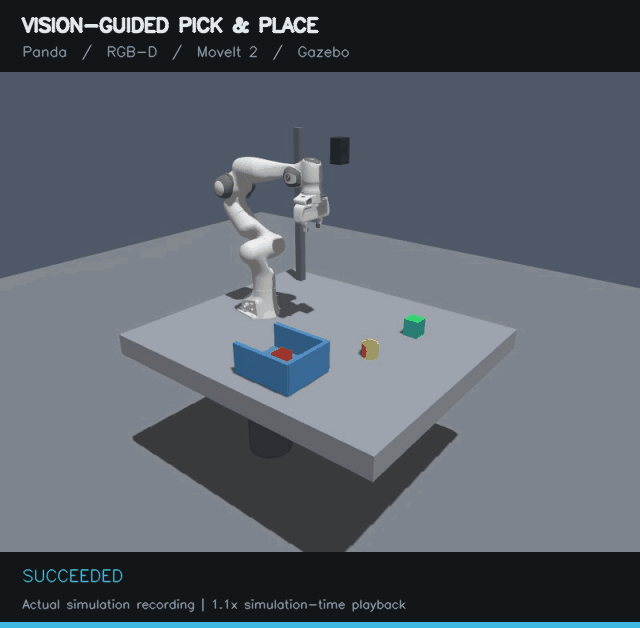
ROS 2 vision-guided pick-and-place simulation with a Panda arm, RGB-D perception, MoveIt 2, and Gazebo.
Tools to set up, repair, and run the Seeed SO-ARM101 robot arm on LeRobot without brownouts.