pinocchio
A fast and flexible implementation of Rigid Body Dynamics algorithms and their analytical derivatives
- 3.9k
- C++
- BSD-2-Clause
- 8 d ago
A fast and flexible implementation of Rigid Body Dynamics algorithms and their analytical derivatives
Central repository for tools, tutorials, resources, and documentation for robotics simulation in Unity.
Fast symbolic computation, code generation, and nonlinear optimization for robotics
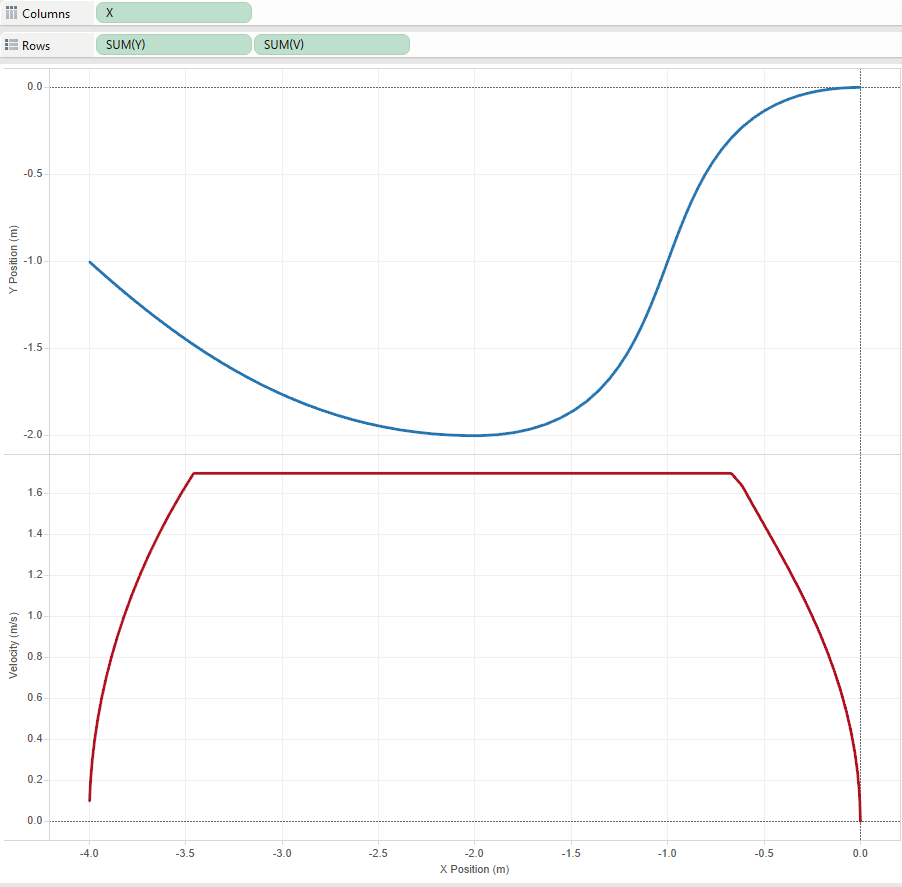
Motion Generation for Robots and Machines. Real-time. Jerk-constrained. Time-optimal.
Crocoddyl is an optimal control library for robot control under contact sequence. Its solver is based on various efficient Differential Dynamic Programming (DDP)-like algorithms
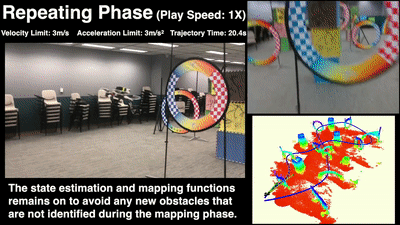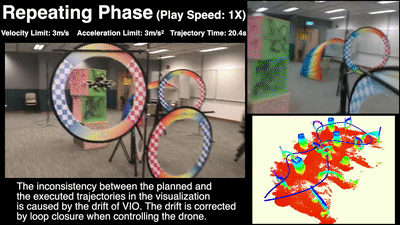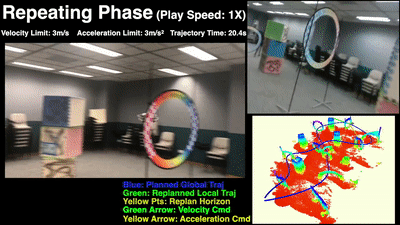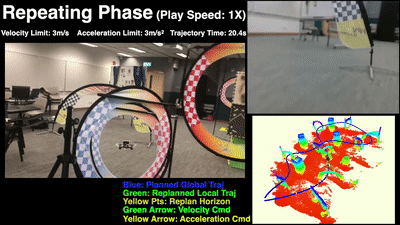
Teach-Repeat-Replan: A Complete and Robust System for Aggressive Flight in Complex Environments
A light-weight, Eigen-based C++ library for trajectory optimization for legged robots.
[ICLR 2025 Oral] The official implementation of "Diffusion-Based Planning for Autonomous Driving with Flexible Guidance"
Summary of key papers and blogs about diffusion models to learn about the topic. Detailed list of all published diffusion robotics papers.
[ICRA'24 Best UAV Paper Award Finalist] An Efficient Global Planner for Aerial Coverage
Open-source Autonomy Software in Rust-lang using gRPC for the Roomba series robot vacuum cleaners. Under development.
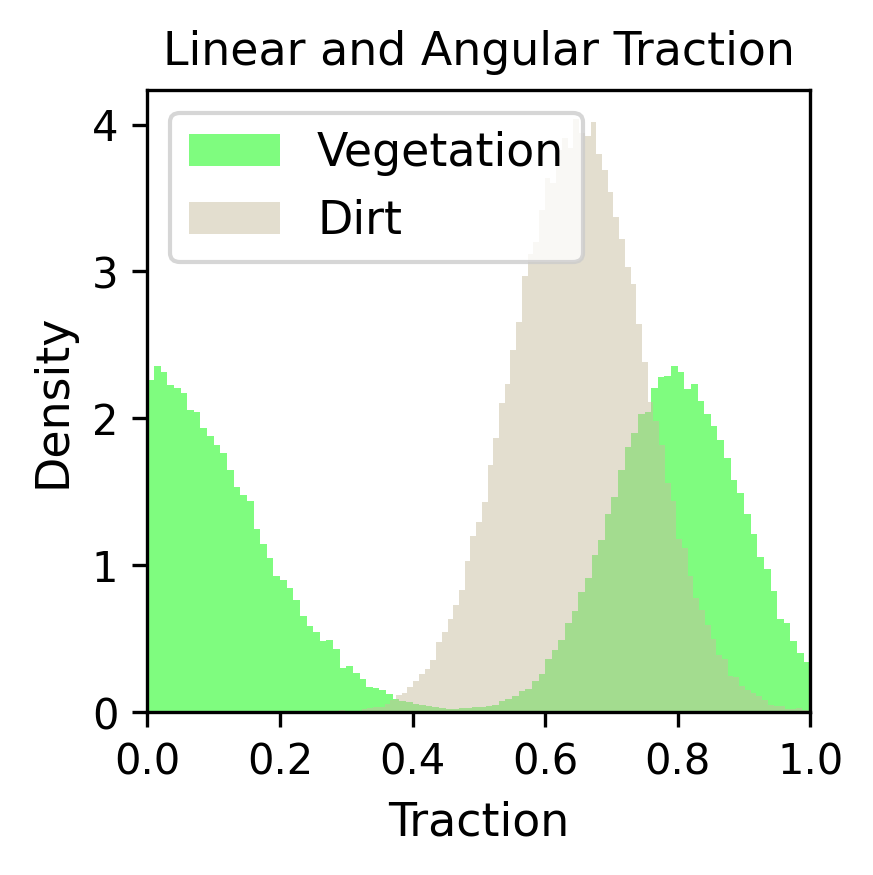
A GPU implementation of Model Predictive Path Integral (MPPI) control that uses a probabilistic traversability model for planning risk-aware trajectories.
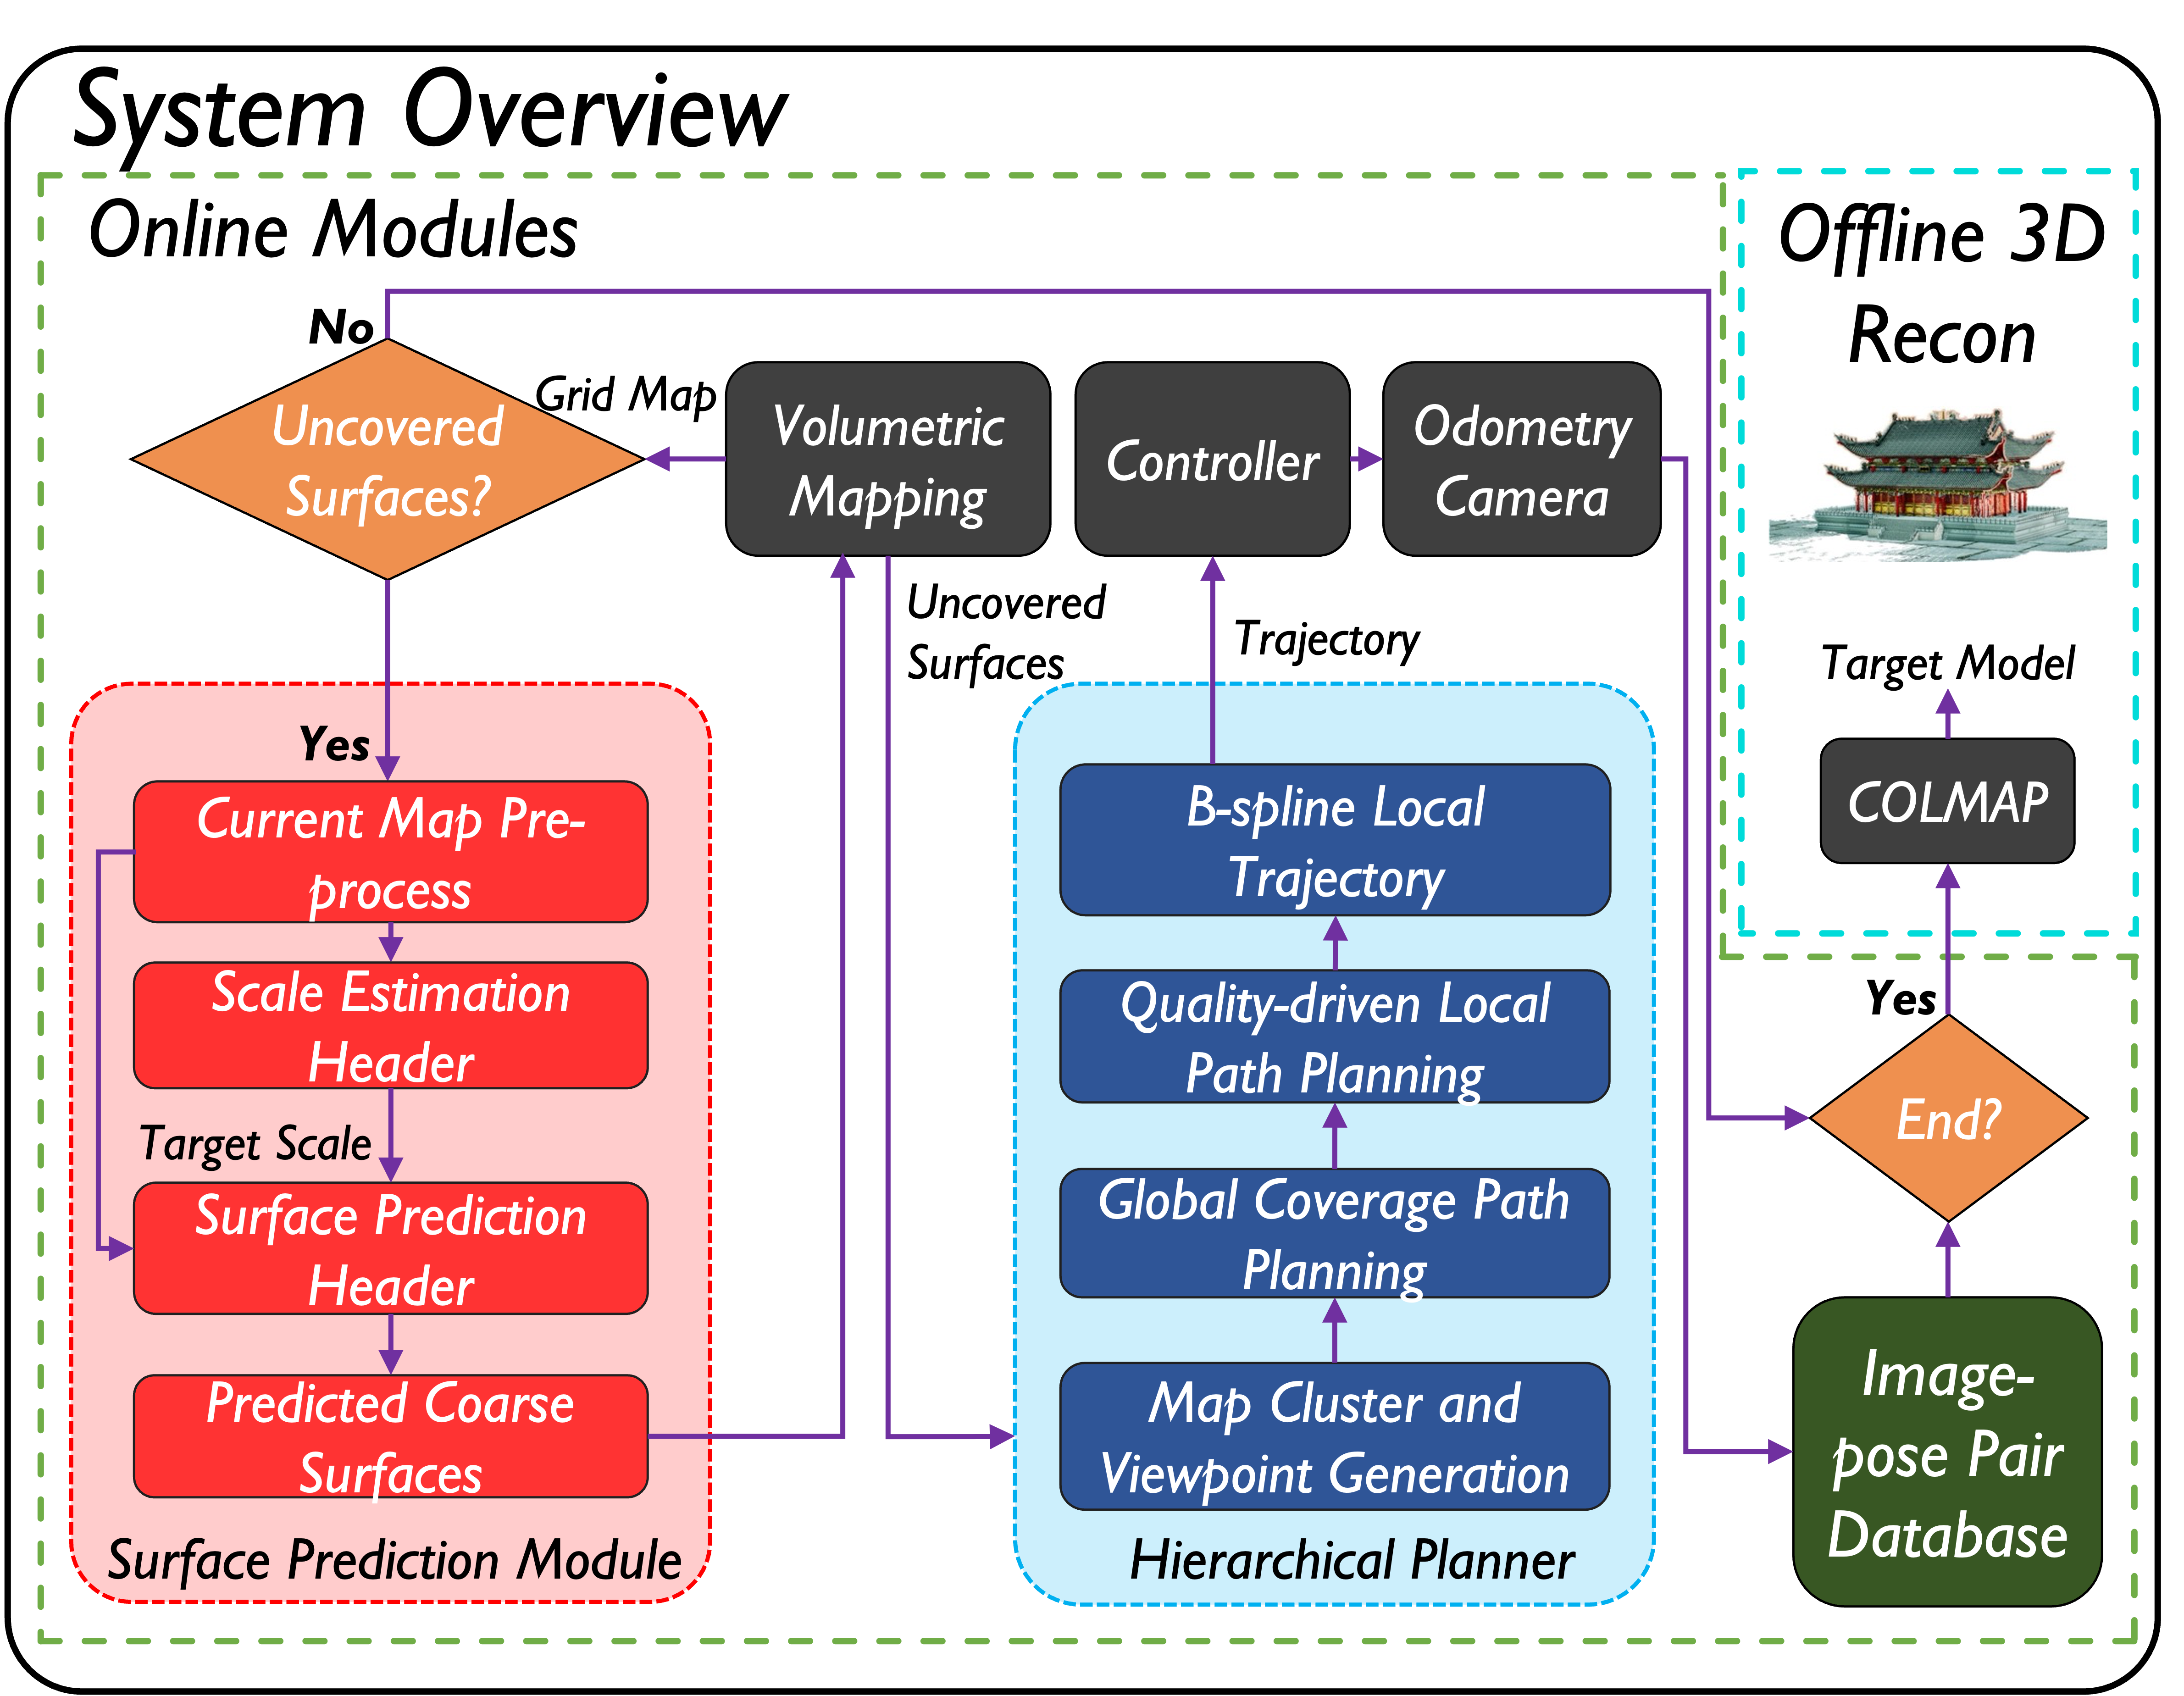
[ICRA'23] A Prediction-boosted Planner for Fast and High-quality Autonomous Aerial Reconstruction
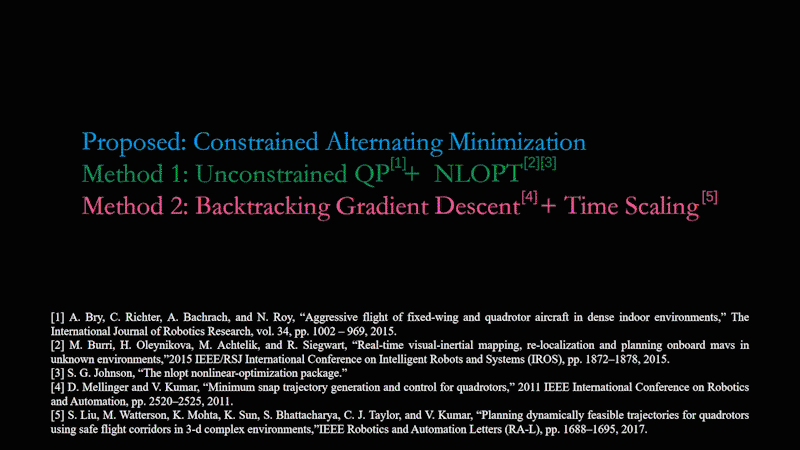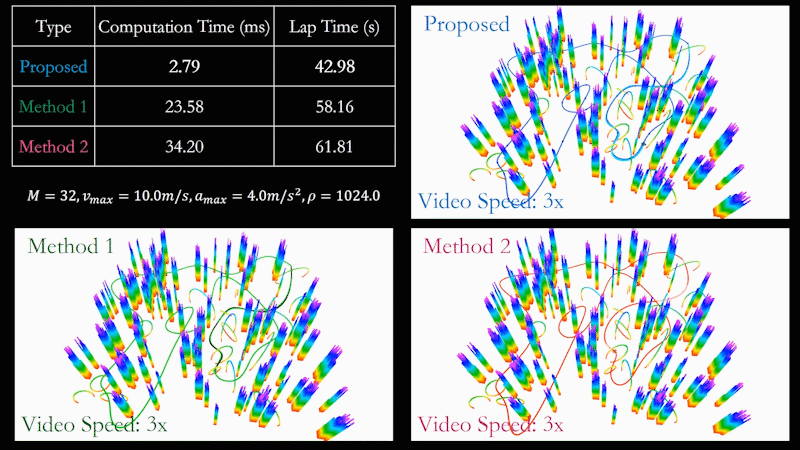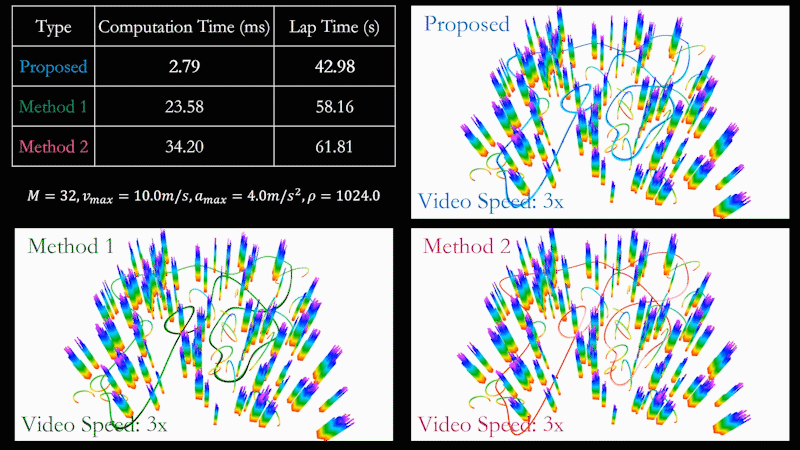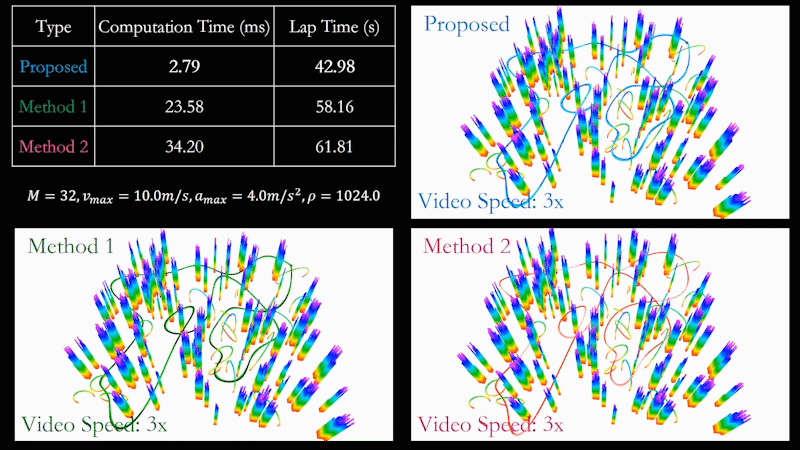
Alternating Minimization Based Trajectory Generation for Quadrotor Aggressive Flight
FISS & FISS+: Fast Iterative Search and Sampling trajectory planners for autonomous driving (with FOP baselines). C++17 core, Python, ROS 2 / ROS 1, Lanelet2, CARLA, MPC
A unified end-to-end learning and control framework that is able to learn a (neural) control objective function, dynamics equation, control policy, or/and optimal trajectory in a control system.
A curated collection of papers, seminars, courses, and technical resources for robotic research.
Dockerized ROS2 stack for the WATonomous Autonomous Driving Software Pipeline
Code accompanying the RA-L / ICRA 2020 paper: "Online Trajectory Generation with Distributed Model Predictive Control for Multi-Robot Motion Planning"
A robust UAV local planner based on the ICRA2020 paper: Robust Real-time UAV Replanning Using Guided Gradient-based Optimization and Topological Paths
Algorithm and model experiments for robot motion planning. Implemented in Julia.
Telekinesis Agentic Skill Library: build AI-powered Computer Vision, Robotics and Physical AI applications.
Text generation model, used with transformers.
Text generation model, used with peft.