lidar_camera_calibration
ROS package to find a rigid-body transformation between a LiDAR and a camera for "LiDAR-Camera Calibration using 3D-3D Point correspondences"
- 1.8k
- C++
- GPL-3.0
- 13 mo ago
ROS package to find a rigid-body transformation between a LiDAR and a camera for "LiDAR-Camera Calibration using 3D-3D Point correspondences"
点云分割论文2017 Fast segmentation of 3d point clouds: A paradigm on lidar data for autonomous vehicle applications
快速3D点云分割论文代码(带注解):Fast segmentation of 3d point clouds for ground vehicles
🌐 A ROS WEB console to control remotely your robot. Based with robotwebtools.
Simple differential drive robot for indoor environments simulated using ROS and Gazebo.
A basic example of using Gazbo+ROS with C++ to control a quadrotor UAV using basic PID control
Robot Operating System course provided by Udemy and the author is Anis Koubaa. Project contains ROS basic file system, ROS Service, ROS Message, ROS Communication etc and C++ & python both programming languages are used.
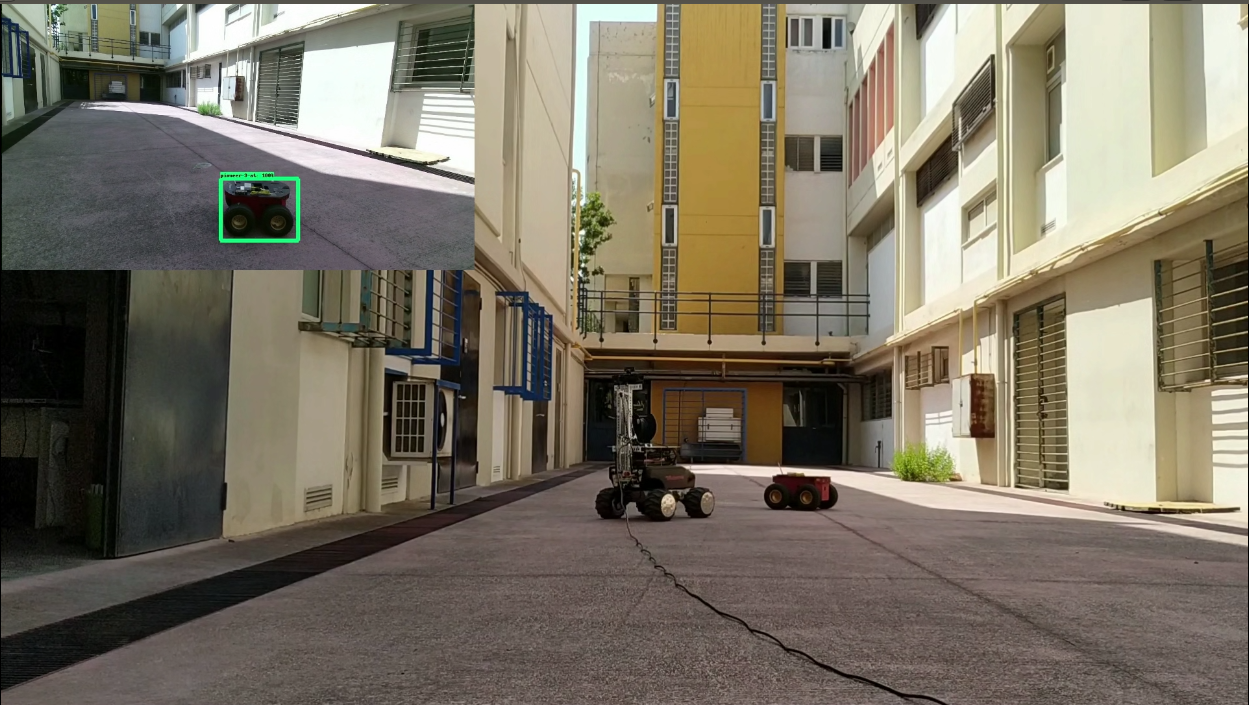
A Leader-Follower Mobile Robot Scheme using an RGB-D Camera and MobileNets
Simulation of different natural and artificial gaits of a snake in ROS using ROS control
A basic example of using PID control to mave a mass to a desired position using Gazebo with C++
This is a simple example to run publisher and subscriber in ROS Melodic.