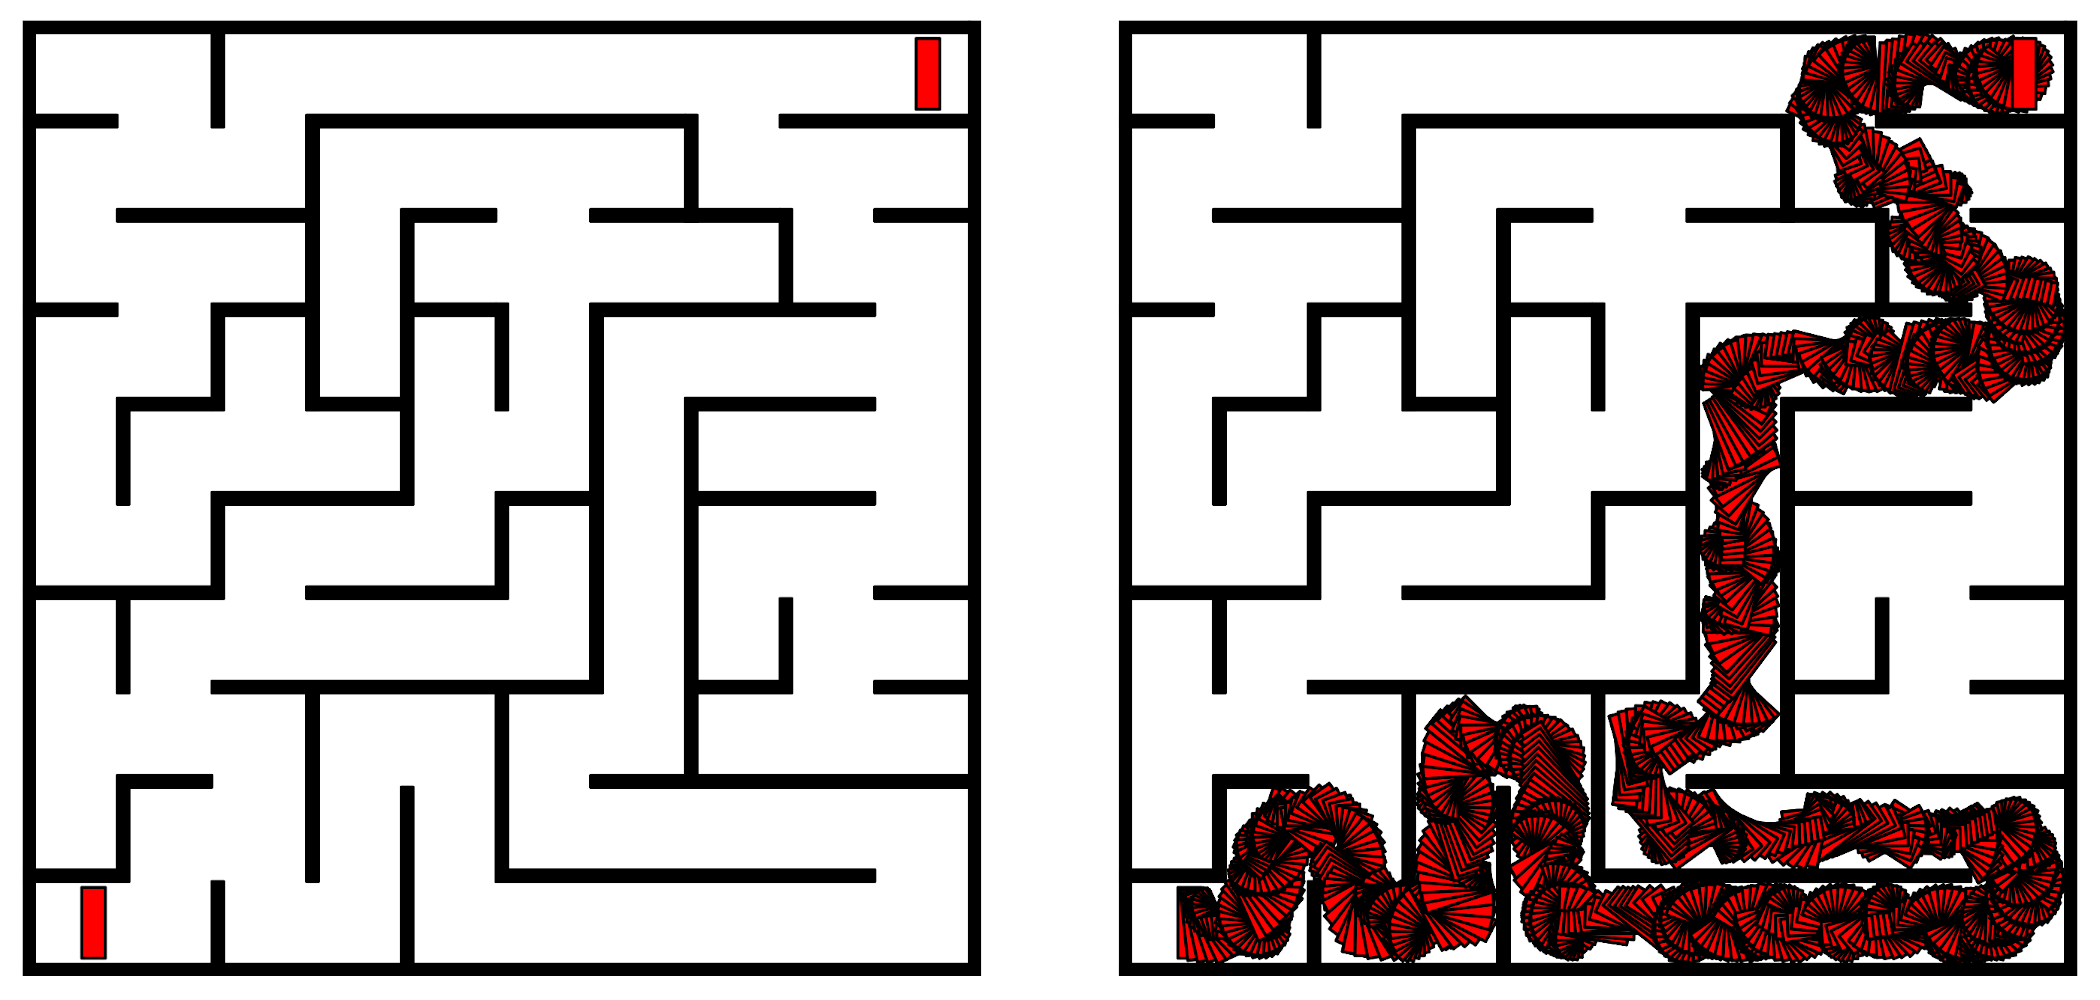
Dstar-lite-pathplanner
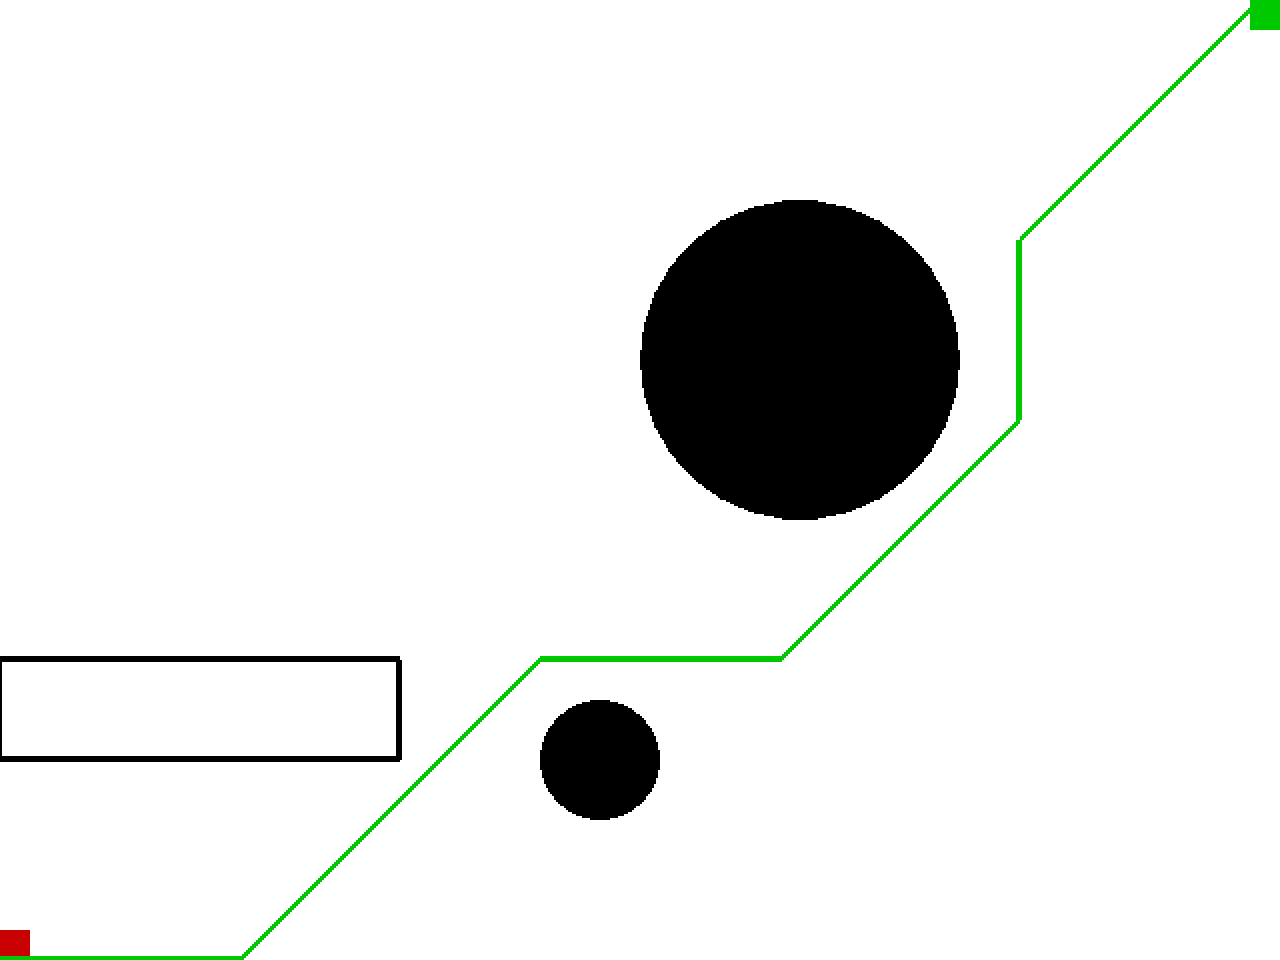
Implementation of the D* lite algorithm in Python for "Improved Fast Replanning for Robot Navigation in Unknown Terrain"
- 198
- Python
- MIT
- 3 y ago
Implementation of the D* lite algorithm in Python for "Improved Fast Replanning for Robot Navigation in Unknown Terrain"
Telekinesis Agentic Skill Library: build AI-powered Computer Vision, Robotics and Physical AI applications.
LQR-RRT* method is used for random motion planning of a simple pendulum in it's phase plot
This repo implemented the core technology of the self-driving car, including the basic concepts such as path tracking, path planning, SLAM, etc., and deep learning techniques such as computer vision and reinforcement learning. Finally, we practiced with NVIDIA JetBot in both the simulator and the real world.
Robot motion planning via "Dynamic Region-biased Rapidly-exploring Random Trees".