trajectory-optimization

control-toolbox
The Control Toolbox - An Open-Source C++ Library for Robotics, Optimal and Model Predictive Control
- 1.7k
- C++
- BSD-2-Clause
- 4 y ago


crocoddyl
Crocoddyl is an optimal control library for robot control under contact sequence. Its solver is based on various efficient Differential Dynamic Programming (DDP)-like algorithms
- 1.3k
- C++
- BSD-3-Clause
- 4 d ago


towr
A light-weight, Eigen-based C++ library for trajectory optimization for legged robots.
- 1.1k
- C++
- BSD-3-Clause
- 4 y ago

CERLAB-UAV-Autonomy
[CMU] A Versatile and Modular Framework Designed for Autonomous Unmanned Aerial Vehicles [UAVs] (C++/ROS/PX4)
- 886
- C++
- MIT
- 20 mo ago

ifopt
An Eigen-based, light-weight C++ Interface to Nonlinear Programming Solvers (Ipopt, Snopt)
- 870
- C++
- BSD-3-Clause
- 13 mo ago


Pontryagin-Differentiable-Programming
A unified end-to-end learning and control framework that is able to learn a (neural) control objective function, dynamics equation, control policy, or/and optimal trajectory in a control system.
- 190
- Python
- MIT
- 4 mo ago


rmader
Decentralized Multiagent Trajectory Planner Robust to Communication Delay
- 130
- C++
- BSD-3-Clause
- 2 y ago
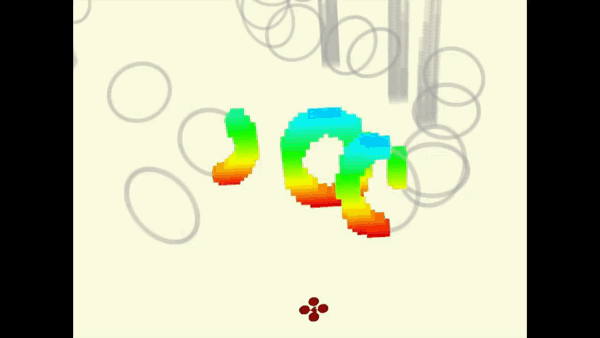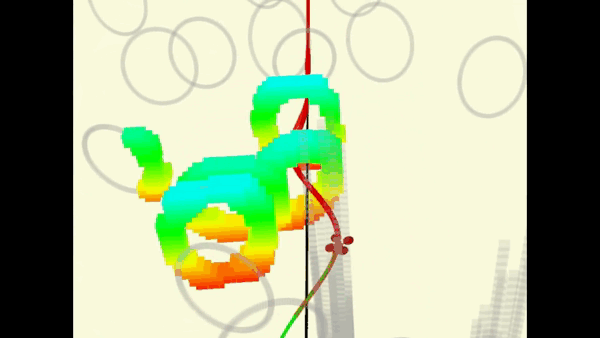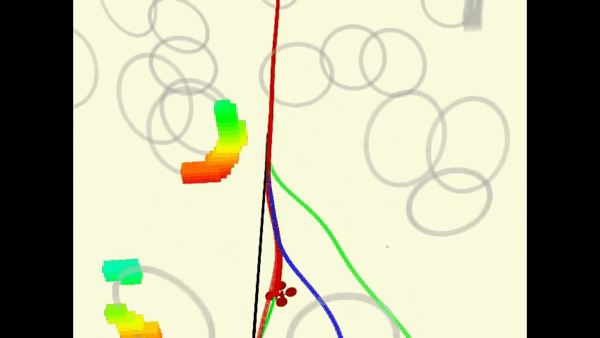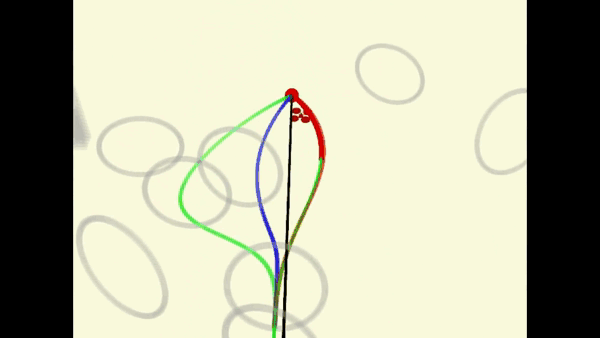
TopoTraj
A robust UAV local planner based on the ICRA2020 paper: Robust Real-time UAV Replanning Using Guided Gradient-based Optimization and Topological Paths
- 106
- 7 y ago

online_dmpc
Code accompanying the RA-L / ICRA 2020 paper: "Online Trajectory Generation with Distributed Model Predictive Control for Multi-Robot Motion Planning"
- 119
- C++
- MIT
- 6 y ago



deep_panther
- 86
- C++
- BSD-3-Clause
- 16 mo ago

optimization_dynamics
Implementation and examples from Trajectory Optimization with Optimization-Based Dynamics https://arxiv.org/abs/2109.04928
- 67
- Julia
- MIT
- 4 y ago


LearnOpt_Motion_Planning
Exploring Learning and Optimization for Robot Motion Planning and Control.
- 37
- Python
- 4 wk ago

DirectTrajectoryOptimization.jl
A Julia package for constrained trajectory optimization using direct methods.
- 29
- Julia
- MIT
- 4 y ago
Discrete-Mechanics-and-Optimal-Control
DMOC method for a simple pendulum swing-up control
- 7
- Matlab
- 10 y ago

gnco
Astrodynamics and trajectory calculation using integration and energy methods.
- 6
- Go
- BSD-3-Clause
- 4 mo ago

TrajOpt-KneedWalker
Finding a stable limit cycle for a passive kneed walker using trajectory optimization.
- 4
- Jupyter Notebook
- 6 y ago
CorridorKey-for-Nuke
Accelerate green screen keying in Nuke using TensorRT for real-time, high-quality foreground color and alpha matte extraction.
- 2
- C++
- 6 wk ago
