mighty
MIGHTY: Hermite spline-based real-time trajectory planner for single- and multi-agent UAVs and ground robots (ROS 2). Accepted to IEEE RA-L.
- 435
- C++
- BSD-3-Clause
- 5 wk ago
MIGHTY: Hermite spline-based real-time trajectory planner for single- and multi-agent UAVs and ground robots (ROS 2). Accepted to IEEE RA-L.
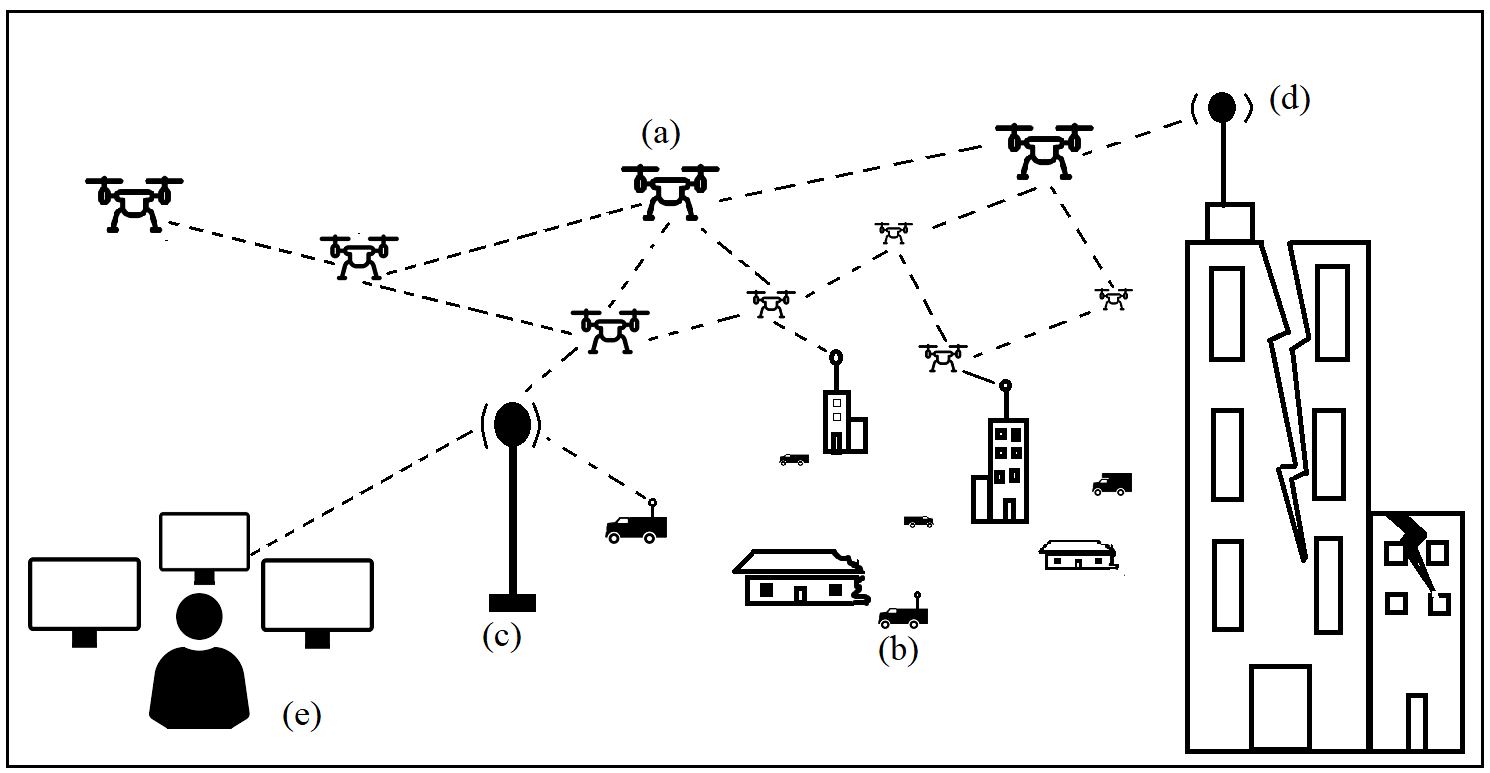
A Multi Hop Communication implementation using UAVs. The system would act as a delay tolerant network gathering messages from one location and delivering them to another. The Network is Ad-Hoc without the need for continuous communication between the UAVs.
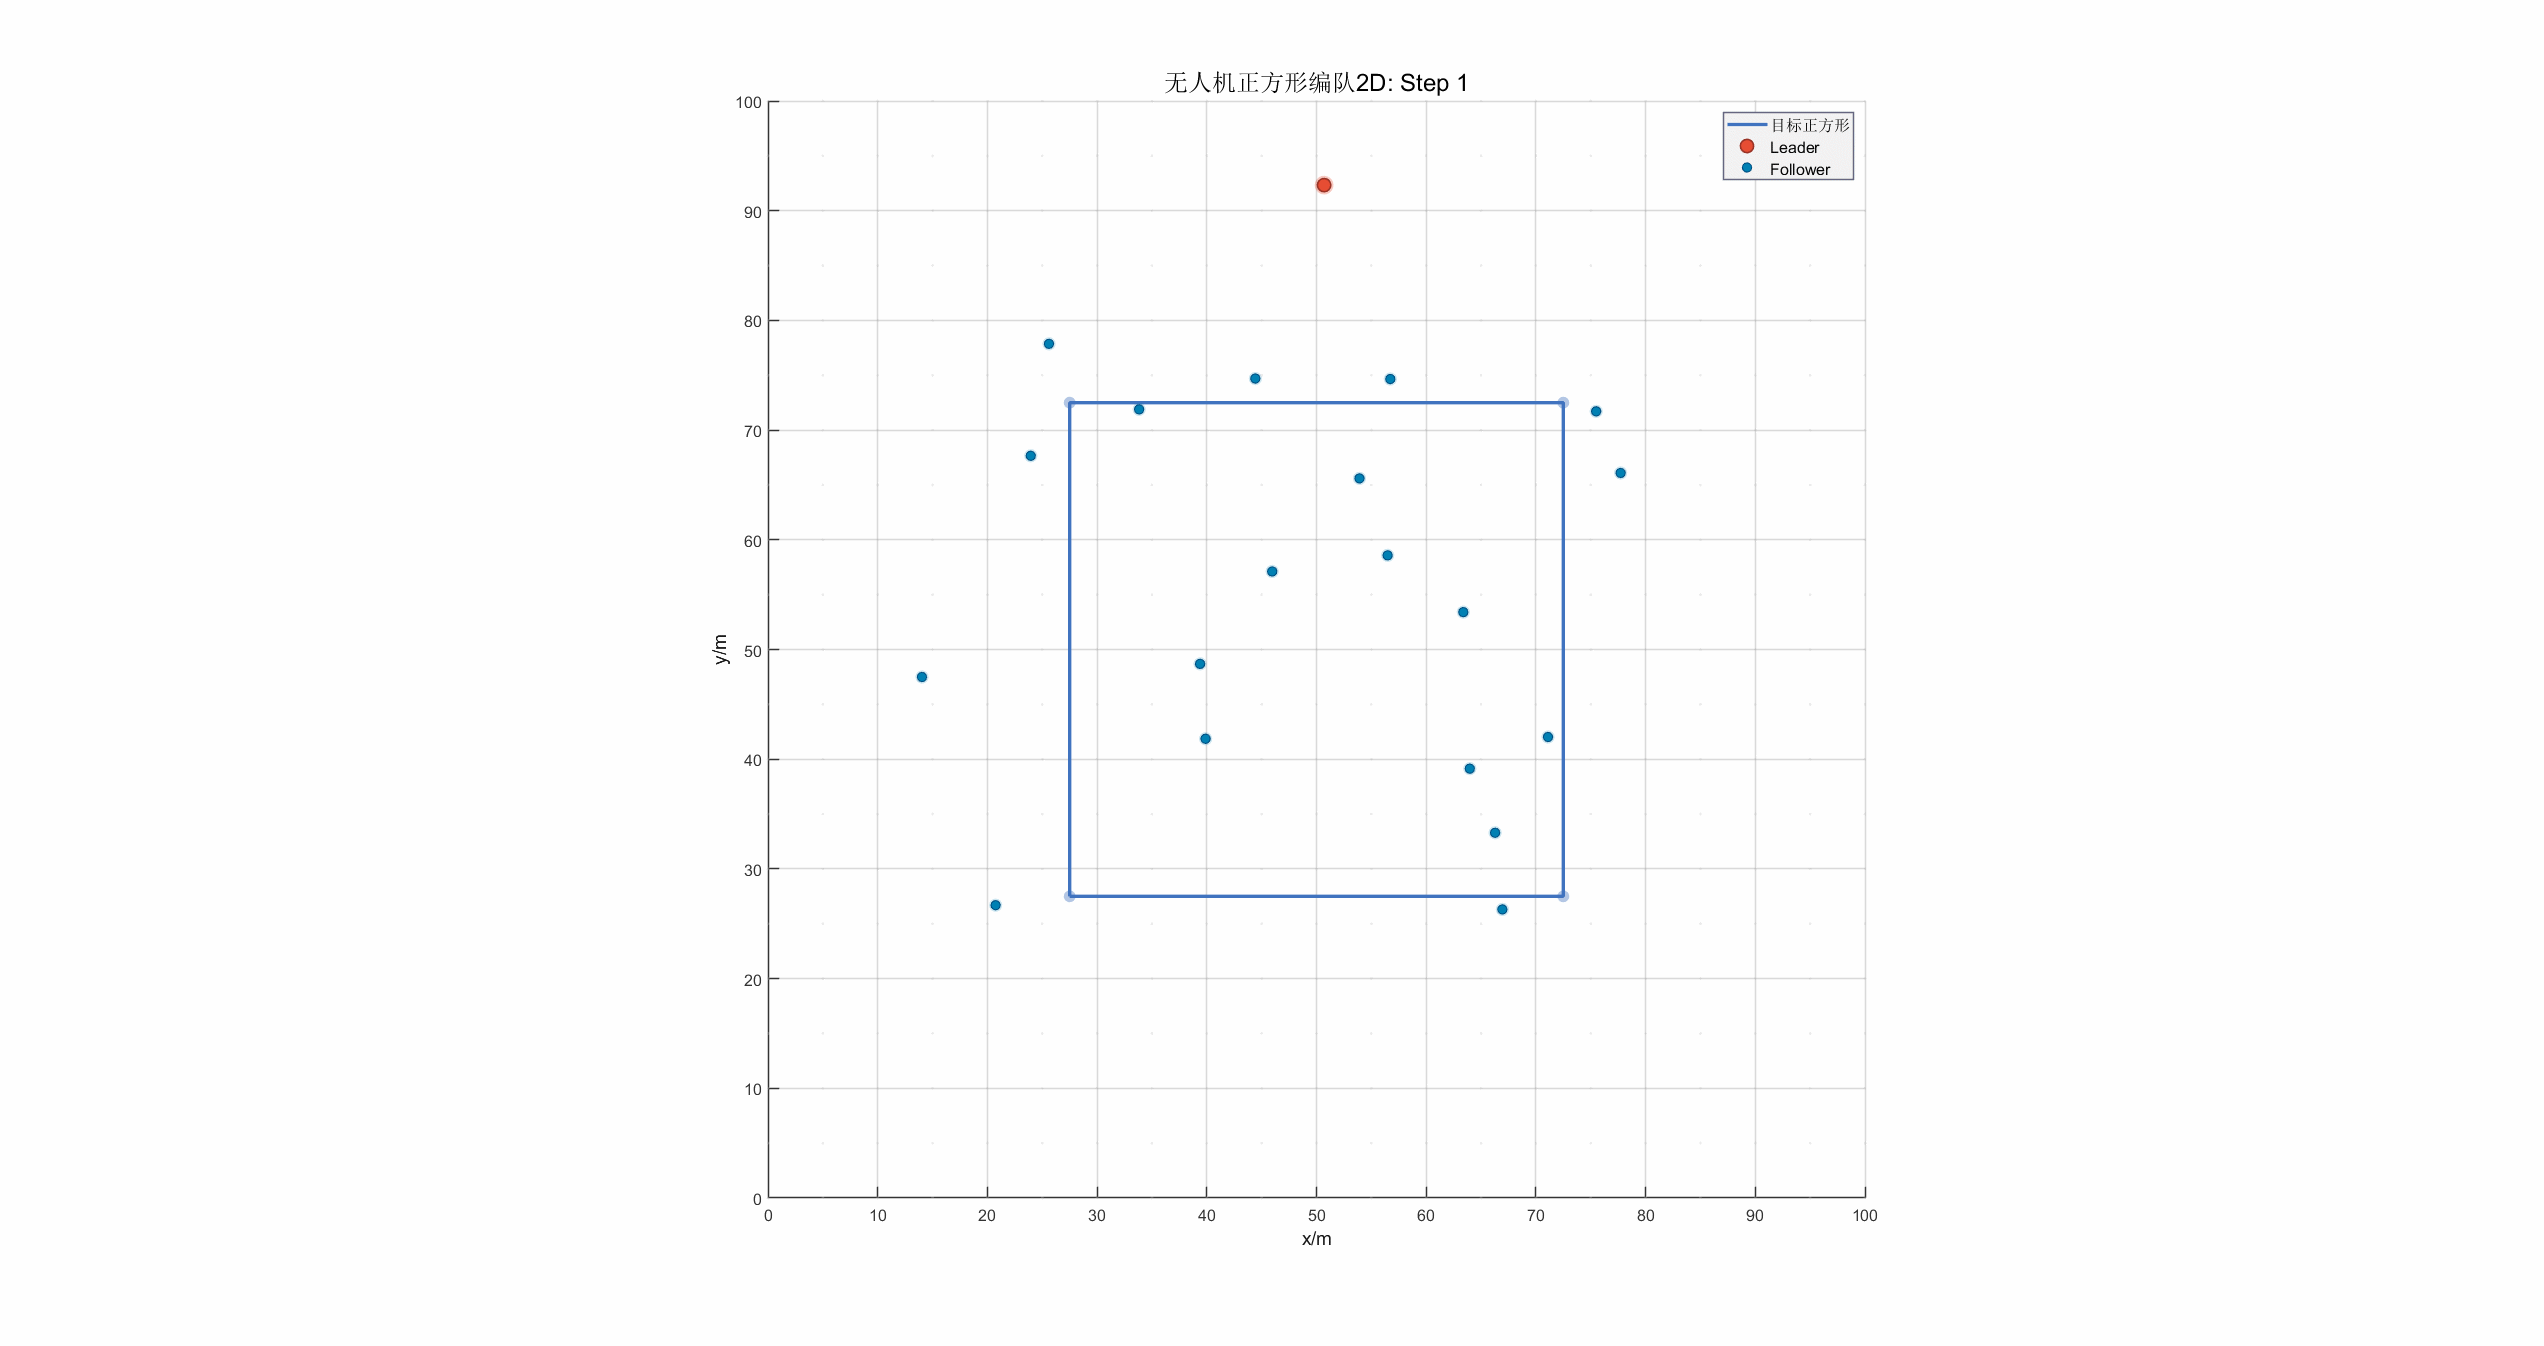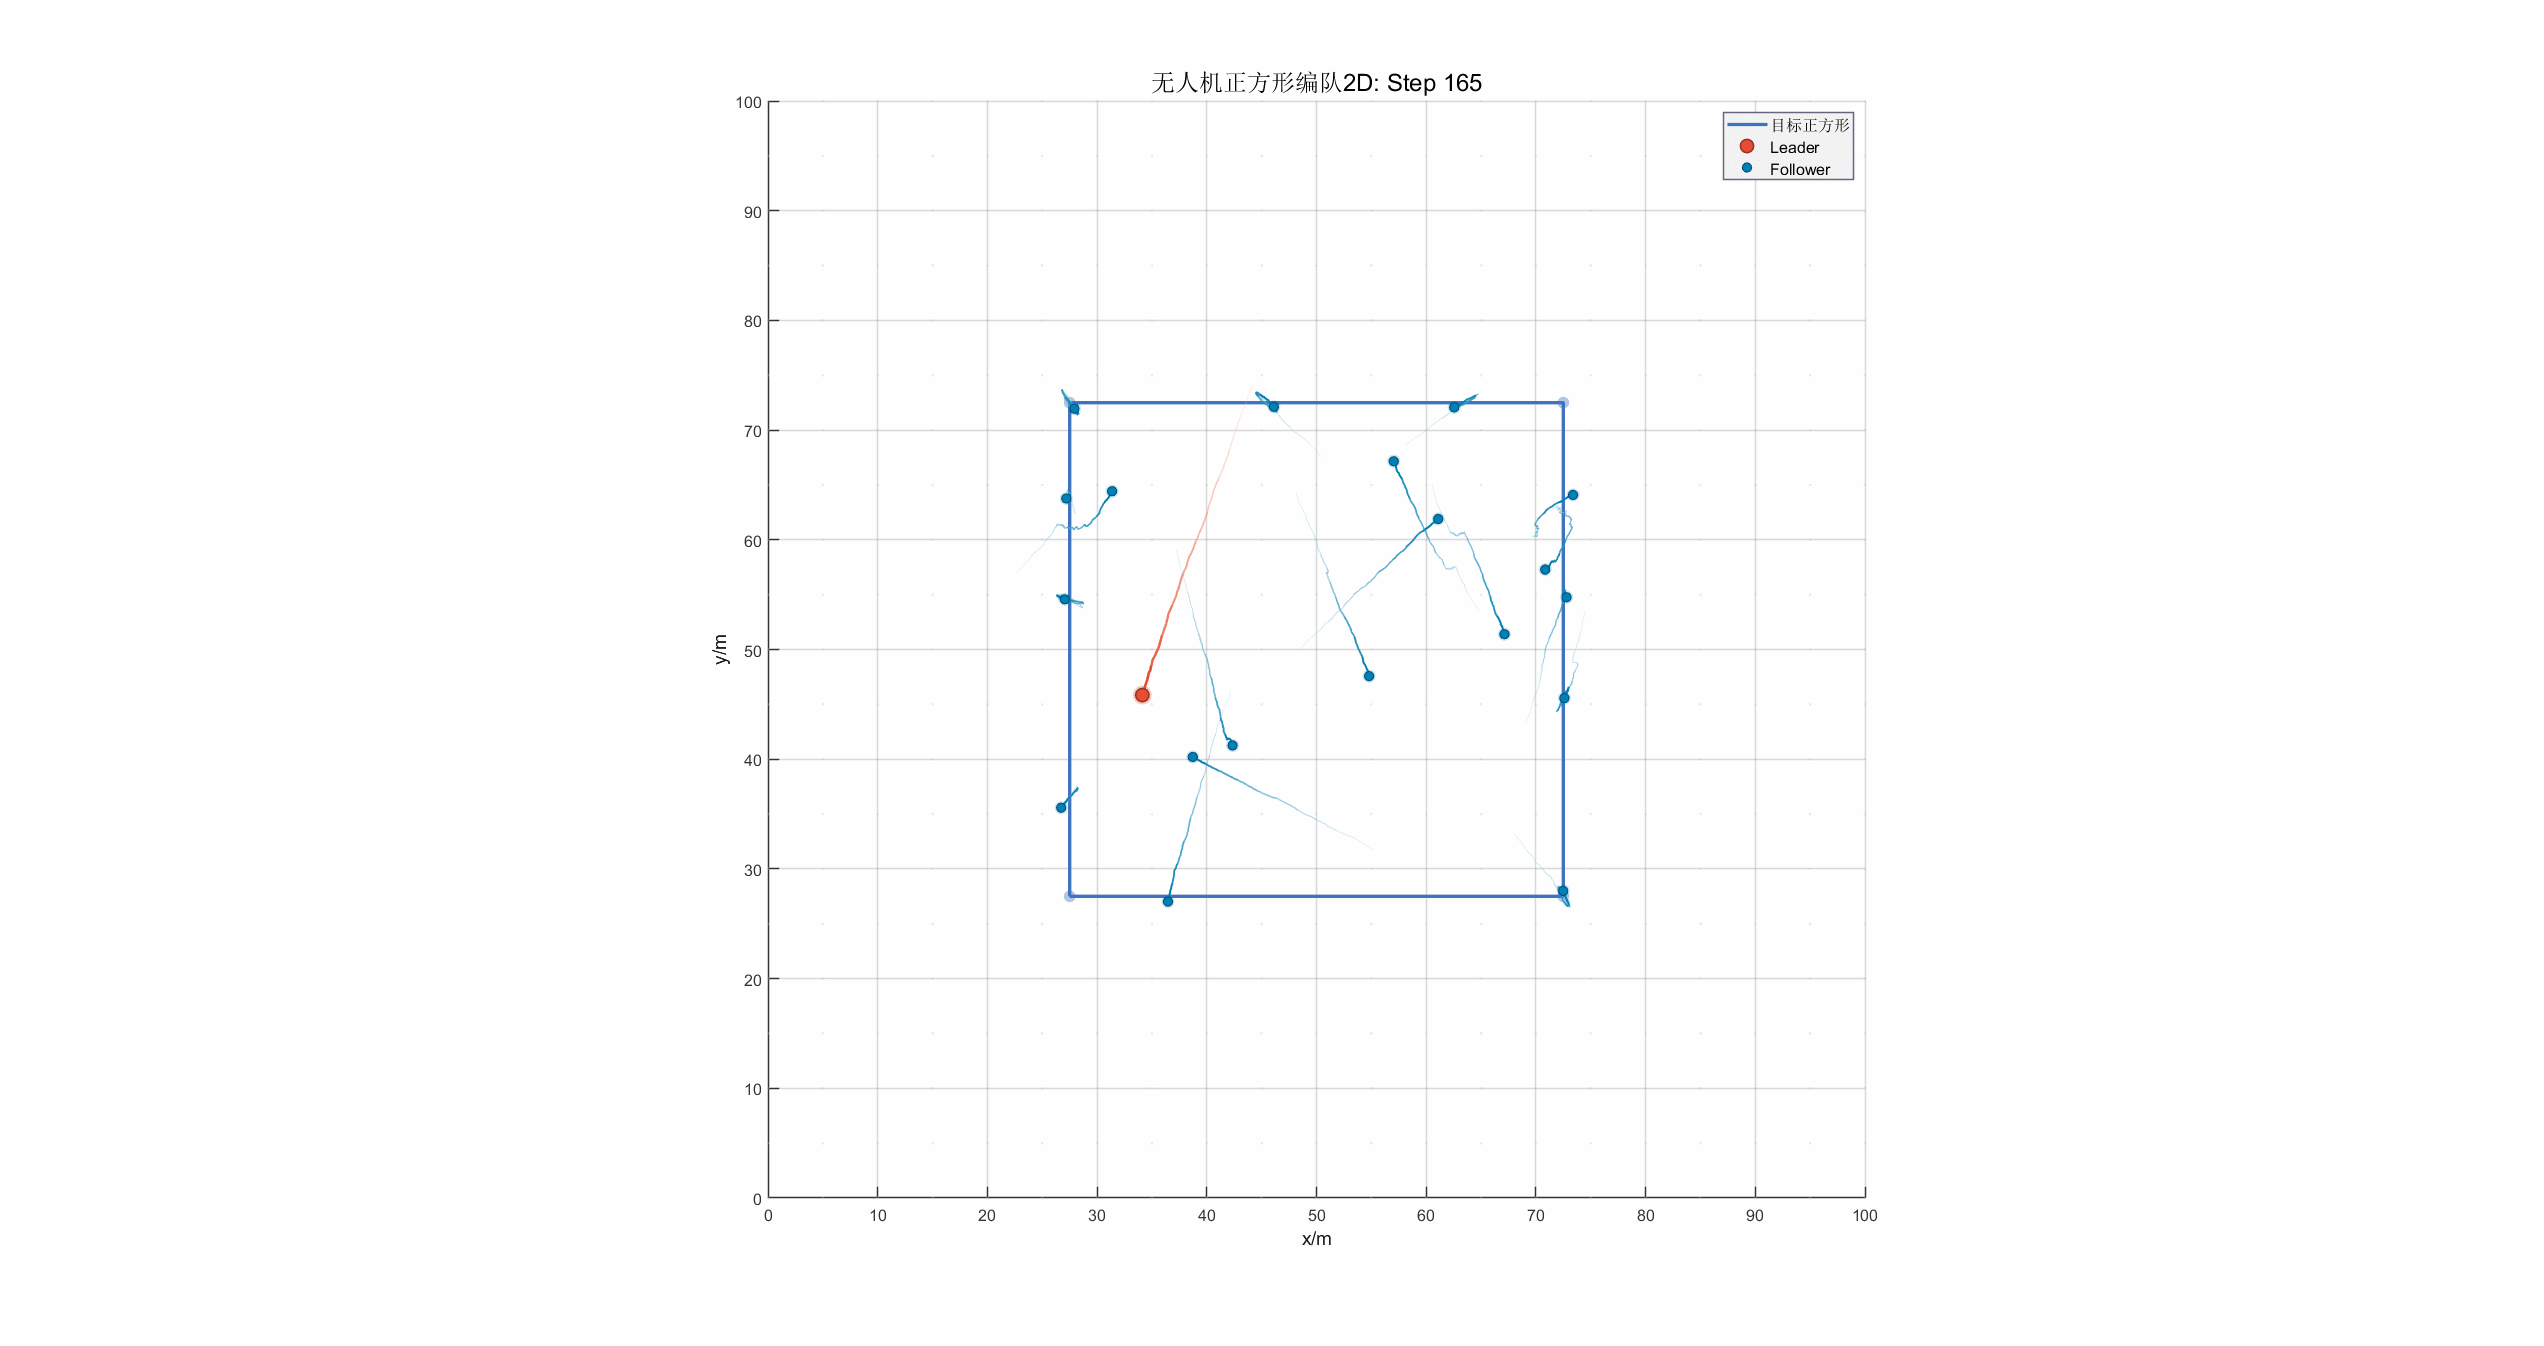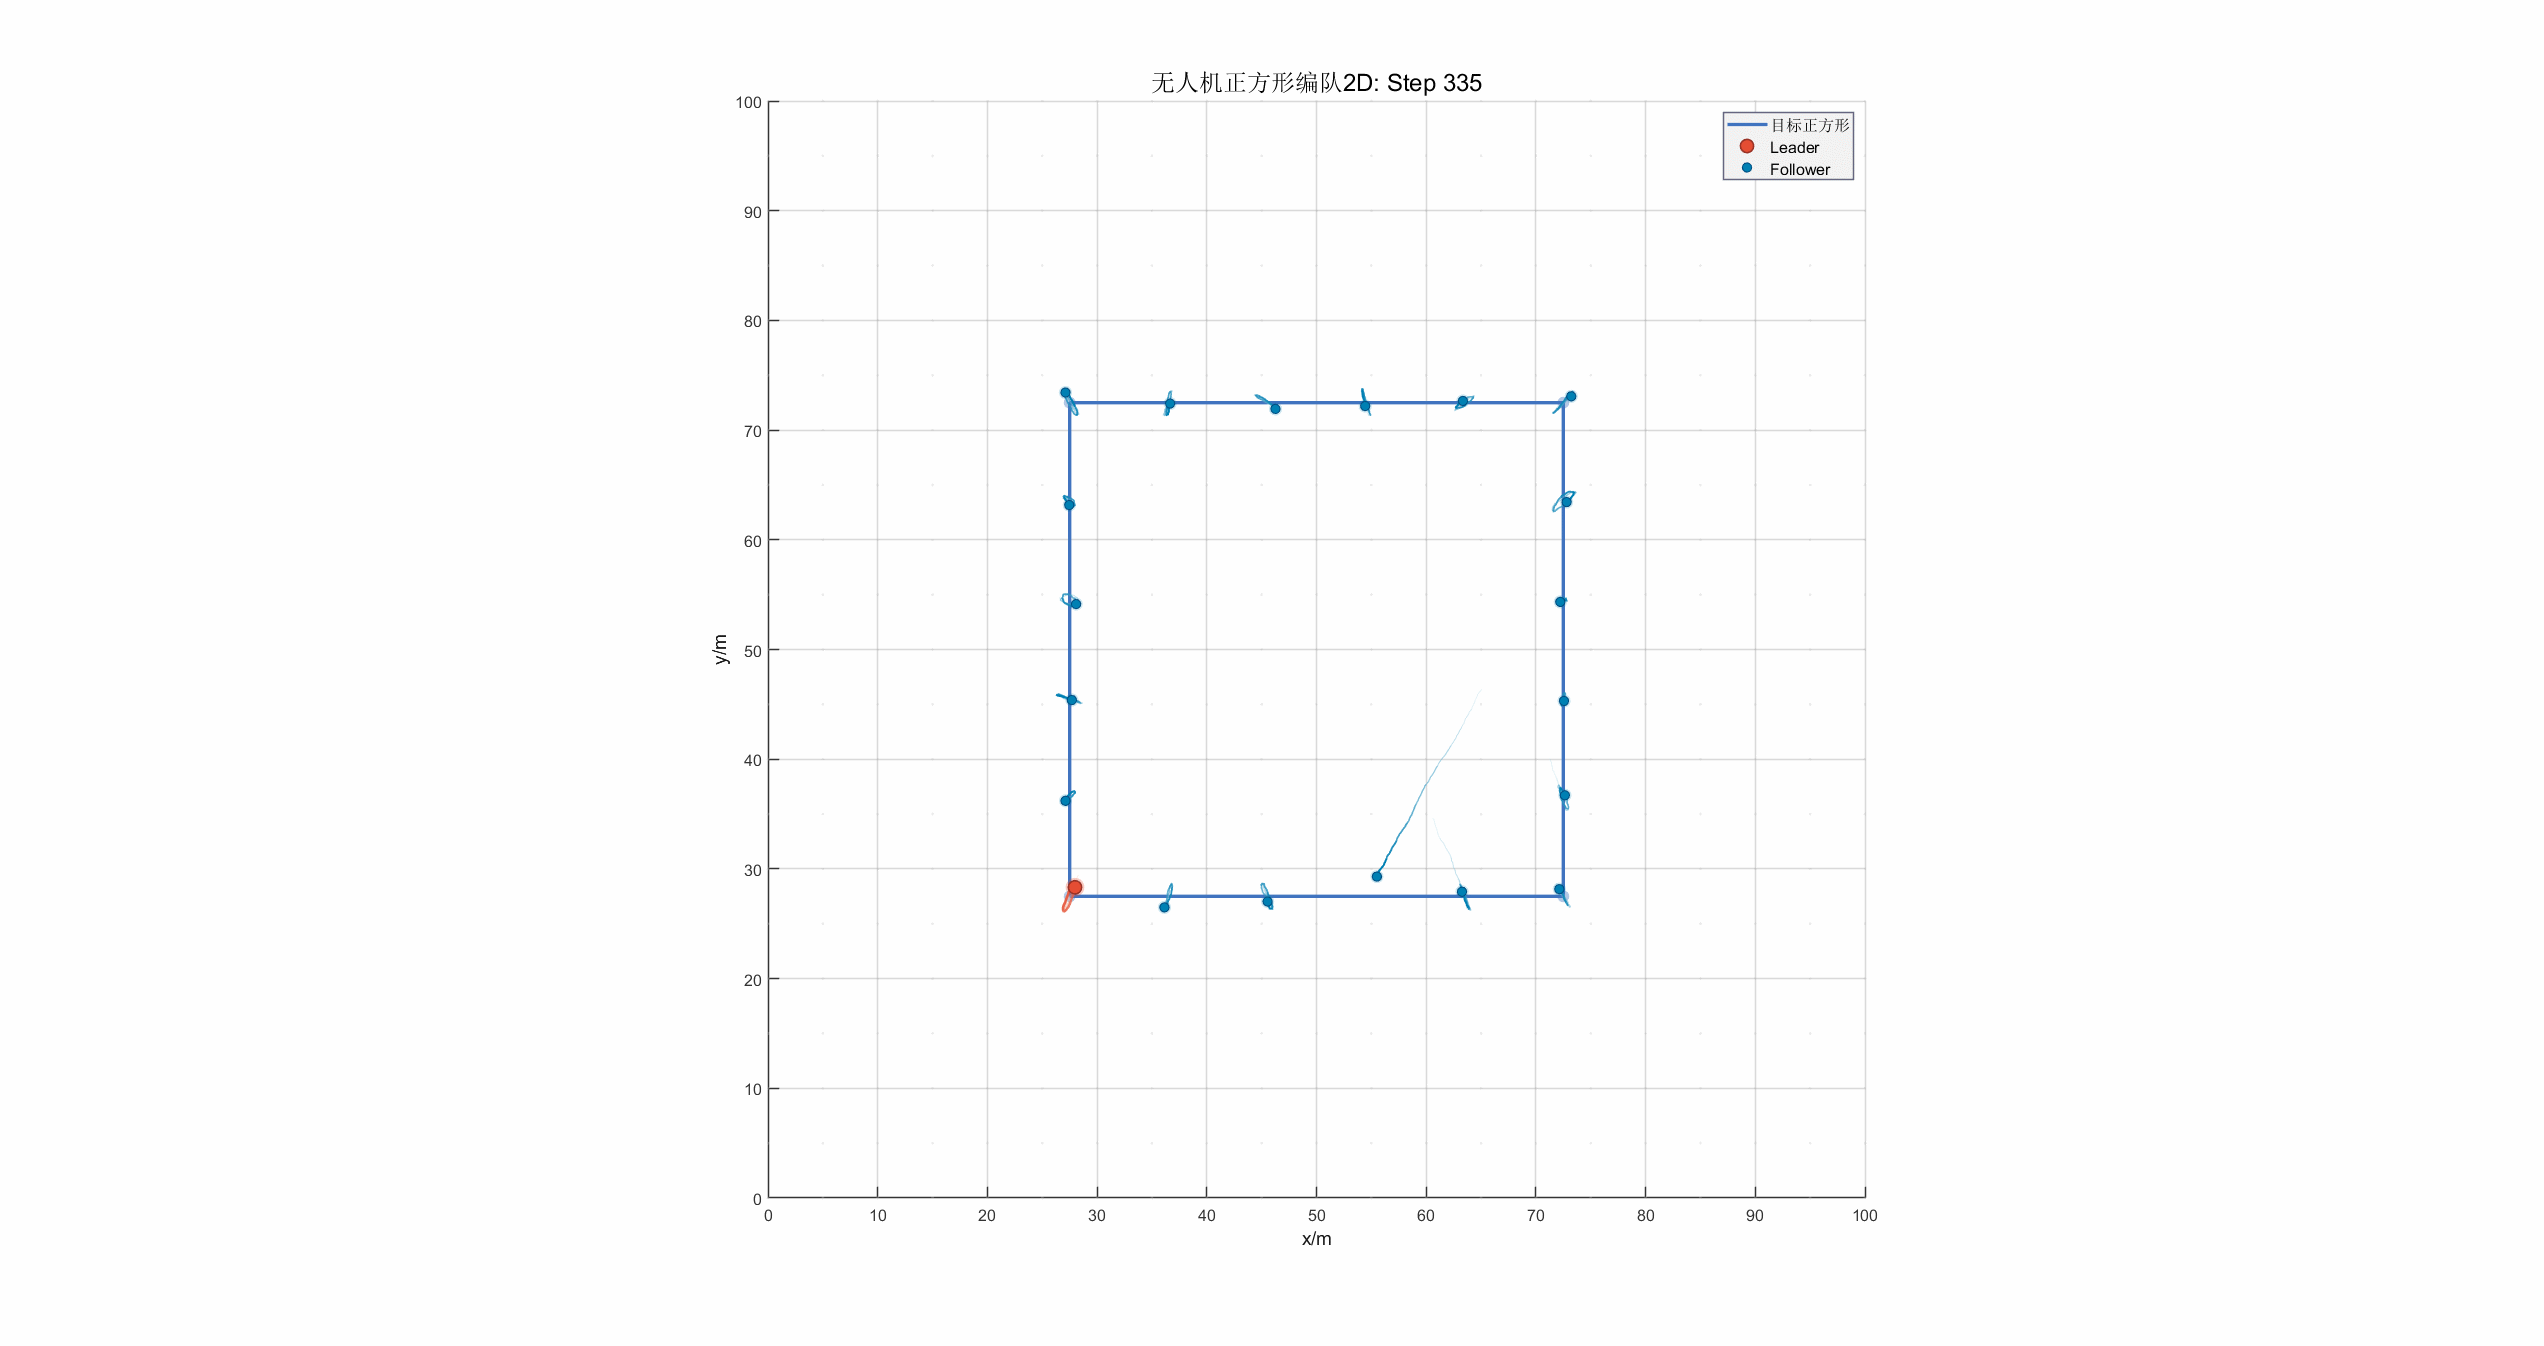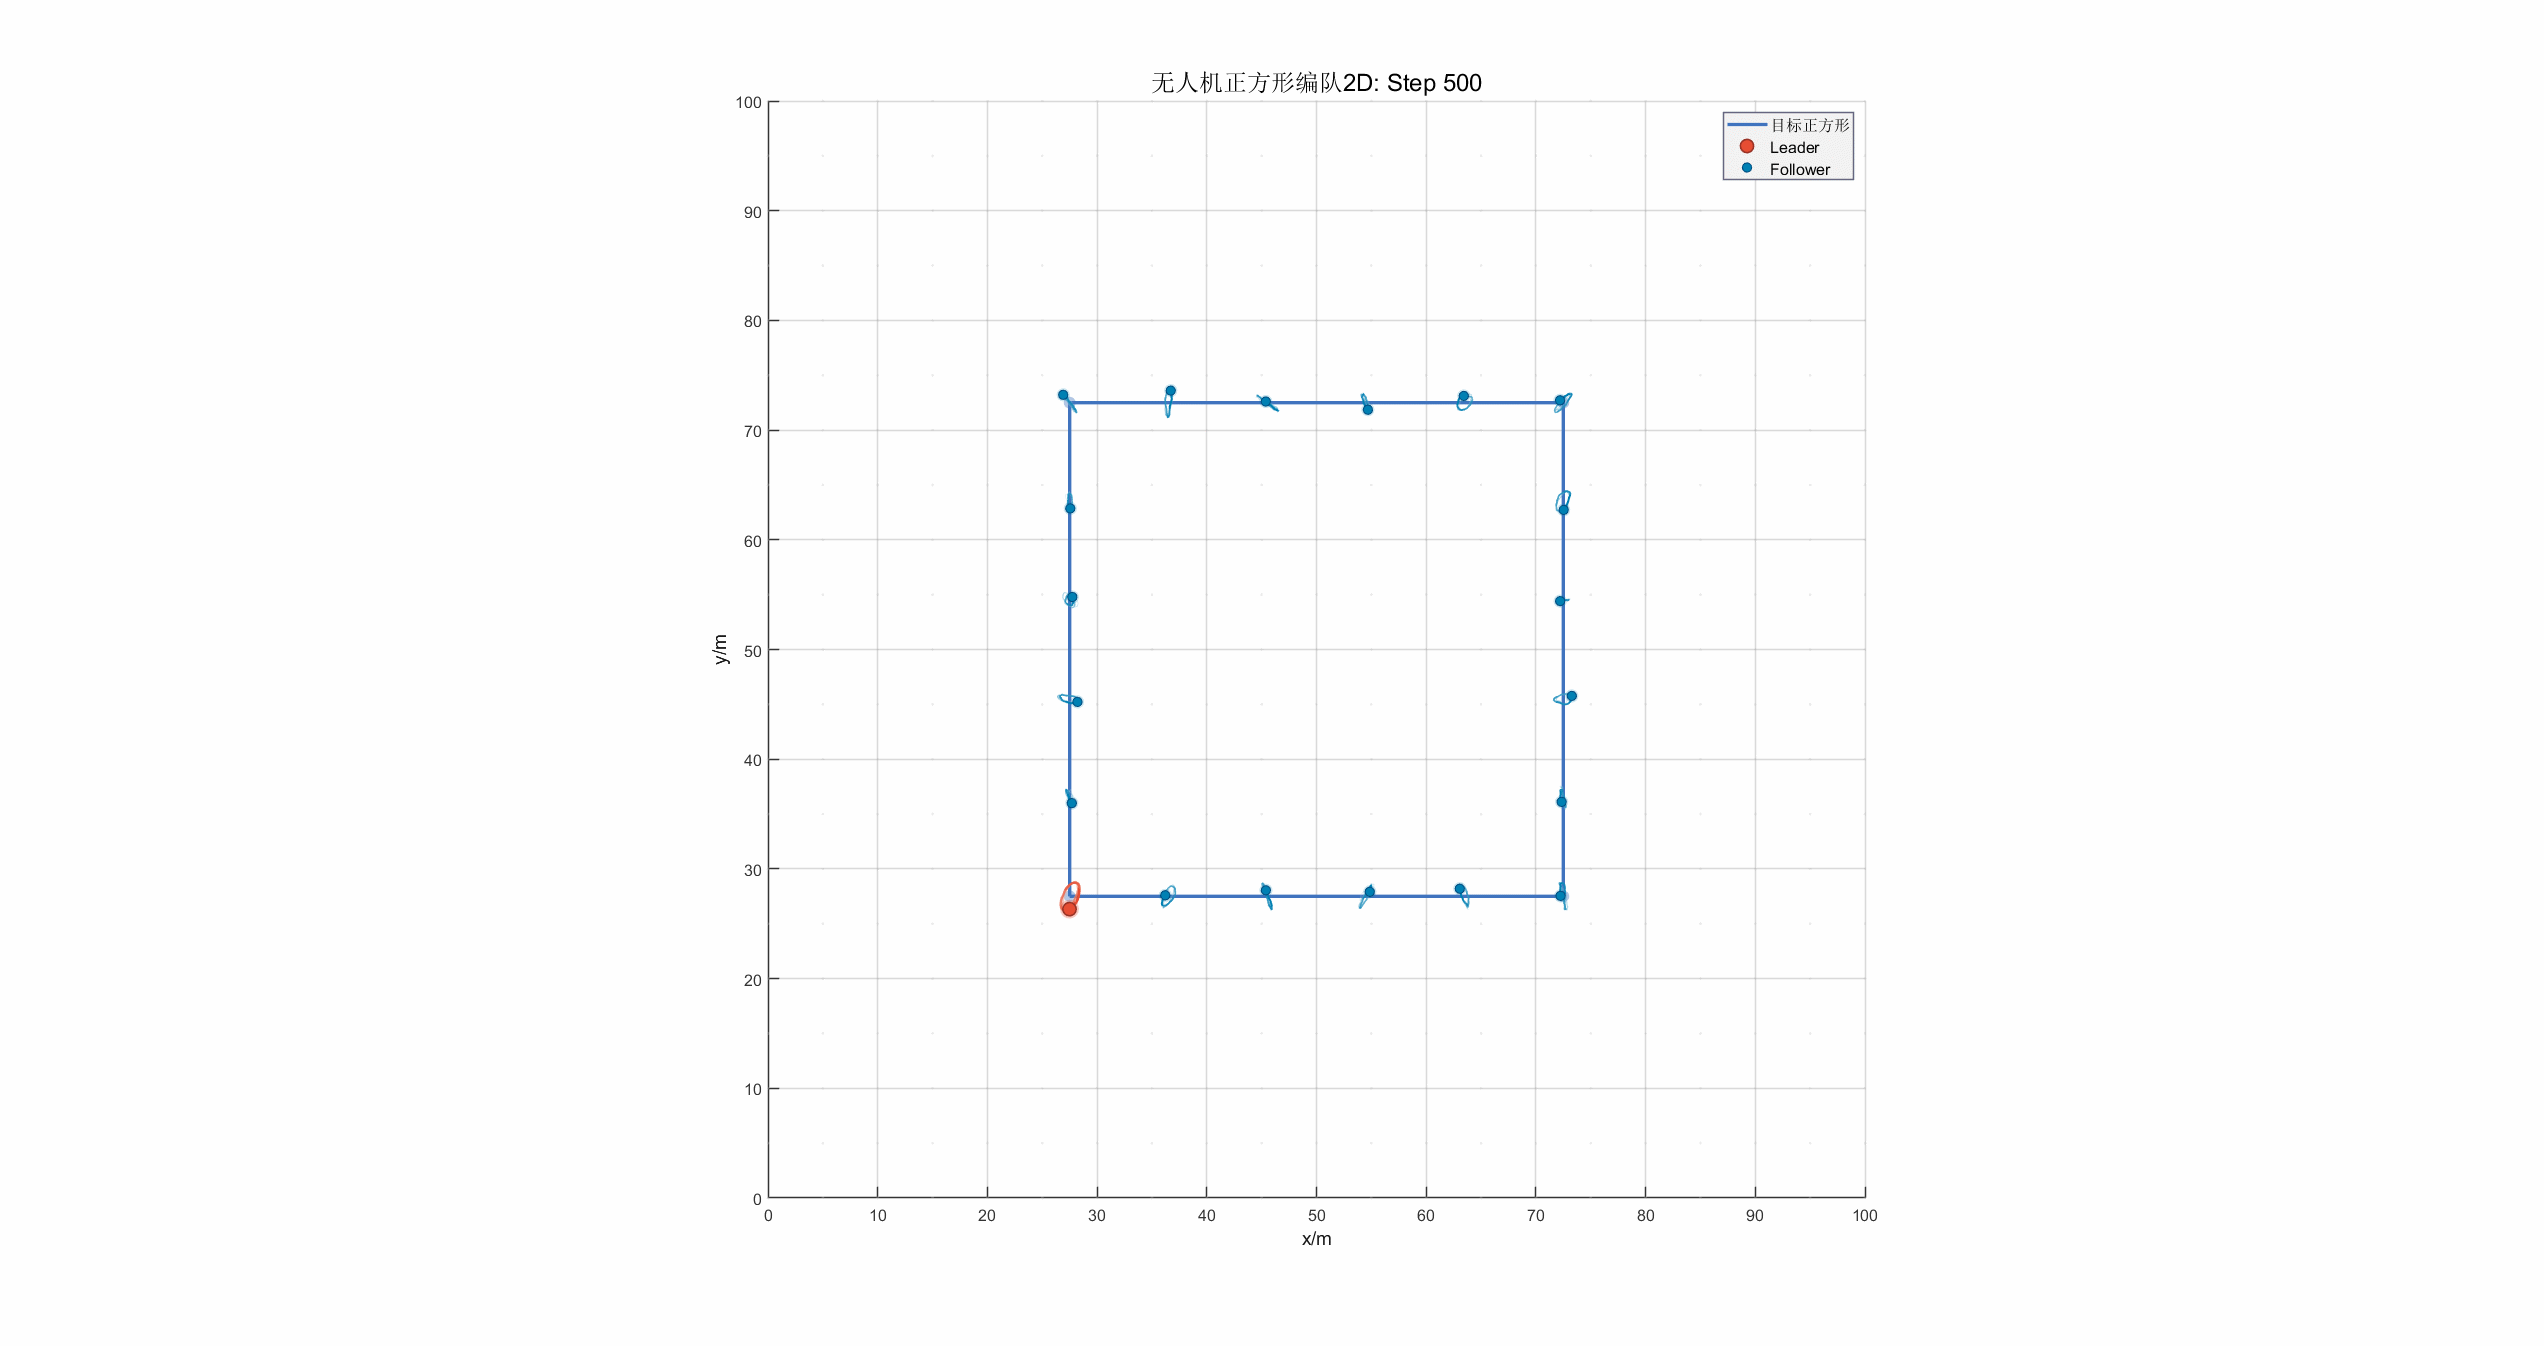
A MATLAB implementation of UAV square formation control using artificial potential fields, featuring autonomous organization, collision avoidance, and high-quality 2D/3D visualizations.
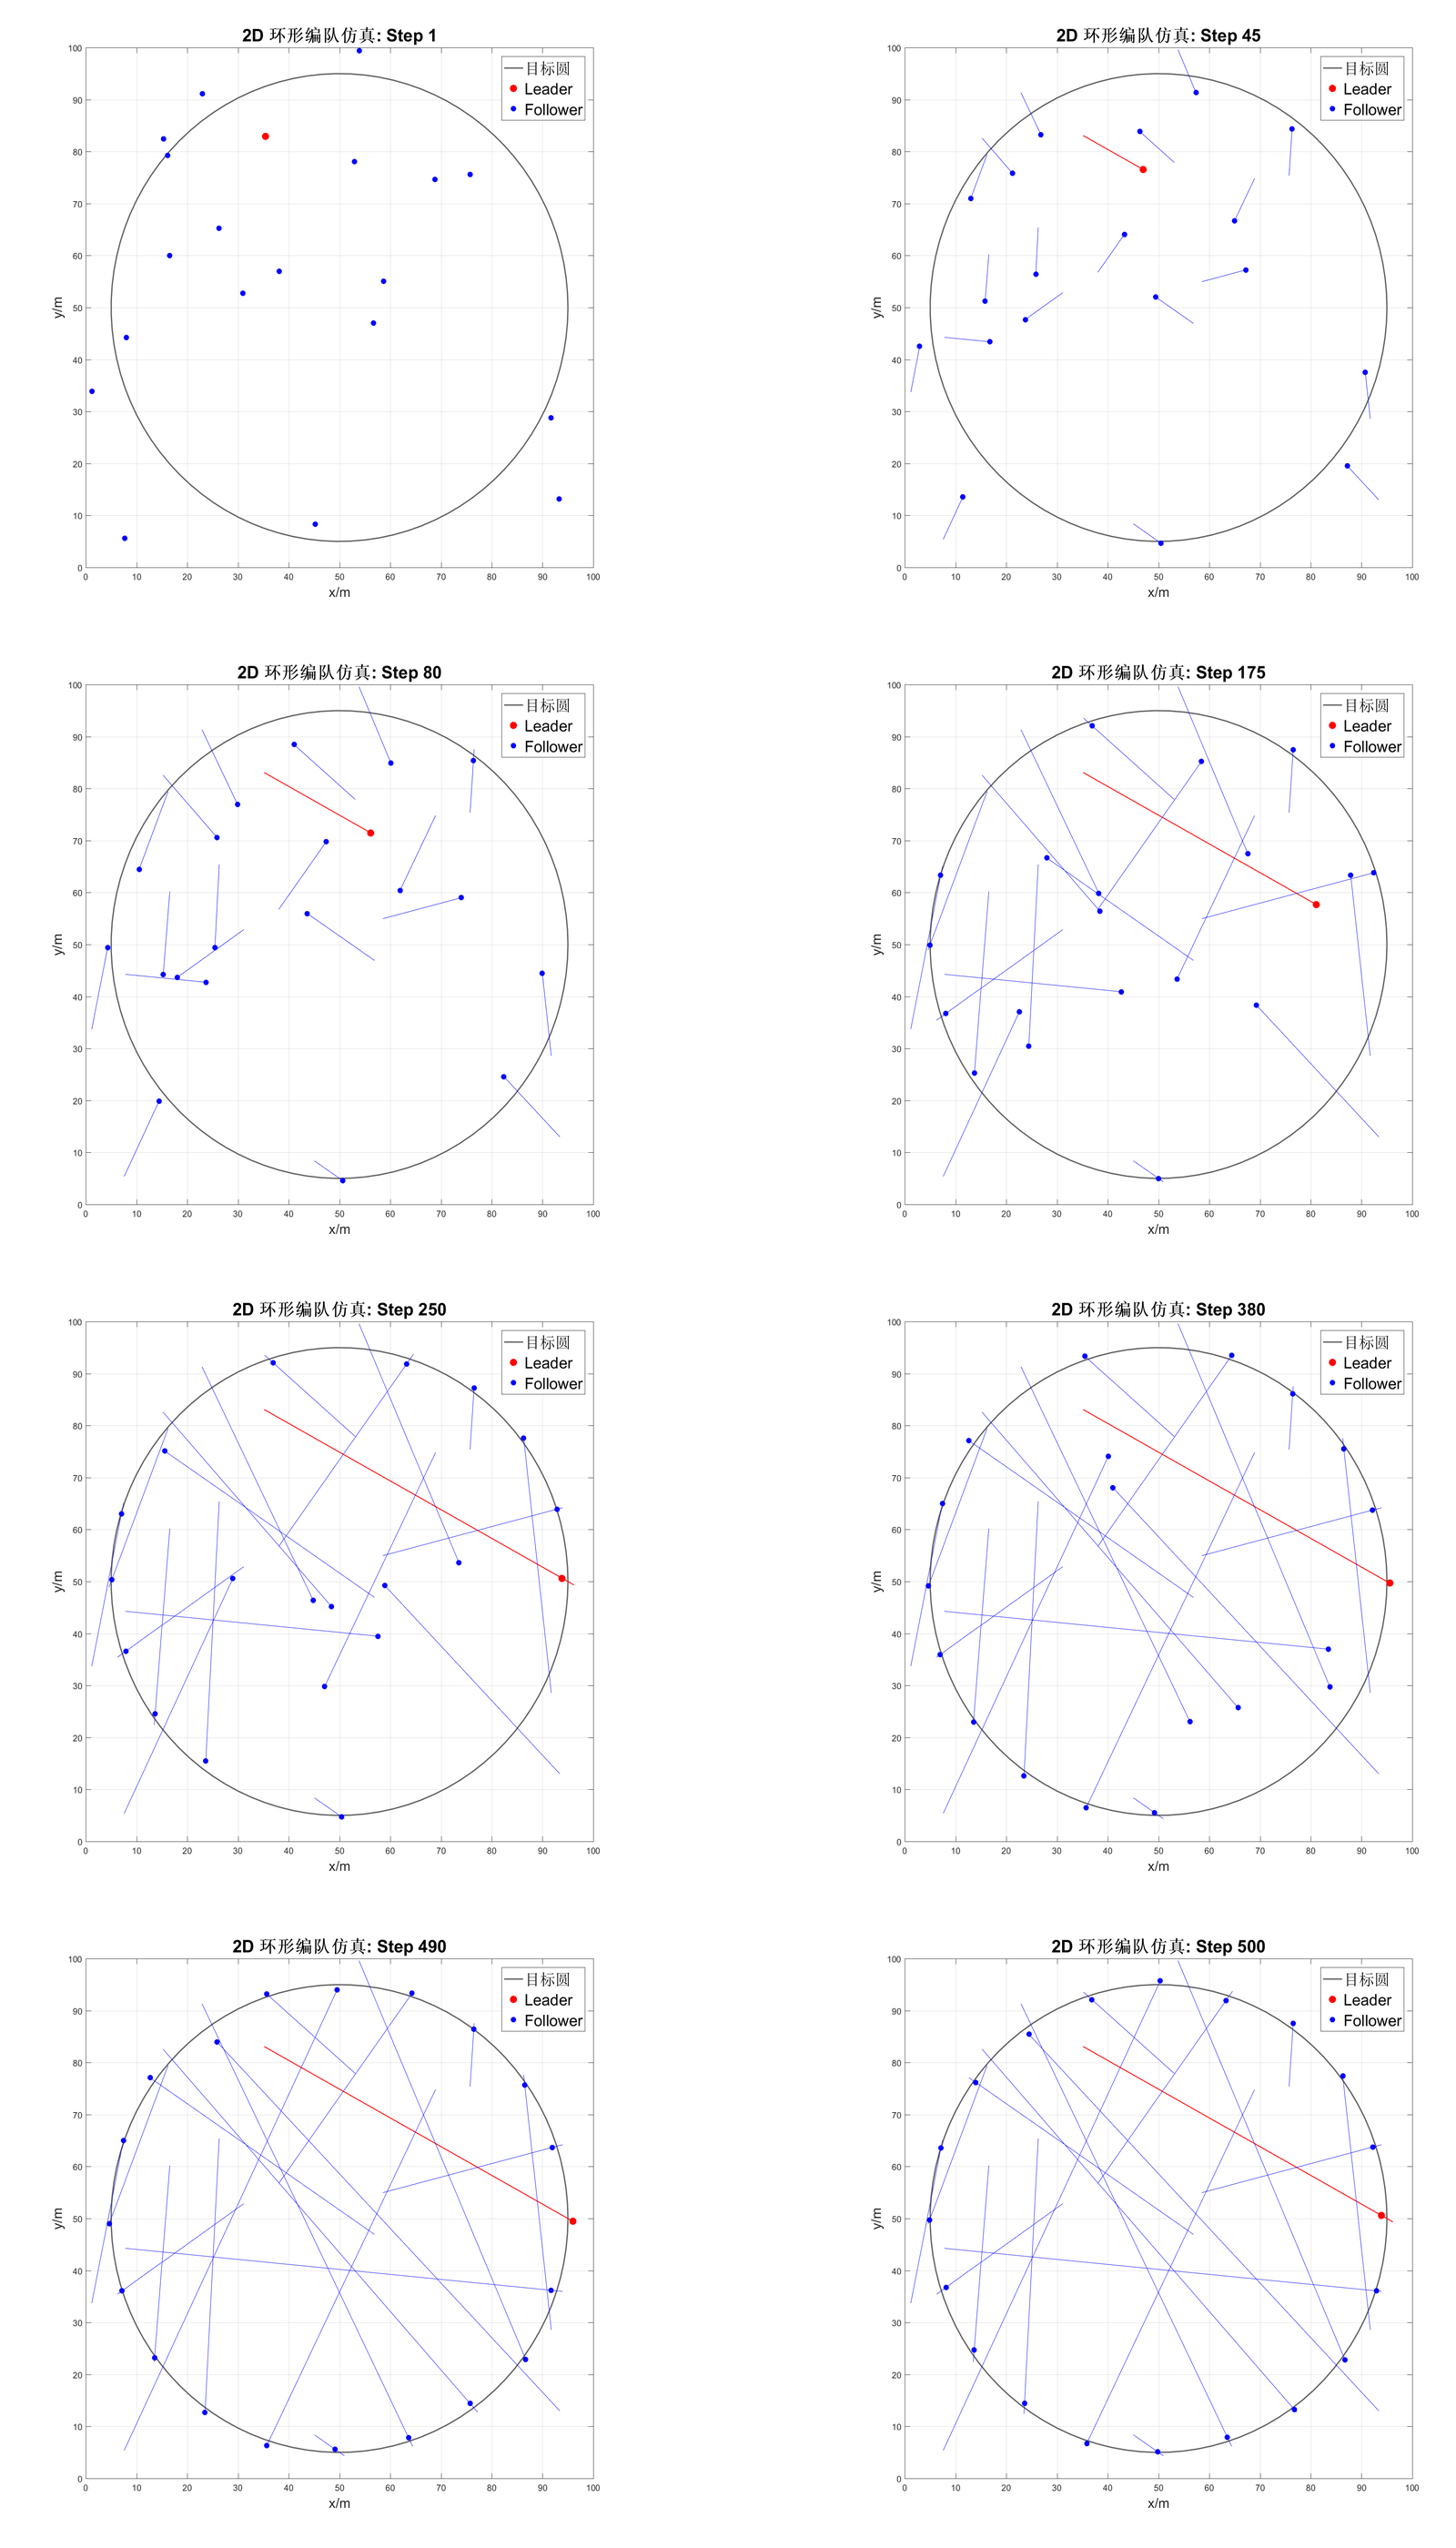
A robust MATLAB implementation of distributed UAV formation control based on ring topology, featuring both 2D planar and 3D spatial formation algorithms with visualization tools.