mobile-robots



fiss_planner
FISS & FISS+: Fast Iterative Search and Sampling trajectory planners for autonomous driving (with FOP baselines). C++17 core, Python, ROS 2 / ROS 1, Lanelet2, CARLA, MPC
- 177
- C++
- Apache-2.0
- 2 wk ago

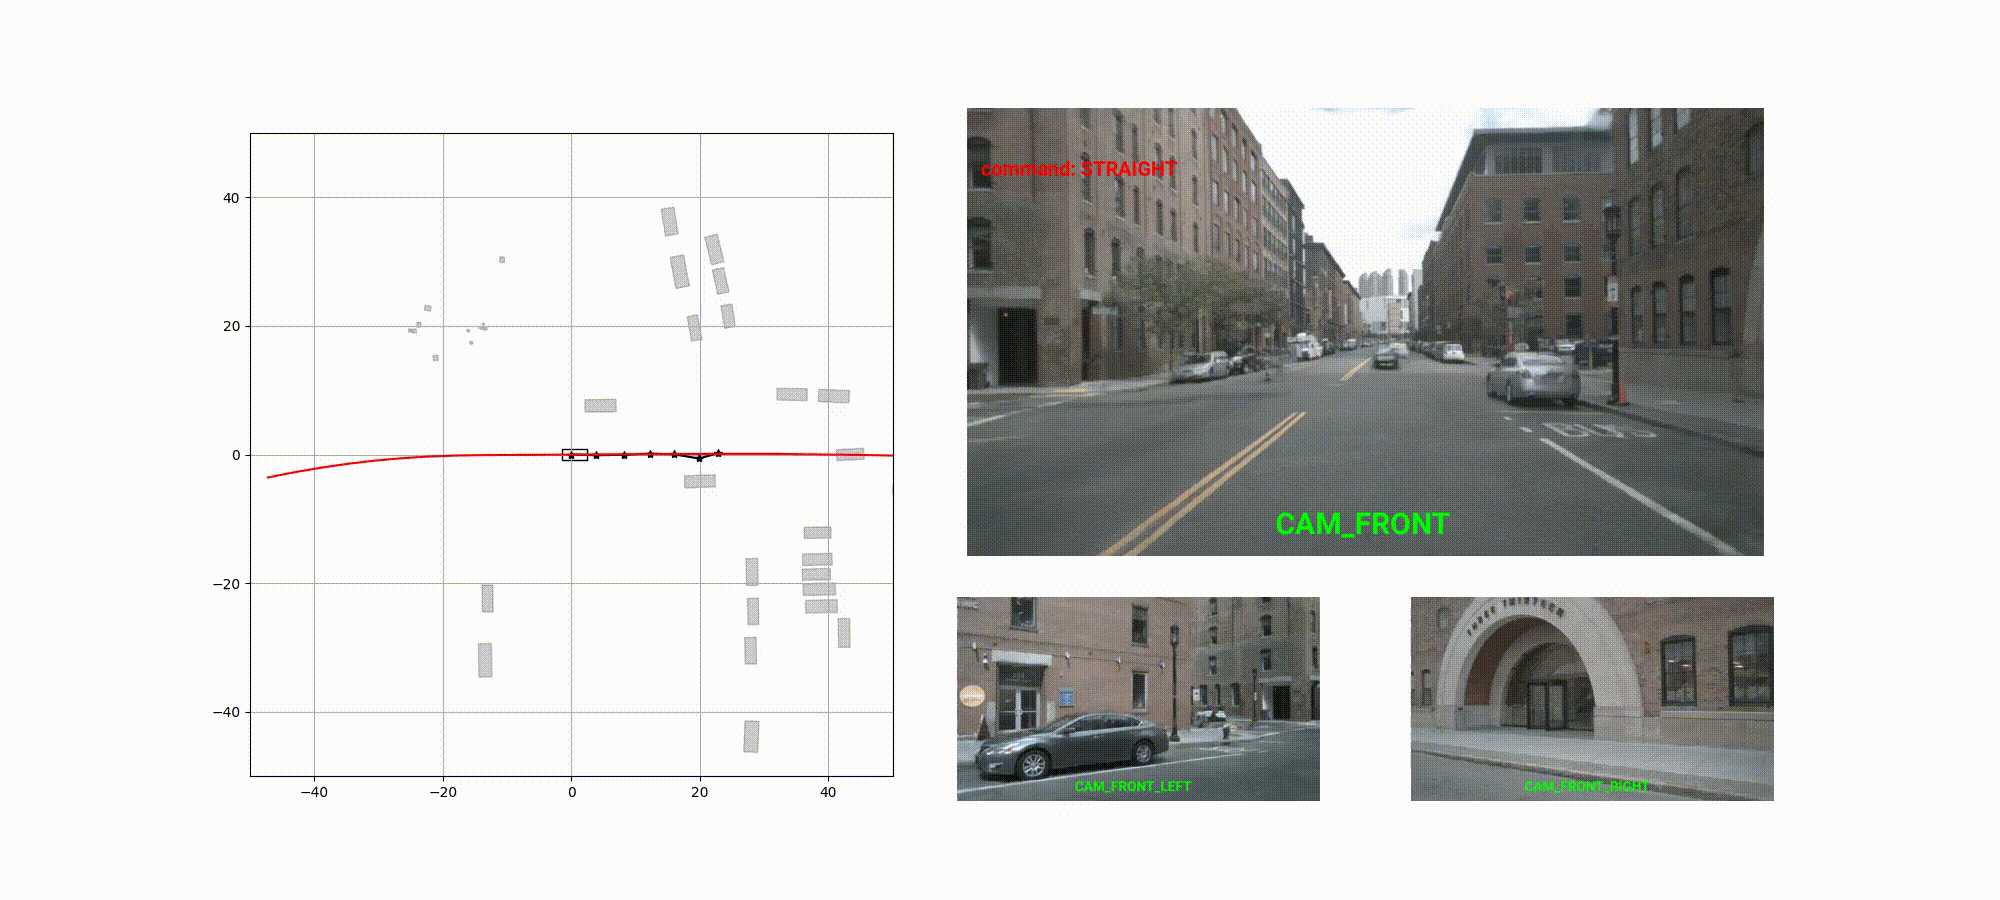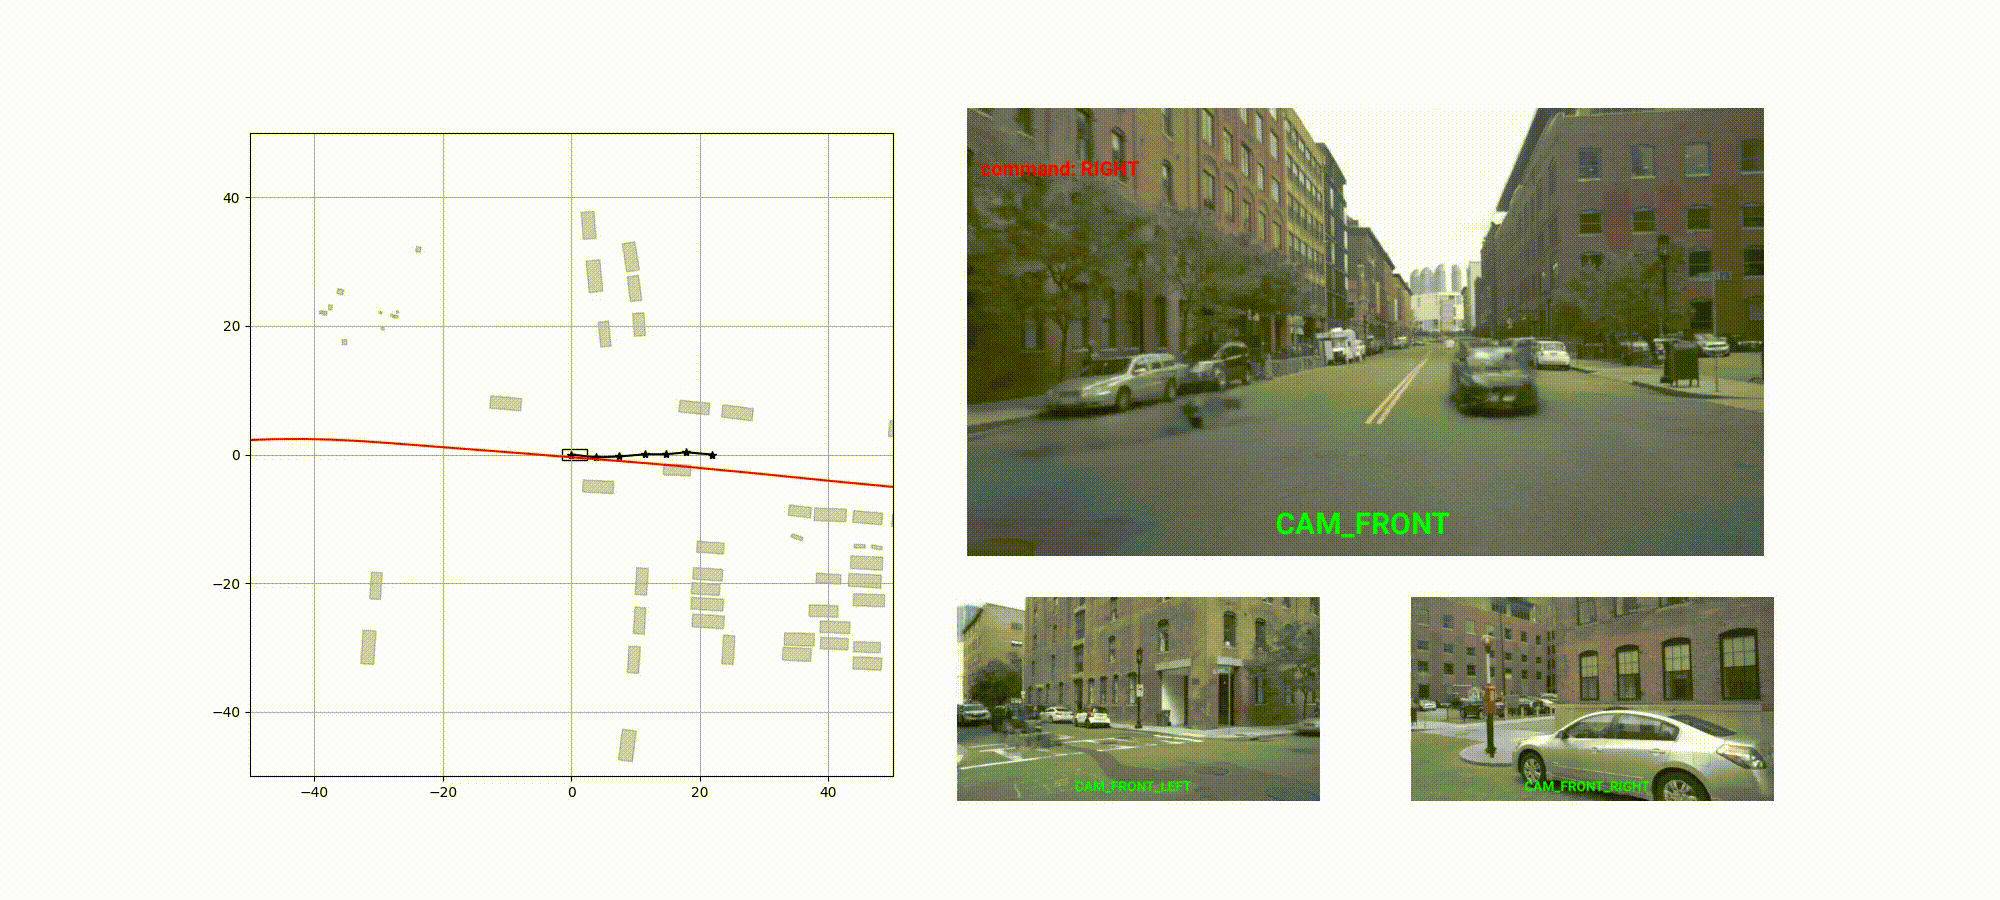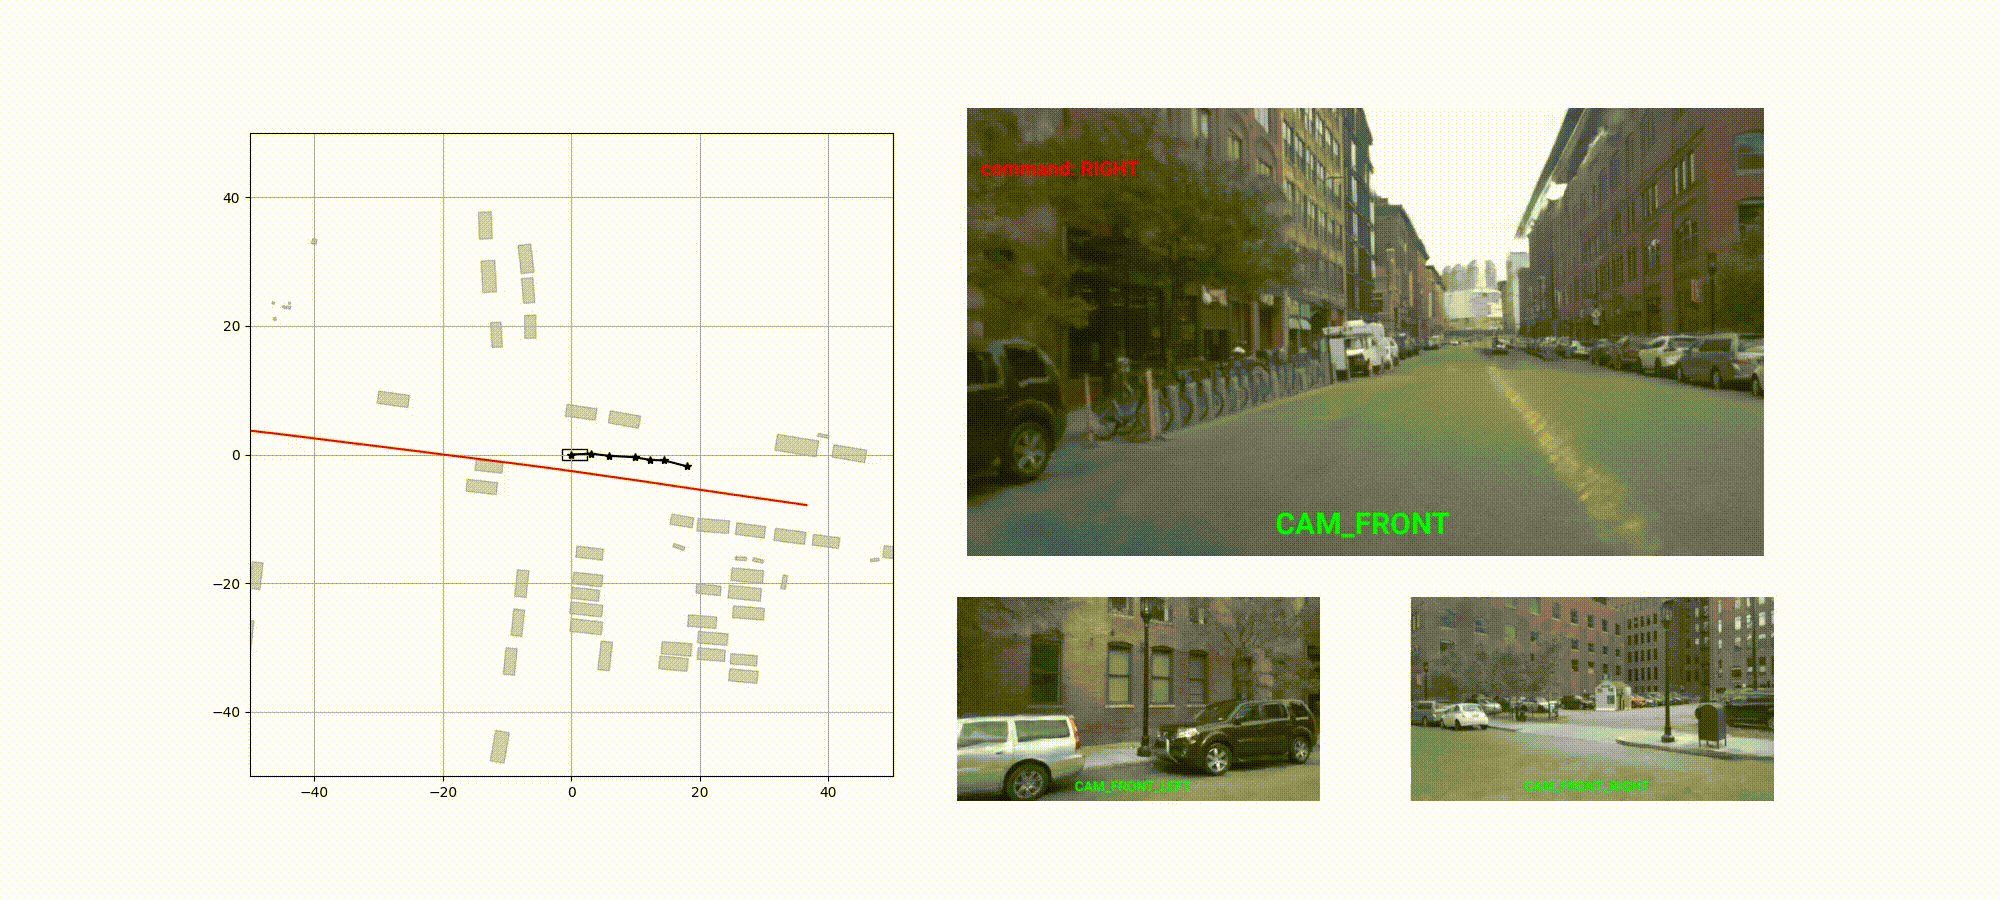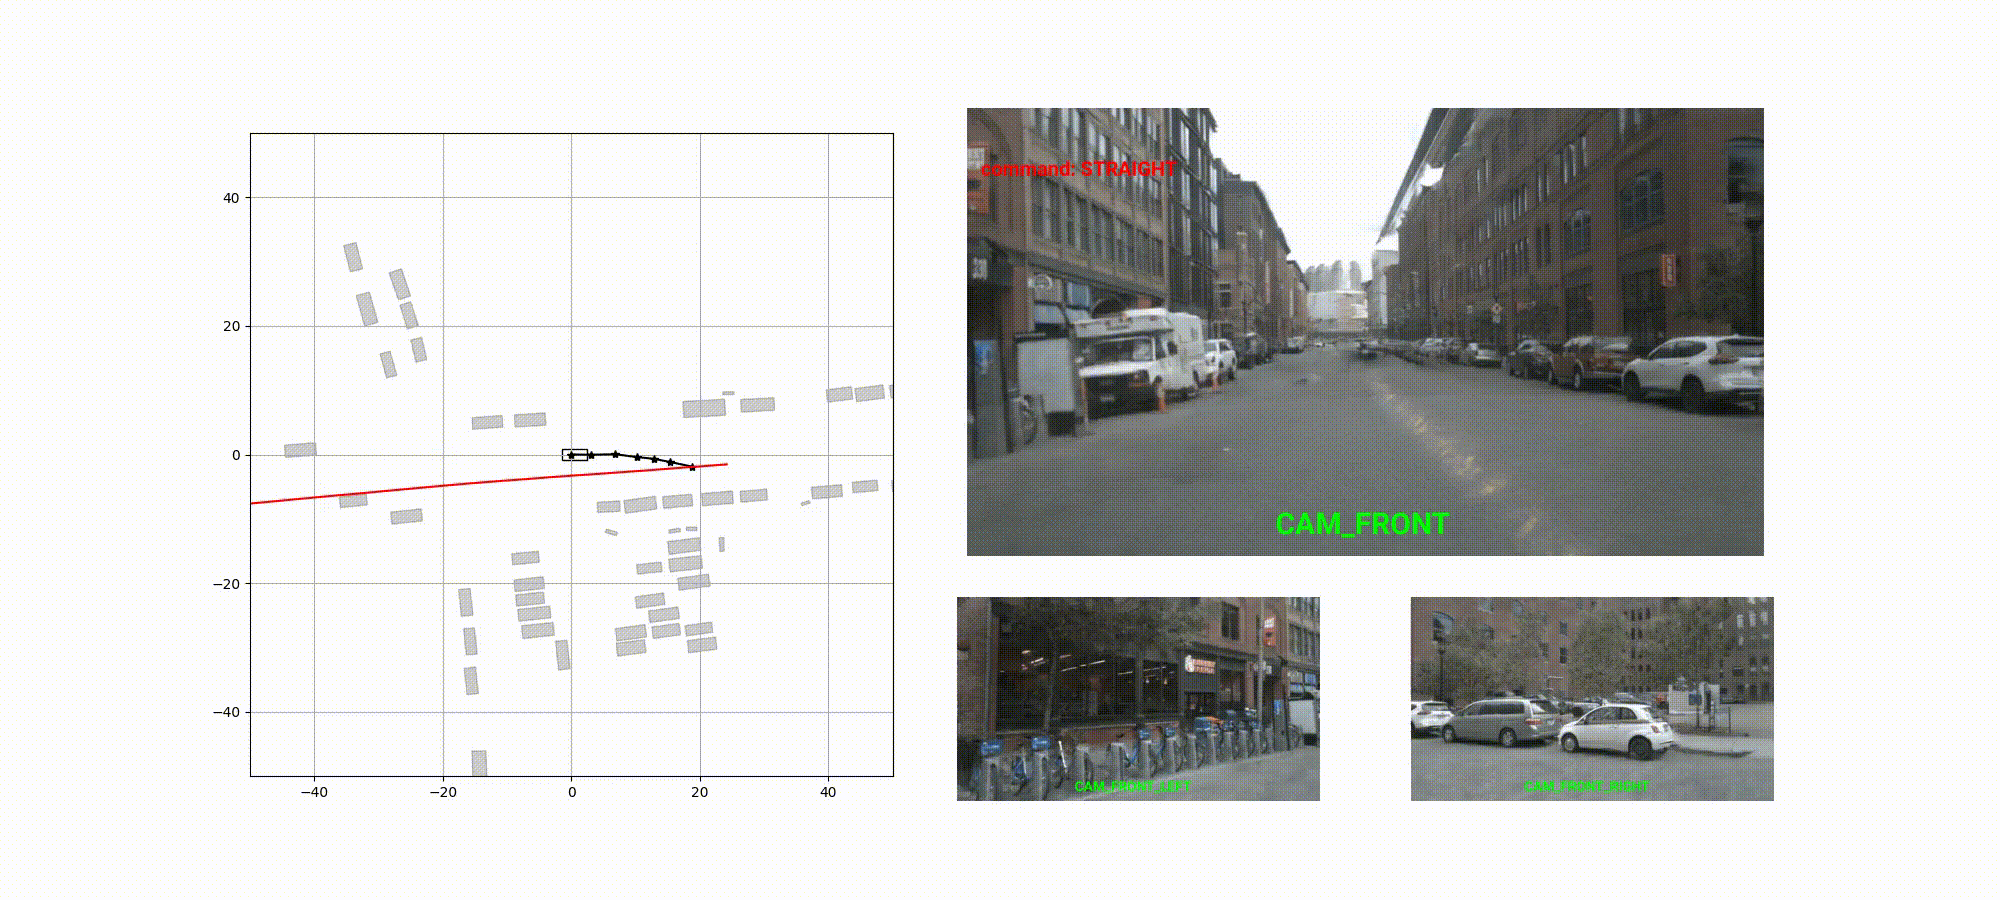
VideoActionModel
VaViM and VaVAM: Autonomous Driving through Video Generative Modeling (official repository).
- 173
- Jupyter Notebook
- MIT
- 17 mo ago

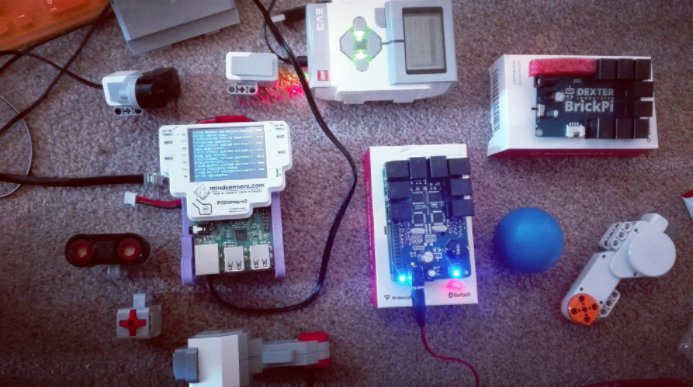
ev3dev-lang-java
A project to learn Java and create software for Mindstorms Robots using hardware supported by EV3Dev & the LeJOS way.
- 108
- Java
- MIT
- 3 y ago

AG-LOAM
COMPAG 2025: Adaptive LiDAR-only Odometry and Mapping Framework in Agricultural Environments
- 67
- C++
- MIT
- 4 wk ago

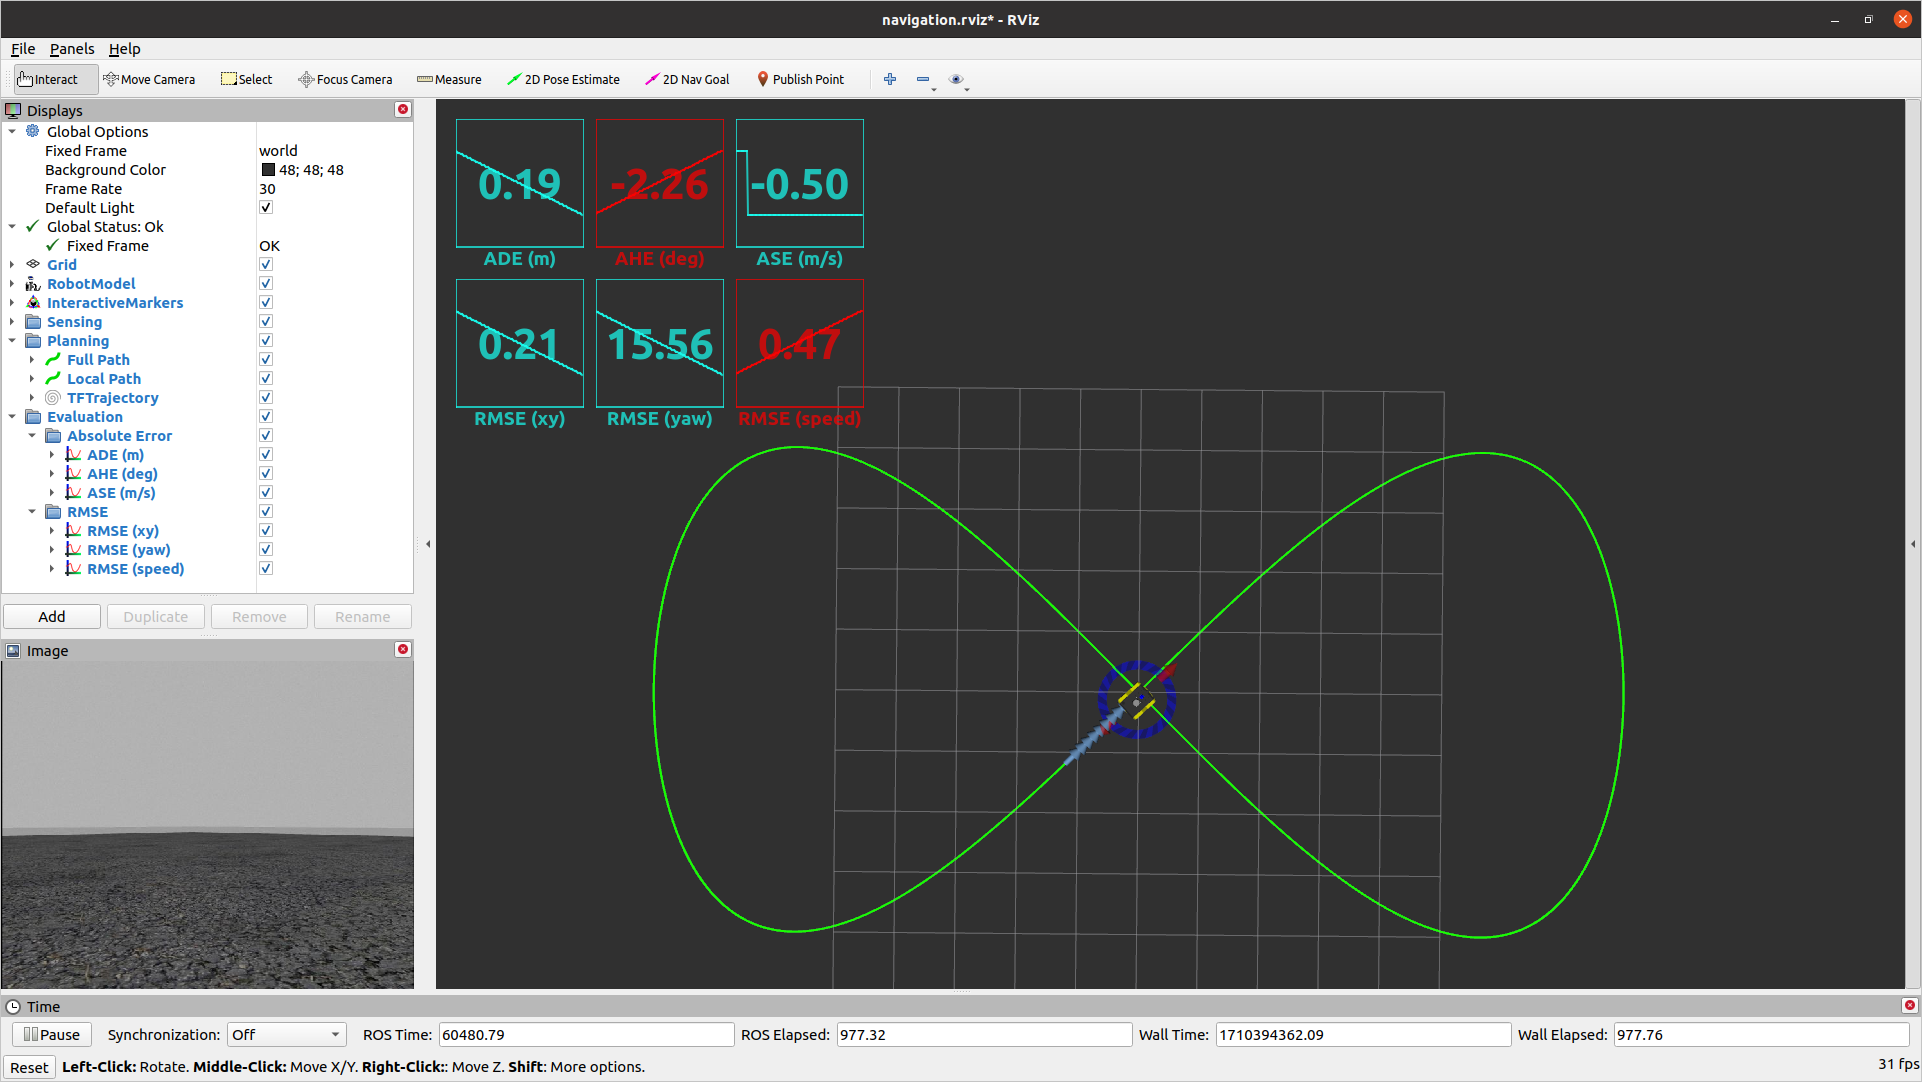

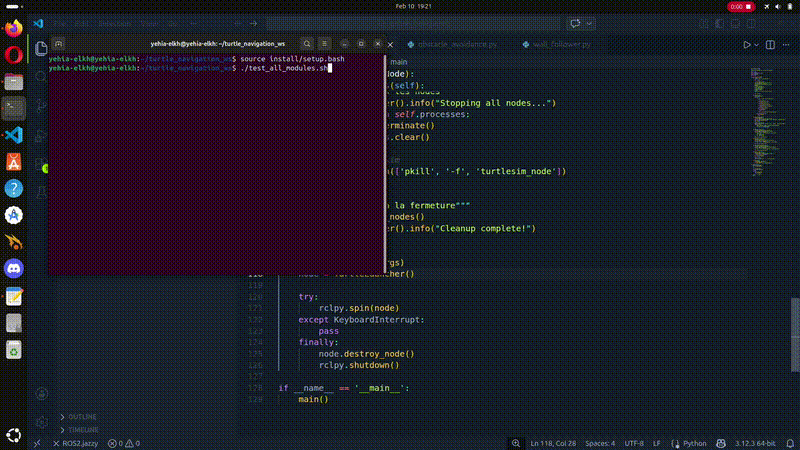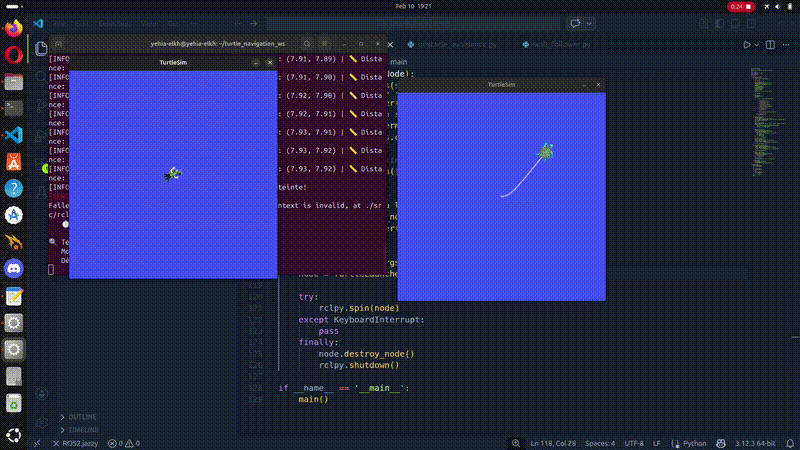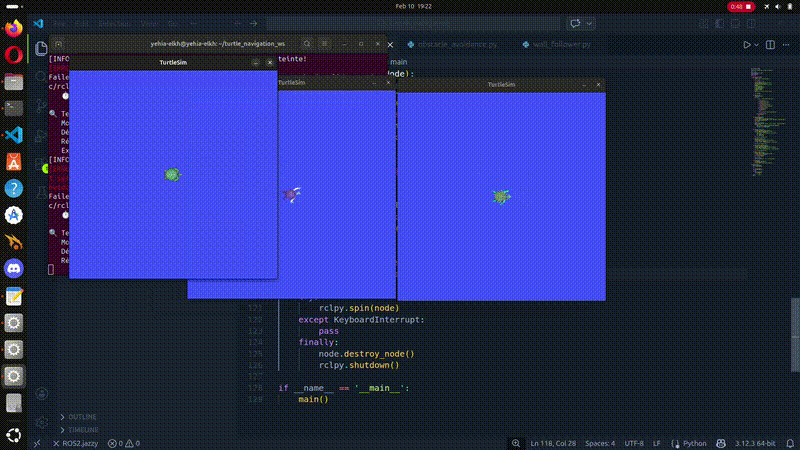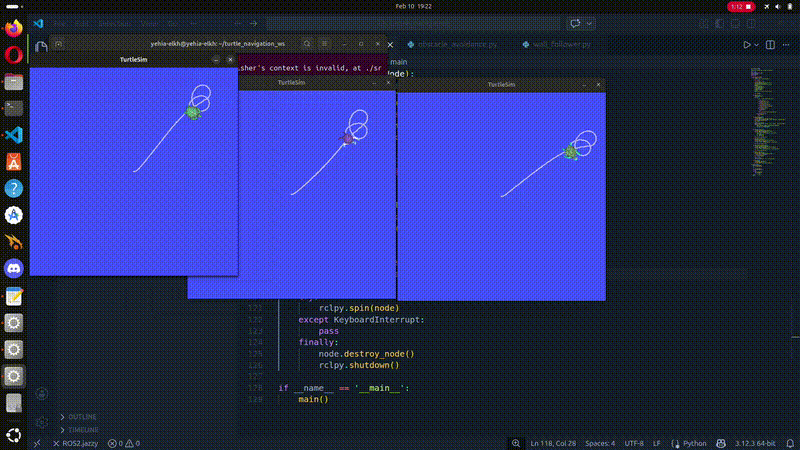
turtle_navigation
ROS 2 navigation algorithms (PID, FSM, Potential Fields) for autonomous mobile robots | TurtleSim implementation...
- 5
- Python
- 9 mo ago

Local-Odometry-Techniques-MIRTO-
- Provided the MIRTO robot, designed and built by a team led by Dr. Franco Raimondi (F.Raimondi@mdx.ac.uk) at Middlesex University London, with autonomous navigation planning capabilities. - Wrote a library of high-level odometrical functionalities (i.e. Java methods) to allow MIRTO to perform actions such as rotating, translating and moving towards a specific point in space while avoiding all obs
- 1
- Java
- 10 y ago


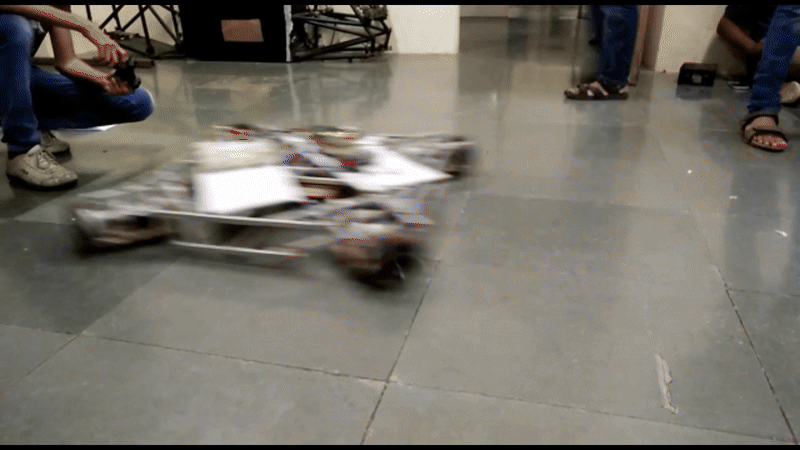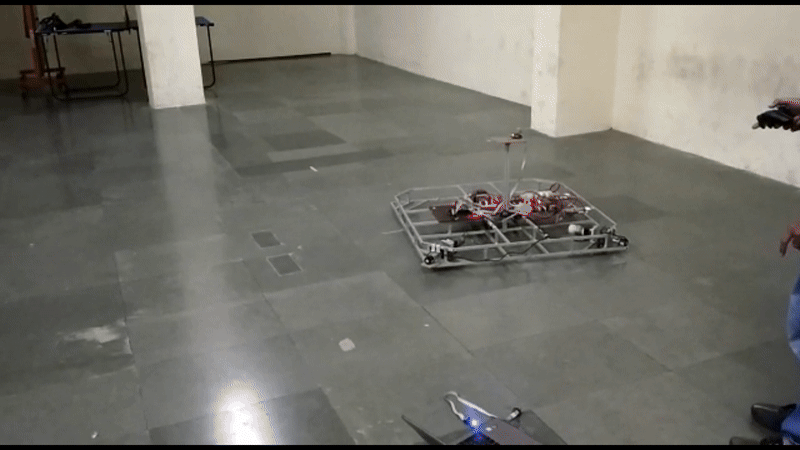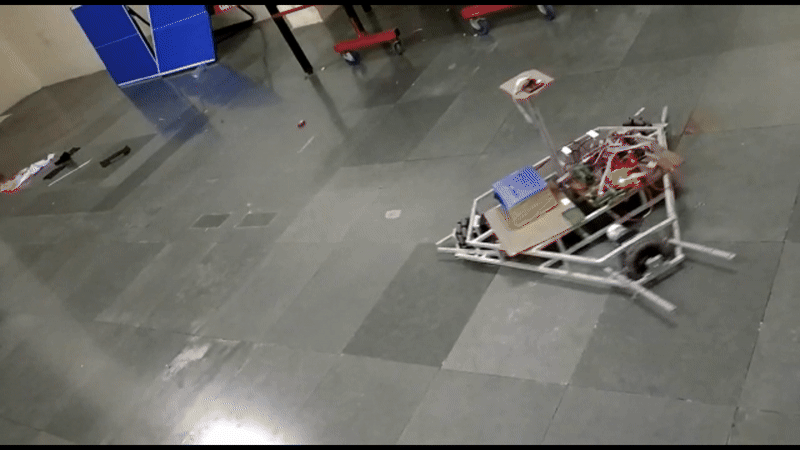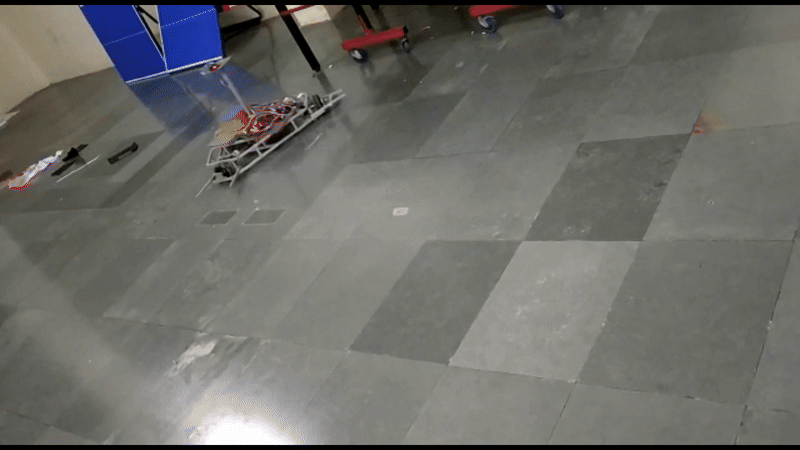
robot-drive-systems
Robot Drive Systems repository featuring code and kinematics for 2-wheel differential drive, 3-wheel omni-directional drive, and 4-wheel omni-wheel drive robots. Enables linear, rotational, and omnidirectional motion for robotics applications.
- 0
- Makefile
- MIT
- 16 mo ago
