uav


qgroundcontrol
Cross-platform ground control station for drones (Android, iOS, Mac OS, Linux, Windows)
- 5.1k
- C++
- Apache-2.0
- 2 d ago


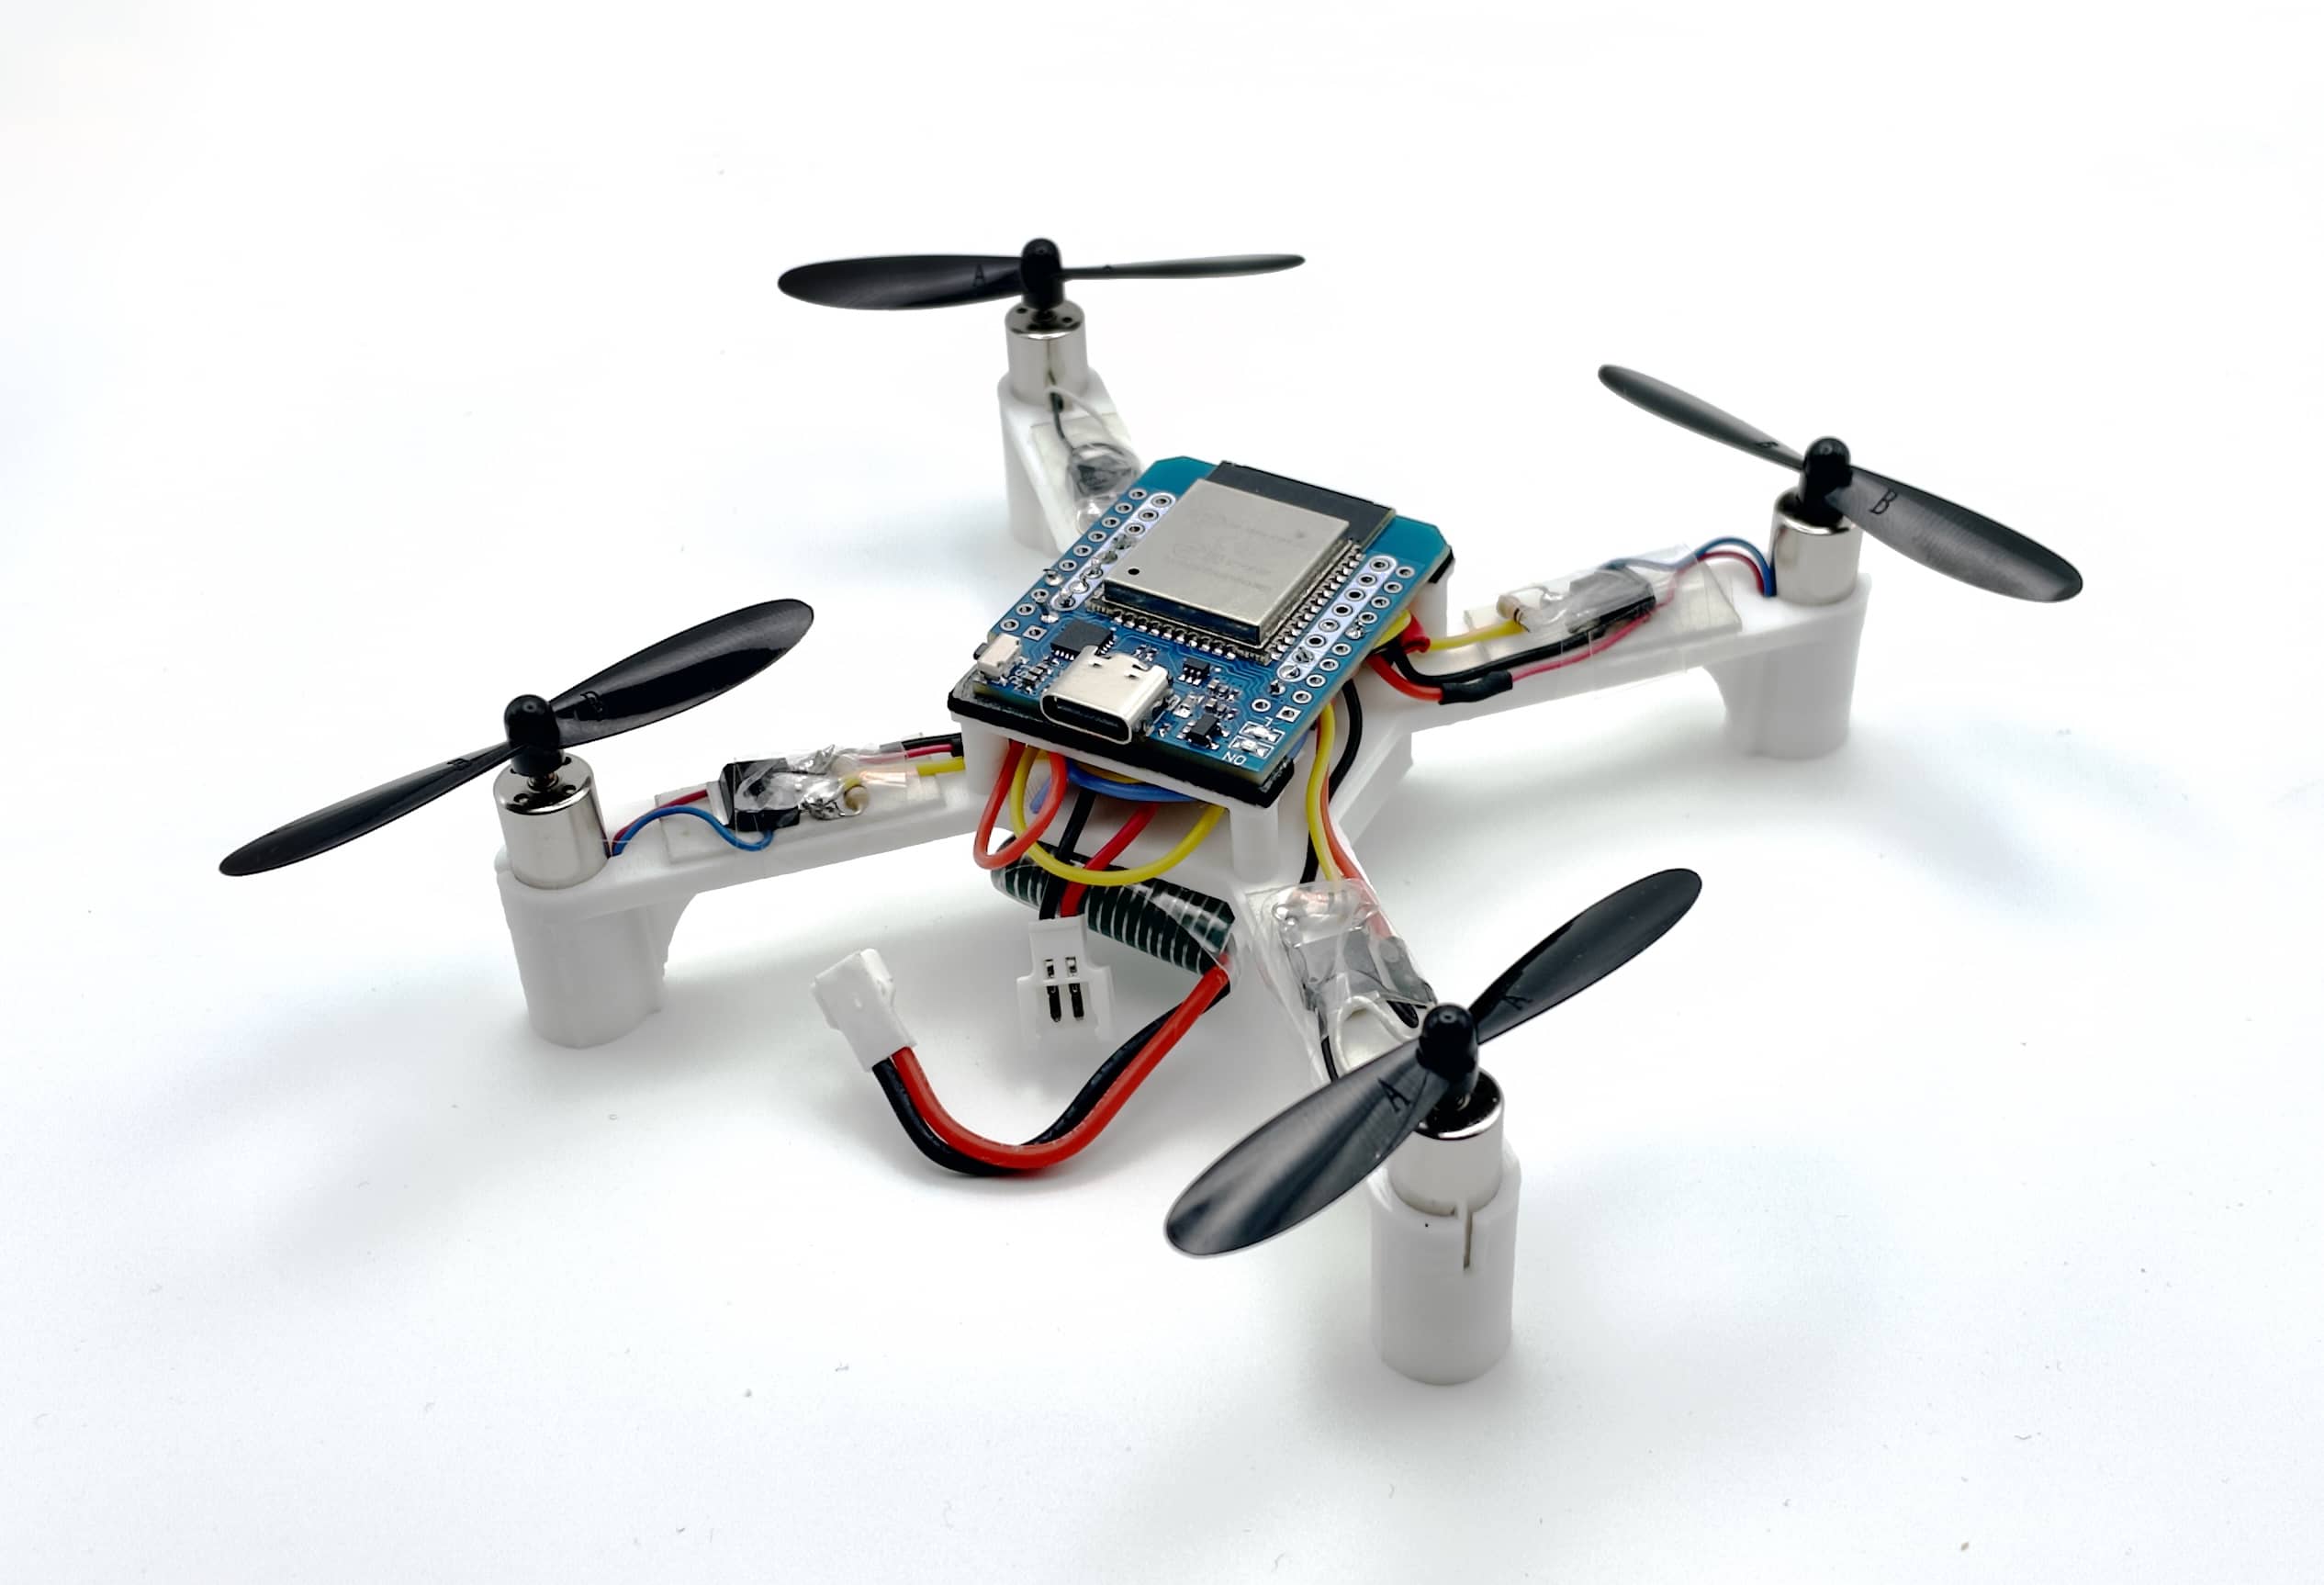

gym-pybullet-drones
PyBullet Gymnasium environments for single and multi-agent reinforcement learning of quadcopter control
- 2.2k
- Python
- MIT
- 8 d ago

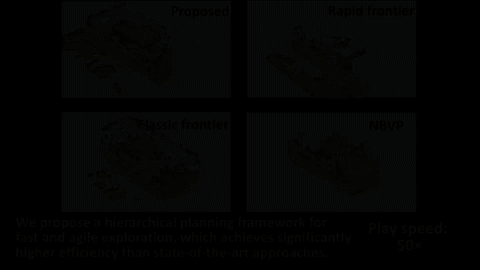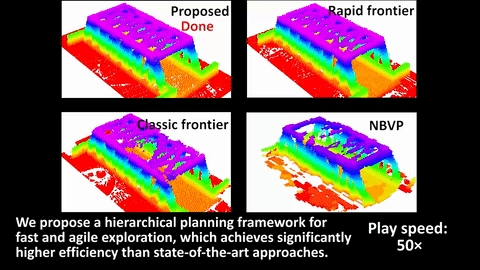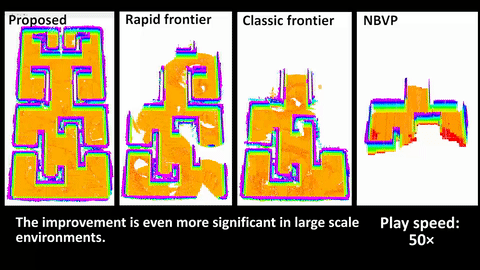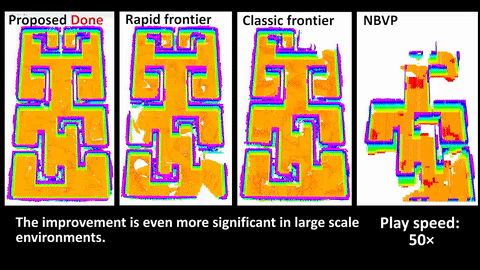


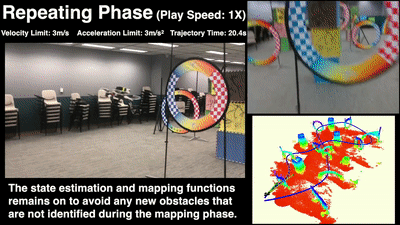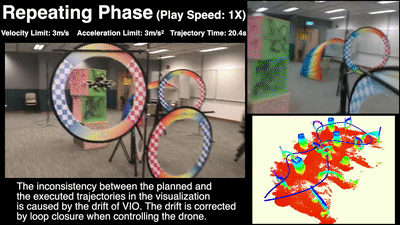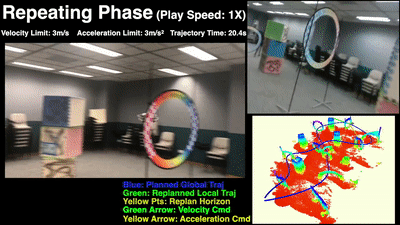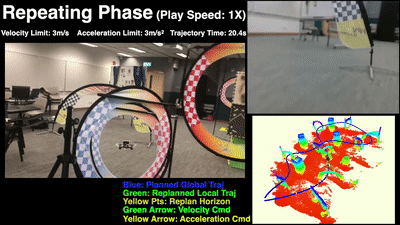
Teach-Repeat-Replan
Teach-Repeat-Replan: A Complete and Robust System for Aggressive Flight in Complex Environments
- 1.2k
- C++
- GPL-3.0
- 5 y ago
ESP32
DroneBridge for ESP32. A secure & transparent telemetry link with support for WiFi and ESP-NOW. Supporting MAVLink, MSP, LTM or any other protocol
- 1.2k
- C
- Apache-2.0
- 4 wk ago

CarlaAir
CarlaAir: Fly Drones Inside a CARLA World!! A Unified Infrastructure for Air-Ground Embodied Intelligence
- 1.1k
- C++
- 3 mo ago


SoftRF
:airplane: Multi-functional, compatible DIY general aviation proximity awareness system
- 1k
- C
- GPL-3.0
- 14 h ago


awesome-mobile-robotics
Useful links of different content related to AI, Computer Vision, and Robotics.
- 787
- 4 mo ago


UAV-DDPG
Code for paper "Computation Offloading Optimization for UAV-assisted Mobile Edge Computing: A Deep Deterministic Policy Gradient Approach"
- 731
- Python
- 6 wk ago



Swarm-LIO2
[T-RO 24] Swarm-LIO2: Decentralized, Efficient LiDAR-inertial Odometry for UAV Swarms
- 471
- C++
- GPL-2.0
- 10 mo ago


libcanard
A compact implementation of the Cyphal/CAN protocol in C for high-integrity real-time embedded systems
- 457
- C
- MIT
- 4 wk ago


UavNetSim
UavNetSim: A Python-based simulation platform for designing and testing communication protocols and control algorithms in UAV swarm.
- 419
- Python
- MIT
- 2 mo ago


YOLOv12-BoT-SORT-ReID
🔥 CVPR 2025 (Nashville TN, USA) - The 4th Anti-UAV Workshop & Challenge 🥉
- 216
- Python
- AGPL-3.0
- 7 wk ago


roboticsknowledgebase.github.io
Robotics Knowledge Base. The Wiki for Robot Builders.
- 190
- JavaScript
- MIT
- 2 d ago

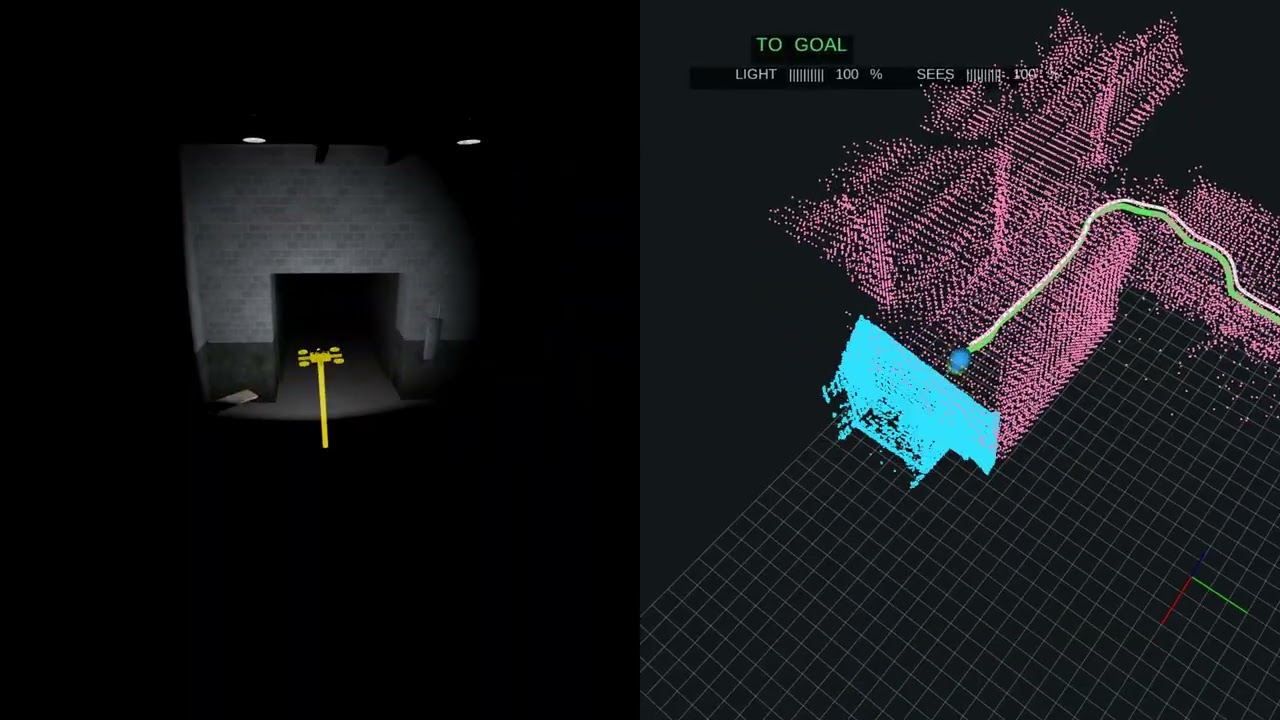
px4-ros2-drone-nav
Autonomous UAV navigation in GNSS-denied indoor spaces with no prior map: stereo VIO (MSCKF) and lidar-inertial odometry with map-based relocalization (SLAM), 3D occupancy mapping, D* Lite path planning and GPU MPPI obstacle avoidance. PX4 + ROS 2 + Gazebo SITL, DARPA SubT Urban.
- 175
- C++
- MIT
- 16 h ago

live
An open-source drone show and drone swarm ground control station GUI frontend
- 129
- TypeScript
- GPL-3.0
- 4 d ago

ardupilot-software-development
Source codes of Software Development for Ardupilot Powered Unmanned Systems course
- 115
- Python
- 2 y ago

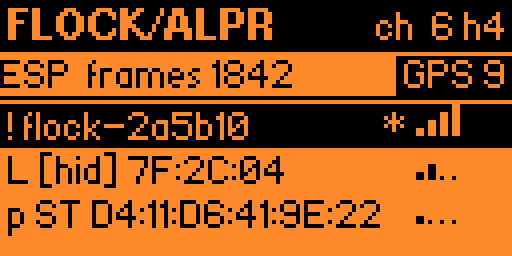
FlipDeFlock
Passive Flipper Zero surveillance detector. Pairs with any ESP32 to find Flock Safety and other ALPR cameras, acoustic sensors, body-worn police cameras and drones over Wi-Fi and BLE. Decodes drone Remote ID, including the operator's position. Geotags, maps, learns new signatures, exports redacted DeFlock reports.
- 111
- C
- GPL-3.0
- 3 wk ago

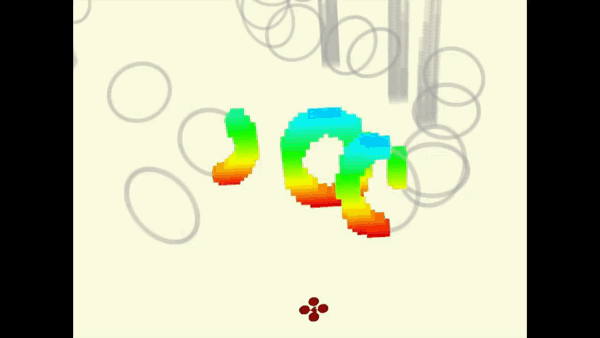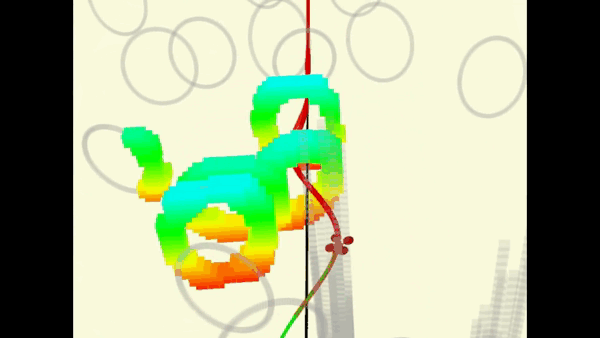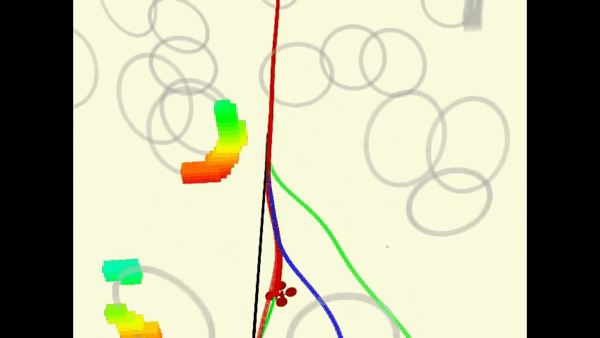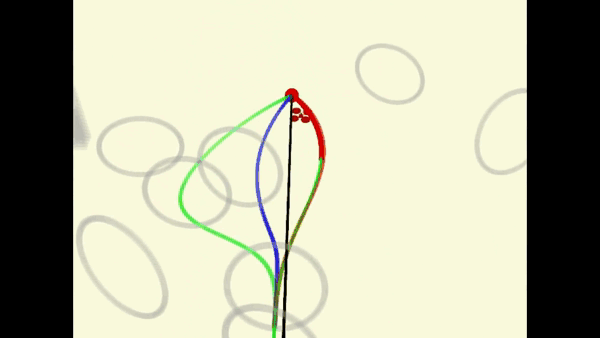
TopoTraj
A robust UAV local planner based on the ICRA2020 paper: Robust Real-time UAV Replanning Using Guided Gradient-based Optimization and Topological Paths
- 106
- 7 y ago
UAV-PUR-8B-GGUF
- 1
- 684
- apache-2.0
- 12 d ago
UAV-PUR-4B-GGUF
- 0
- 644
- apache-2.0
- 13 d ago
sae-2026-hang-all-yolo26n-seg-v2-960
Image segmentation model, used with ultralytics.
- 0
- 3.8k
- apache-2.0
- 5 mo ago
x3d-BaboonLand
- 0
- 24
- mit
- 9 mo ago