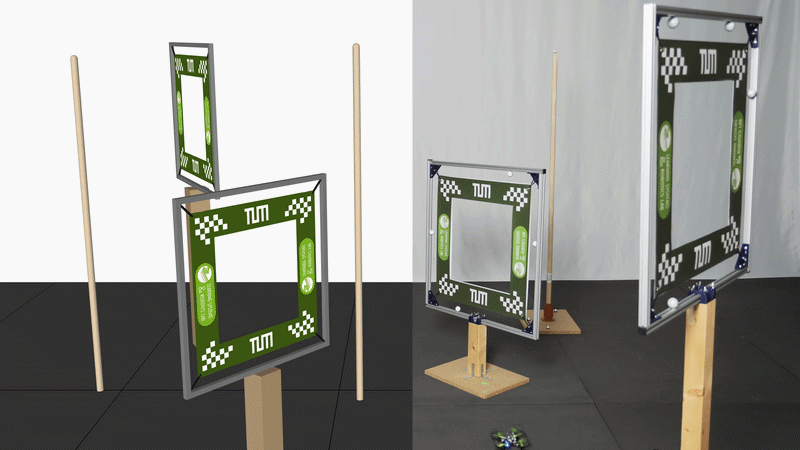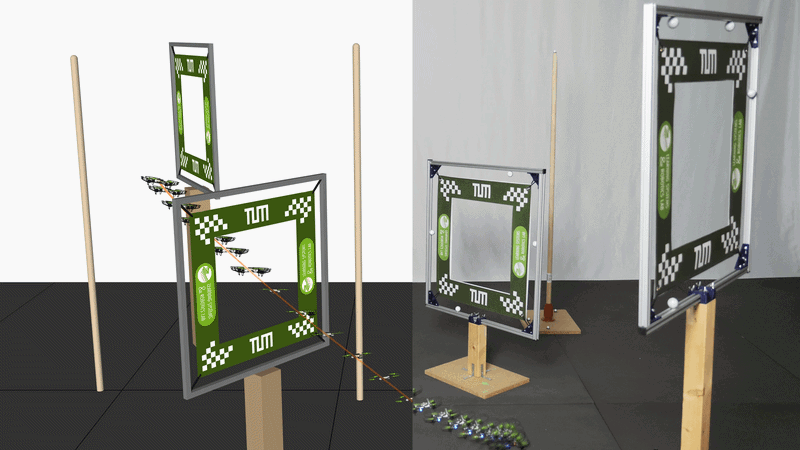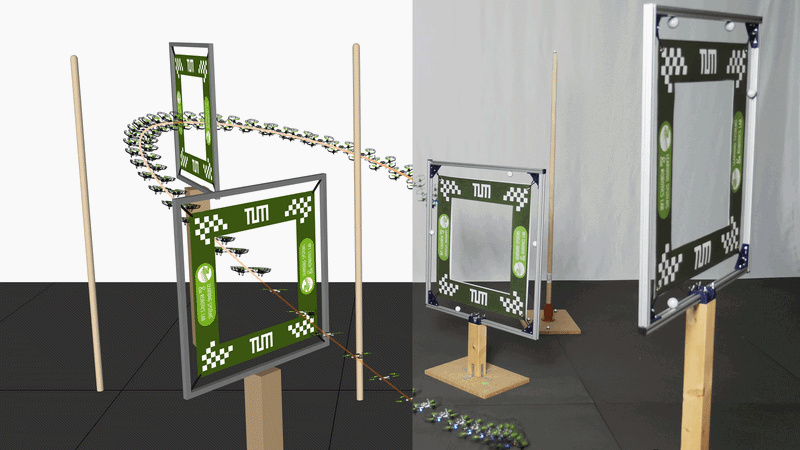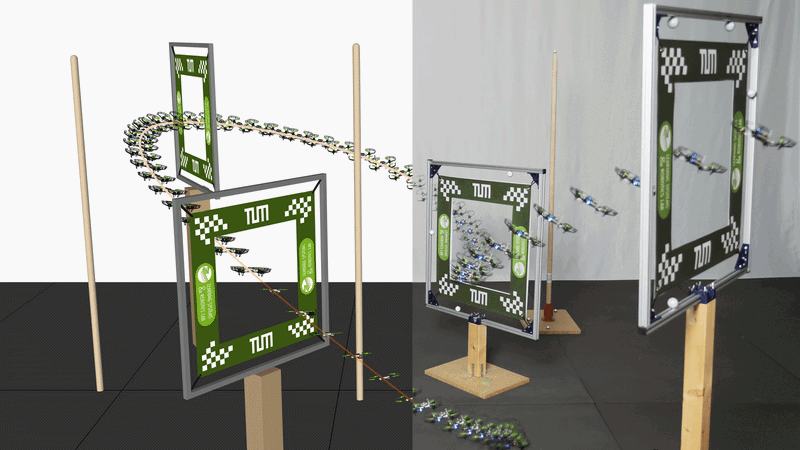

AMSwarm
Repository associated with paper titled "AMSwarm: An Alternating Minimization Approach for Safe Motion Planning of Quadrotor Swarms in Cluttered Environments", presented at IEEE ICRA 2023.
- 51
- MIT
- 3 y ago
Repo learnsyslab/AMSwarm, read from GitHub 1 min ago. learnsyslab has not joined Take My Repo.
In short
learnsyslab/AMSwarm is a public repo on GitHub by learnsyslab. Repository associated with paper titled "AMSwarm: An Alternating Minimization Approach for Safe Motion Planning of Quadrotor Swarms in Cluttered Environments", presented at IEEE ICRA 2023. It declares the MIT license on GitHub. It is written mainly in C, has 51 stars and last changed on 2023-10-28. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-21.
AMSwarm Repository
Repository associated with paper titled "AMSwarm: An Alternating Minimization Approach for Safe Motion Planning of Quadrotor Swarms in Cluttered Environments", presented at IEEE ICRA 2023.
Video: https://youtu.be/eIBcOKq5_Jk
What's included
- Codes:
- Proposed Distributed Alternating Minimizatiom (AM) based approach
- Distributed Sequential Convex Programming (SCP) with Continuous Collision Avoidance [1] and On-demand Collision Avoidance [2].
- Distributed Trajectory Optimization with Optimal Control Solver ACADO [3] (incorporating discrete-time Barrier Function constraints)
- Supplementart Material:
- Detailed experimental setup
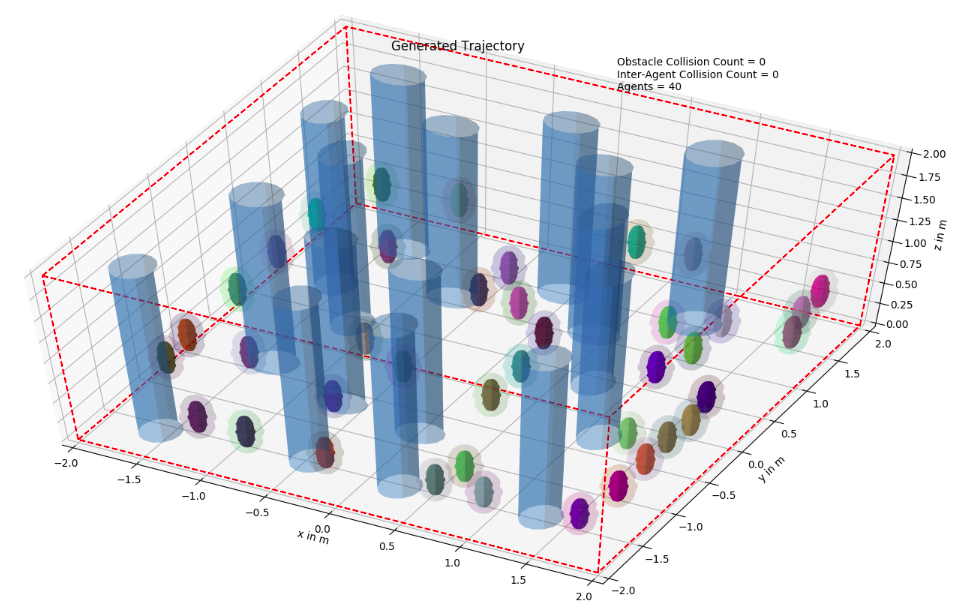
Simulation Environment Example

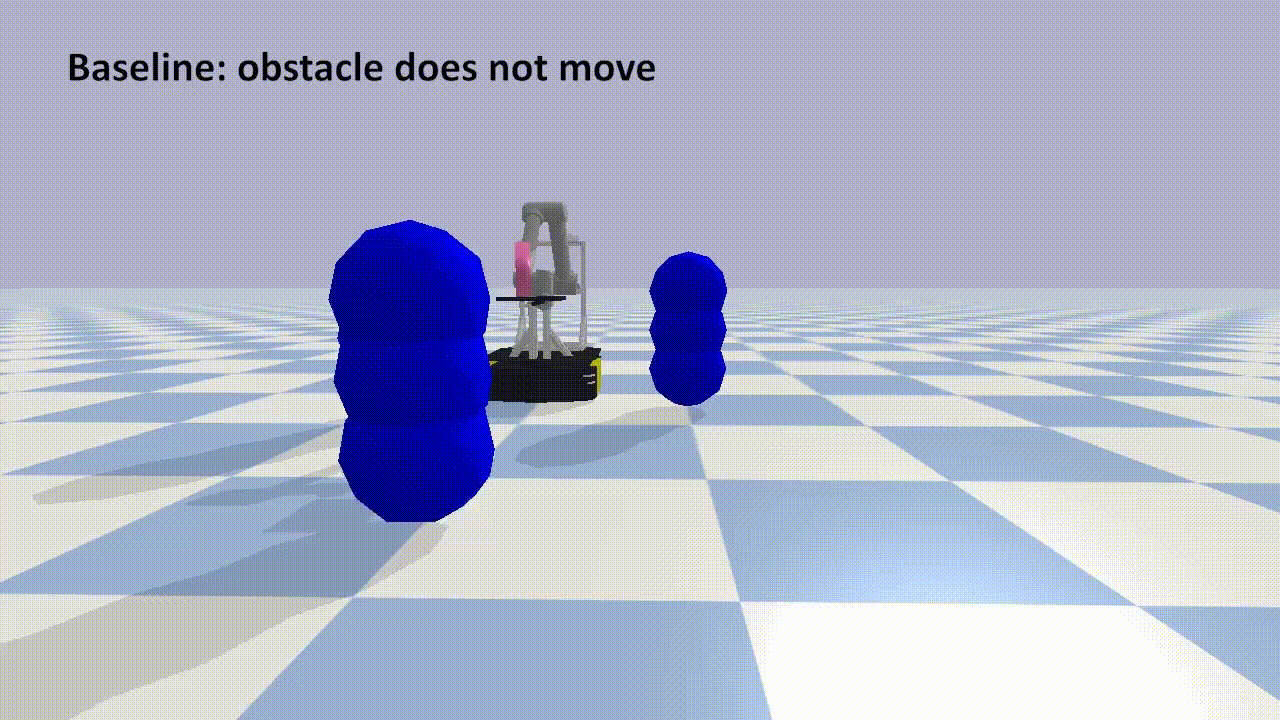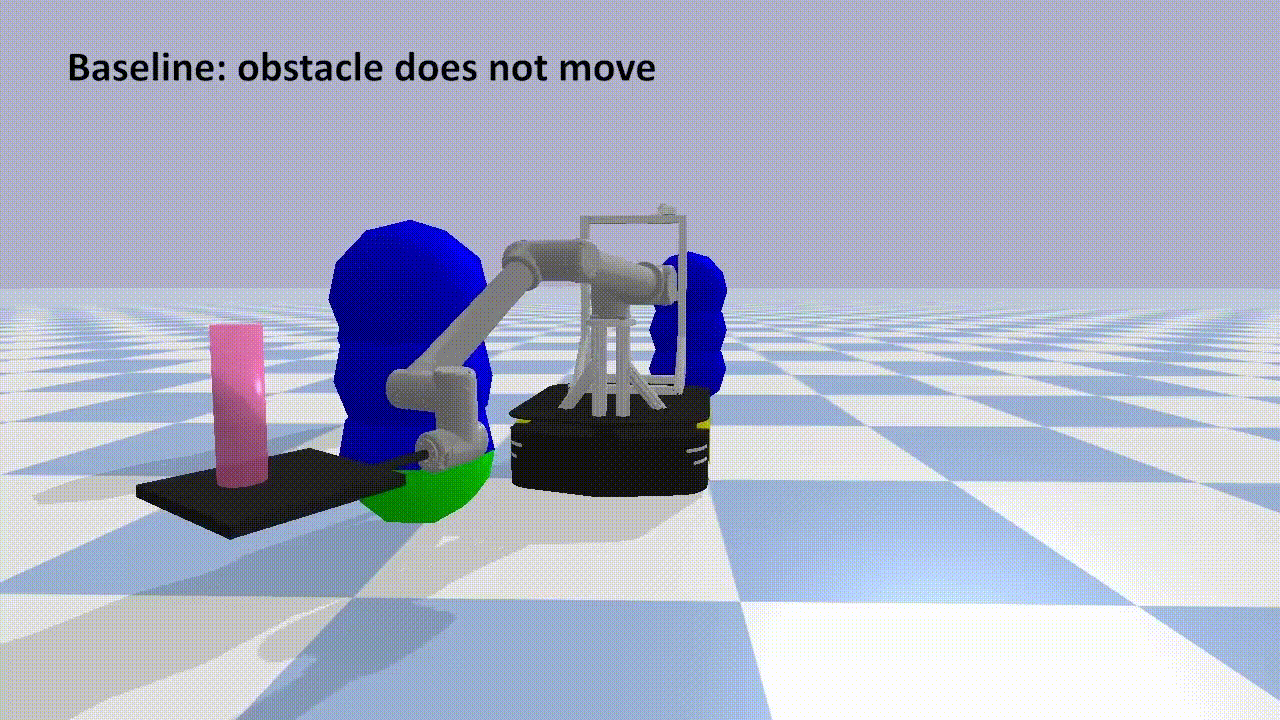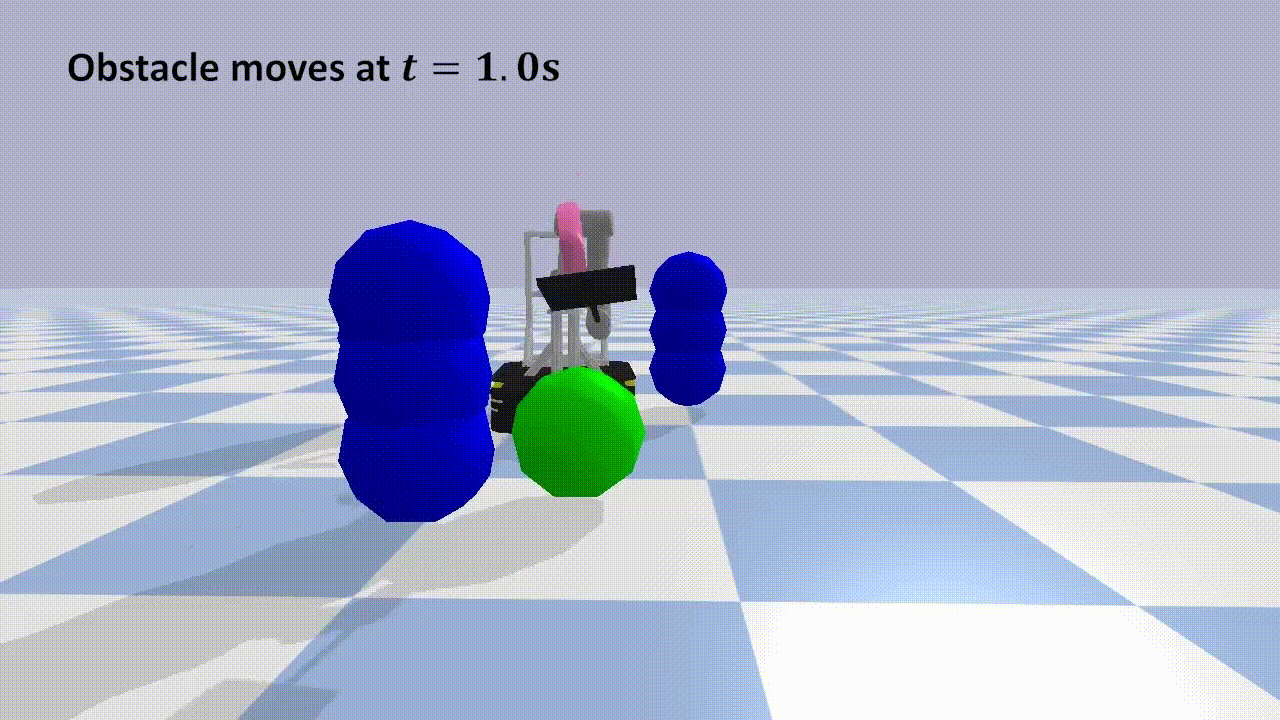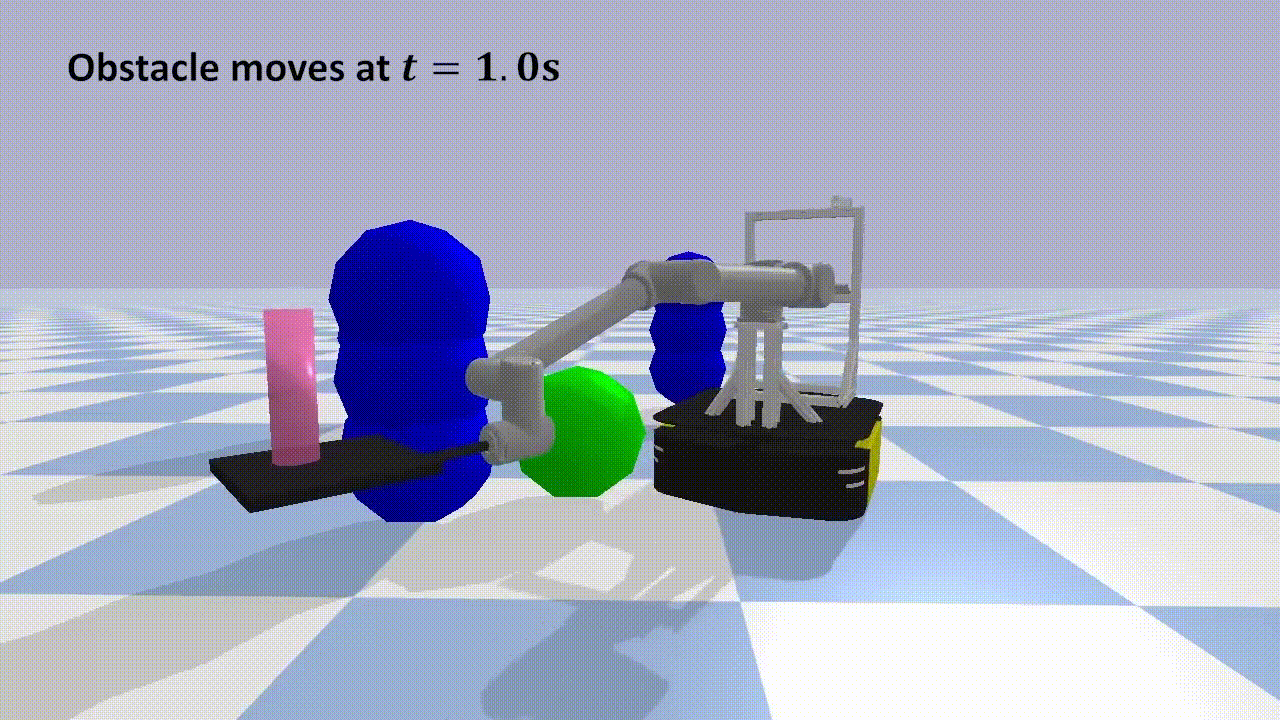
Fig. 40 quadrotors in a forest-like cluttered environment. Dark-colored ellipsoids are quadrotors and light-colored ellipsoids are respective goals of each quadrotor. Red-dashed lines represent a workable space, and tall blue cylinders are static obstacles.
References
[1] Soria, Enrica, Fabrizio Schiano, and Dario Floreano. "Distributed Predictive Drone Swarms in Cluttered Environments." IEEE Robotics and Automation Letters 7.1 (2021): 73-80.
[2] Luis, Carlos E., Marijan Vukosavljev, and Angela P. Schoellig. "Online trajectory generation with distributed model predictive control for multi-robot motion planning." IEEE Robotics and Automation Letters 5.2 (2020): 604-611.
[3] Houska, Boris, Hans Joachim Ferreau, and Moritz Diehl. "ACADO toolkit—An open‐source framework for automatic control and dynamic optimization." Optimal Control Applications and Methods 32.3 (2011): 298-312.
Questions
What is AMSwarm?
learnsyslab/AMSwarm is a public repo on GitHub by learnsyslab. Repository associated with paper titled "AMSwarm: An Alternating Minimization Approach for Safe Motion Planning of Quadrotor Swarms in Cluttered Environments", presented at IEEE ICRA 2023.
Is AMSwarm open source?
It declares the MIT license on GitHub.
Does AMSwarm run on macOS, Windows or Linux?
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
How do I install AMSwarm?
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Is AMSwarm still maintained?
Its last change on GitHub was on 2023-10-28. Take My Repo does not judge from that whether it is maintained.
What do people who ran AMSwarm say?
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.